
6 Axis Robot Controller

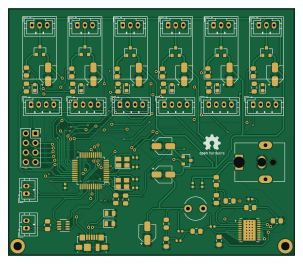
About the 6 Axis Robot Controller PCB
6 Axis Robot Controller is an open source STM32 PCB design by Biswajitpattanaik07, published on GitHub. It is a 2-layer board measuring 75.6 × 65.2 mm, with 85 components from 31 distinct parts.
Its main chip is the STM32F103C8Tx, from the STM32 family. Other key parts include the TPS53318DQPR, CP2102N-A01-GQFN24 and LM3480-3.3. By type, the board carries 26 capacitors, 24 resistors, 8 diodes, 6 transistors, 3 ICs and 1 inductor.
It belongs with the robotics & motion, rf & radio and usb & debug tools designs in this gallery.
From the project
Axion is an open-source controller board for a 6-axis articulated robot arm. It is built around an STM32F103C8T6 and combines six servo outputs, six per-joint IMU inputs, and three ways to talk to the outside world: USB, CAN bus, and an NRF24L01 wireless link.
Axion is an open-source controller board for a 6-axis articulated robot arm. It is built around an STM32F103C8T6 and combines six servo outputs, six per-joint IMU inputs, and three ways to talk to the outside world: USB, CAN bus, and an NRF24L01 wireless link.
The whole board runs from a single 12 V input. Everything else (5 V for servos and logic, 3.3 V for the MCU and radio) is generated on board.
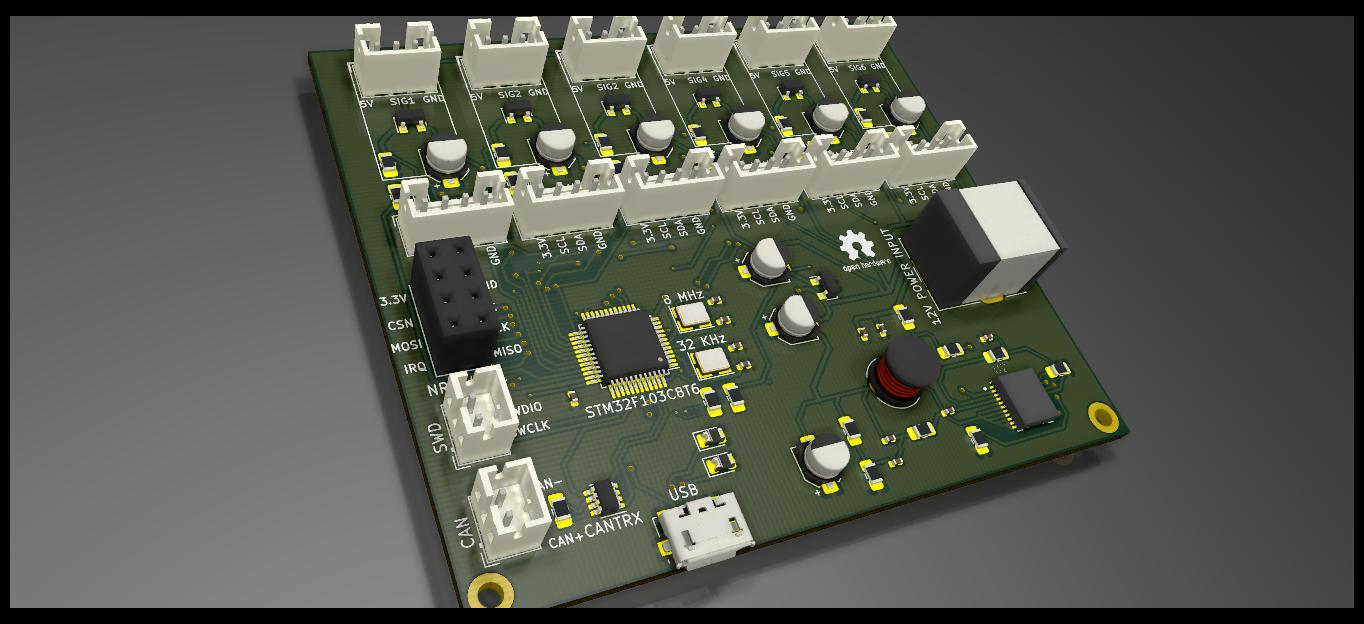
Main components on the 6 Axis Robot Controller
6 Axis Robot Controller bill of materials (BOM)
85 components, 31 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | TPS53318DQPR | CONV_TPS53318DQPR | U2 |
| 1 | CP2102N-A01-GQFN24 | QFN-24-1EP_4x4mm_P0.5mm_EP2.6x2.6mm | U3 |
| 1 | LM3480-3.3 | SOT-23 | U4 |
| 6 | DMN2056U | SOT-23 | Q1, Q2, Q3, Q4, Q5, Q6 |
| 2 | Crystal_GND23 | Crystal_SMD_Abracon_ABM8G-4Pin_3.2x2.5mm | 8 MHz, 32 KHz |
| 1 | Barrel_Jack | BarrelJack_CUI_PJ-063AH_Horizontal | 12V POWER INPUT |
| 6 | Conn_01x04 | JST_PH_B4B-PH-K_1x04_P2.00mm_Vertical | IMU1, IMU2, IMU3, IMU4, IMU5, IMU6 |
| 1 | Conn_02x04_Odd_Even | PinSocket_2x04_P2.54mm_Vertical | NRF24L01 |
| 6 | Conn_01x03 | JST_PH_B3B-PH-K_1x03_P2.00mm_Vertical | SERVO1, SERVO2, SERVO3, SERVO4, SERVO5, SERVO6 |
| 1 | STM32F103C8Tx | LQFP-48_7x7mm_P0.5mm | STM32F103C8T6 |
| 6 | LED | LED_0603_1608Metric | D1, D2, D3, D4, D5, D6 |
| 2 | D_TVS | D_0805_2012Metric | D7, D8 |
| 1 | 4.7U | L_Radial_D6.0mm_P4.00mm | L1 |
| 2 | 4.7U | C_0402_1005Metric | C1, C2 |
| 5 | 10N | C_0402_1005Metric | C3, C4, C5, C6, C7 |
| 1 | 1U | C_0402_1005Metric | C8 |
| 2 | 100N | C_0402_1005Metric | C9, C17 |
| 7 | 1N | C_0402_1005Metric | C10, C11, C12, C13, C14, C15, C16 |
| 1 | 100U | CP_Elec_4x3 | C18 |
| 2 | 1N | CP_Elec_4x3 | C19, C23 |
Show 11 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 6 | 2U | CP_Elec_4x3 | C20, C21, C22, C24, C25, C26 |
| 2 | 4.7K | R_0805_2012Metric_Pad1.15x1.40mm_HandSolder | R1, R2 |
| 1 | 854K | R_0805_2012Metric_Pad1.15x1.40mm_HandSolder | R3 |
| 1 | 86.6K | R_0805_2012Metric_Pad1.15x1.40mm_HandSolder | R4 |
| 1 | 1K | R_0805_2012Metric_Pad1.15x1.40mm_HandSolder | R5 |
| 3 | 105K | R_0805_2012Metric_Pad1.15x1.40mm_HandSolder | R6, R7, R11 |
| 7 | 1.91K | R_0805_2012Metric_Pad1.15x1.40mm_HandSolder | R8, R9, R10, R12, R13, R14, R15 |
| 1 | 69.8K | R_0805_2012Metric_Pad1.15x1.40mm_HandSolder | R16 |
| 1 | 10K | R_0805_2012Metric_Pad1.15x1.40mm_HandSolder | R17 |
| 6 | 2k | R_0805_2012Metric_Pad1.15x1.40mm_HandSolder | R18, R19, R20, R21, R22, R23 |
| 1 | 120 | R_0805_2012Metric_Pad1.15x1.40mm_HandSolder | R24 |
6 Axis Robot Controller design files
The KiCad project lives in the Biswajitpattanaik07/6_Axis_Robot_Controller repository on GitHub; these links point at the commit this page was built from.
- LayoutRoProp.kicad_pcb
- SchematicRoProp.kicad_sch
6 Axis Robot Controller: common questions
What microcontroller does the 6 Axis Robot Controller use?
The 6 Axis Robot Controller is built around the STM32F103C8Tx, from the STM32 family.
How big is the 6 Axis Robot Controller PCB?
The 6 Axis Robot Controller measures 75.6 × 65.2 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the 6 Axis Robot Controller?
85 components, from 31 distinct parts. The full bill of materials is listed on this page.
Where can I download the 6 Axis Robot Controller design files?
From the Biswajitpattanaik07/6_Axis_Robot_Controller repository on GitHub, which has the KiCad layout and the schematic; the links under Design files point to each one.
Can I use the 6 Axis Robot Controller design in my own project?
The repository has no license, so all rights stay with Biswajitpattanaik07. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the 6 Axis Robot Controller without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug STM32 firmware against it before you order a PCB.
Similar boards
 STM32
LumenPnP Motherboard
opulo-inc
149 × 95 mm296 parts4LCC-BY-SA-4.03.7k STM32
Type g
google
169 × 30 mm24 parts2LApache-2.02.9k STM32
Base
52.3 × 52.3 mm36 parts2LApache-2.02.9k STM32
Main panel
234 × 84 mm26 parts4LApache-2.02.9k STM32
Type a
150 × 30 mm14 parts2LApache-2.02.9k STM32
Type c
188 × 30 mm17 parts2LApache-2.02.9k