
Robot auto balanceur CUT2026

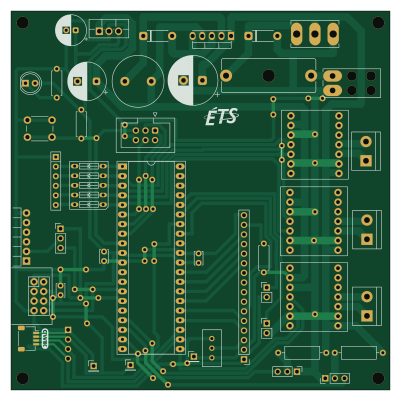
About the Robot auto balanceur CUT2026 PCB
Robot auto balanceur CUT2026 is an open source AVR/Arduino PCB design by recursive-embedded-DEV, published on GitHub. It is a 2-layer board measuring 100 × 100 mm, with 44 components from 41 distinct parts.
Its main chip is the ATmega644A-P, from the AVR/Arduino family. Other key parts include the LM2575-5.0BT, BA33BCO, Pont_H_MD, Pont_H_MG and Pont_H_Pince. By type, the board carries 12 connectors, 9 ICs, 6 capacitors, 6 resistors, 4 diodes and 2 switches.
It belongs with the robotics & motion designs in this gallery.
From the project
Ce répertoire présente les différentes étape de conception matérielle et logicielle d'un robot biroue auto-balanceur créé dans le cadre d'un projet étudiant en 2026 à l'École de Technologie Supérieure (ÉTS).
Main components on the Robot auto balanceur CUT2026
Robot auto balanceur CUT2026 bill of materials (BOM)
44 components, 41 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | ATmega644A-P | Microcontroller (Atmega644A) | U1 |
| 1 | LM2575-5.0BT | Breadboard friendly TO-220-5 (LM2575) | U2 |
| 1 | BA33BCO | TO-220F-3_Vertical | U3 |
| 1 | Pont_H_MD | H-bridge breakout (DRV8874) | U4 |
| 1 | Pont_H_MG | H-bridge breakout (DRV8874) | U5 |
| 1 | Pont_H_Pince | H-bridge breakout (DRV8874) | U6 |
| 1 | Wi-Fi_Module | Wifi module (ESP-01S) | U7 |
| 1 | UART Debug | TTL Debug connector (Pololu AVR) | U8 |
| 1 | Gyro_IMU | Qwiic connector (SM04B-SRSS-TB) | U9 |
| 1 | 5V | PinHeader_1x01_P2.54mm_Vertical | J1 |
| 1 | Servo_M_1 | Servo connector (pin header) | J2 |
| 1 | Pololu_ISP | IDC-Header_2x03_P2.54mm_Vertical | J3 |
| 1 | LS_1 | PinHeader_1x02_P2.54mm_Vertical | J4 |
| 1 | LS_2 | PinHeader_1x02_P2.54mm_Vertical | J5 |
| 1 | 3V3 | PinHeader_1x01_P2.54mm_Vertical | J6 |
| 1 | GND | PinHeader_1x01_P2.54mm_Vertical | J7 |
| 1 | Debug | Qwiic connector (pin header) | J8 |
| 1 | Moteur_D | Motor Screw Terminal (OSTTC) | J9 |
| 1 | Moteur_G | Motor Screw Terminal (OSTTC) | J10 |
| 1 | Bornier_Pince | Motor Screw Terminal (OSTTC) | J11 |
Show 21 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | Servo_M_2 | Servo connector (pin header) | J12 |
| 1 | LIPO_7.4V | Battery connector (JST RCY) | BT1 |
| 1 | LCD_16x02 | PinHeader_1x16_P2.54mm_Vertical | DS1 |
| 1 | 8A | Fuse holder (4628) | F1 |
| 1 | 10kR | Potentiometer_Bourns_3296W_Vertical | RV1 |
| 1 | On/Off | Toggle switch SPDT (ANT11SF1CQE) | SW1 |
| 1 | reset | SW_PUSH_6mm | SW2 |
| 1 | ~ | Bargraph 5 LED (XGxxX5D) | D1 |
| 1 | 1N5819 | D_DO-41_SOD81_P7.62mm_Horizontal | D2 |
| 1 | 1N4001 | D_DO-41_SOD81_P7.62mm_Horizontal | D4 |
| 1 | Green | LED_D5.0mm | D5 |
| 1 | 330uH | L_Radial_D13.5mm_P7.00mm_Fastron_09HCP | L1 |
| 3 | 100nF | C_Disc_D3.4mm_W2.1mm_P2.50mm | C1, C2, C5 |
| 1 | 100uF | CP_Radial_D8.0mm_P2.50mm | C3 |
| 1 | 1000uF | CP_Radial_D13.0mm_P5.00mm | C4 |
| 1 | 330uF | CP_Radial_D10.0mm_P5.00mm | C8 |
| 1 | 10kΩ | R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R1 |
| 1 | 470R | R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R2 |
| 2 | 1R5 | R_Axial_DIN0309_L9.0mm_D3.2mm_P12.70mm_Horizontal | R3, R5 |
| 1 | 330Ω | R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R4 |
| 1 | 330R | R_Array_SIP6 | RN1 |
Robot auto balanceur CUT2026 design files
The KiCad project lives in the recursive-embedded-DEV/Robot_auto_balanceur_CUT2026 repository on GitHub; these links point at the commit this page was built from.
Robot auto balanceur CUT2026: common questions
What microcontroller does the Robot auto balanceur CUT2026 use?
The Robot auto balanceur CUT2026 is built around the ATmega644A-P, from the AVR/Arduino family.
How big is the Robot auto balanceur CUT2026 PCB?
The Robot auto balanceur CUT2026 measures 100 × 100 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Robot auto balanceur CUT2026?
44 components, from 41 distinct parts. The full bill of materials is listed on this page.
Where can I download the Robot auto balanceur CUT2026 design files?
From the recursive-embedded-DEV/Robot_auto_balanceur_CUT2026 repository on GitHub, which has the KiCad layout and the schematic; the links under Design files point to each one.
Can I use the Robot auto balanceur CUT2026 design in my own project?
The repository has no license, so all rights stay with recursive-embedded-DEV. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the Robot auto balanceur CUT2026 without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug AVR/Arduino firmware against it before you order a PCB.
Similar boards
 AVR/Arduino
Magspoof
samyk
35 × 29 mm11 parts2LNo license4.2k AVR/Arduino
Redox keyboard
mattdibi
162.2 × 126.5 mm77 parts2LMIT2.0k AVR/Arduino
Labrador
espotek-org
36.8 × 34.7 mm75 parts2LNo license1.2k AVR/Arduino
ModuleV450
stuartpittaway
30 × 61.4 mm39 parts2LCC-BY-NC-4.01.1k AVR/Arduino
V4
30 × 50 mm38 parts2LCC-BY-NC-4.01.1k AVR/Arduino
Discipline
coseyfannitutti
304.9 × 122.8 mm170 parts2LCC-BY-NC-4.01.0k