
Simple robot

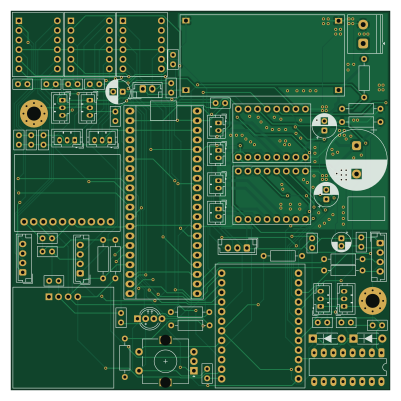
About the Simple robot PCB
Simple robot is an open source PCB design by 1-rafael-1, published on GitHub under the MIT license. It is a 4-layer board measuring 100 × 100 mm, with 67 components from 39 distinct parts.
Other key parts include the CD4049UB. By type, the board carries 26 capacitors, 17 connectors, 11 resistors, 2 diodes, 1 IC and 1 switch.
It belongs with the robotics & motion, sensors and displays & leds designs in this gallery.
From the project
A not-too-simple tracked robot with autonomous navigation and sensor-driven obstacle avoidance, written in Rust with Embassy. v2 reached the limits of its hardware platform; development continues in a new repository.
A not-too-simple tracked robot with autonomous navigation and sensor-driven obstacle avoidance, written in Rust with Embassy. v2 reached the limits of its hardware platform; development continues in the follow-up explorer-robot repository.
This started out as a hobby project for my 10-year-old son, who wanted me to build a robot for him. The thing started as a rather simple machine (v1) and then I got a little carried away. Check out the v1-robot navigating autonomously, download the demo video here: Autonomous Operation.
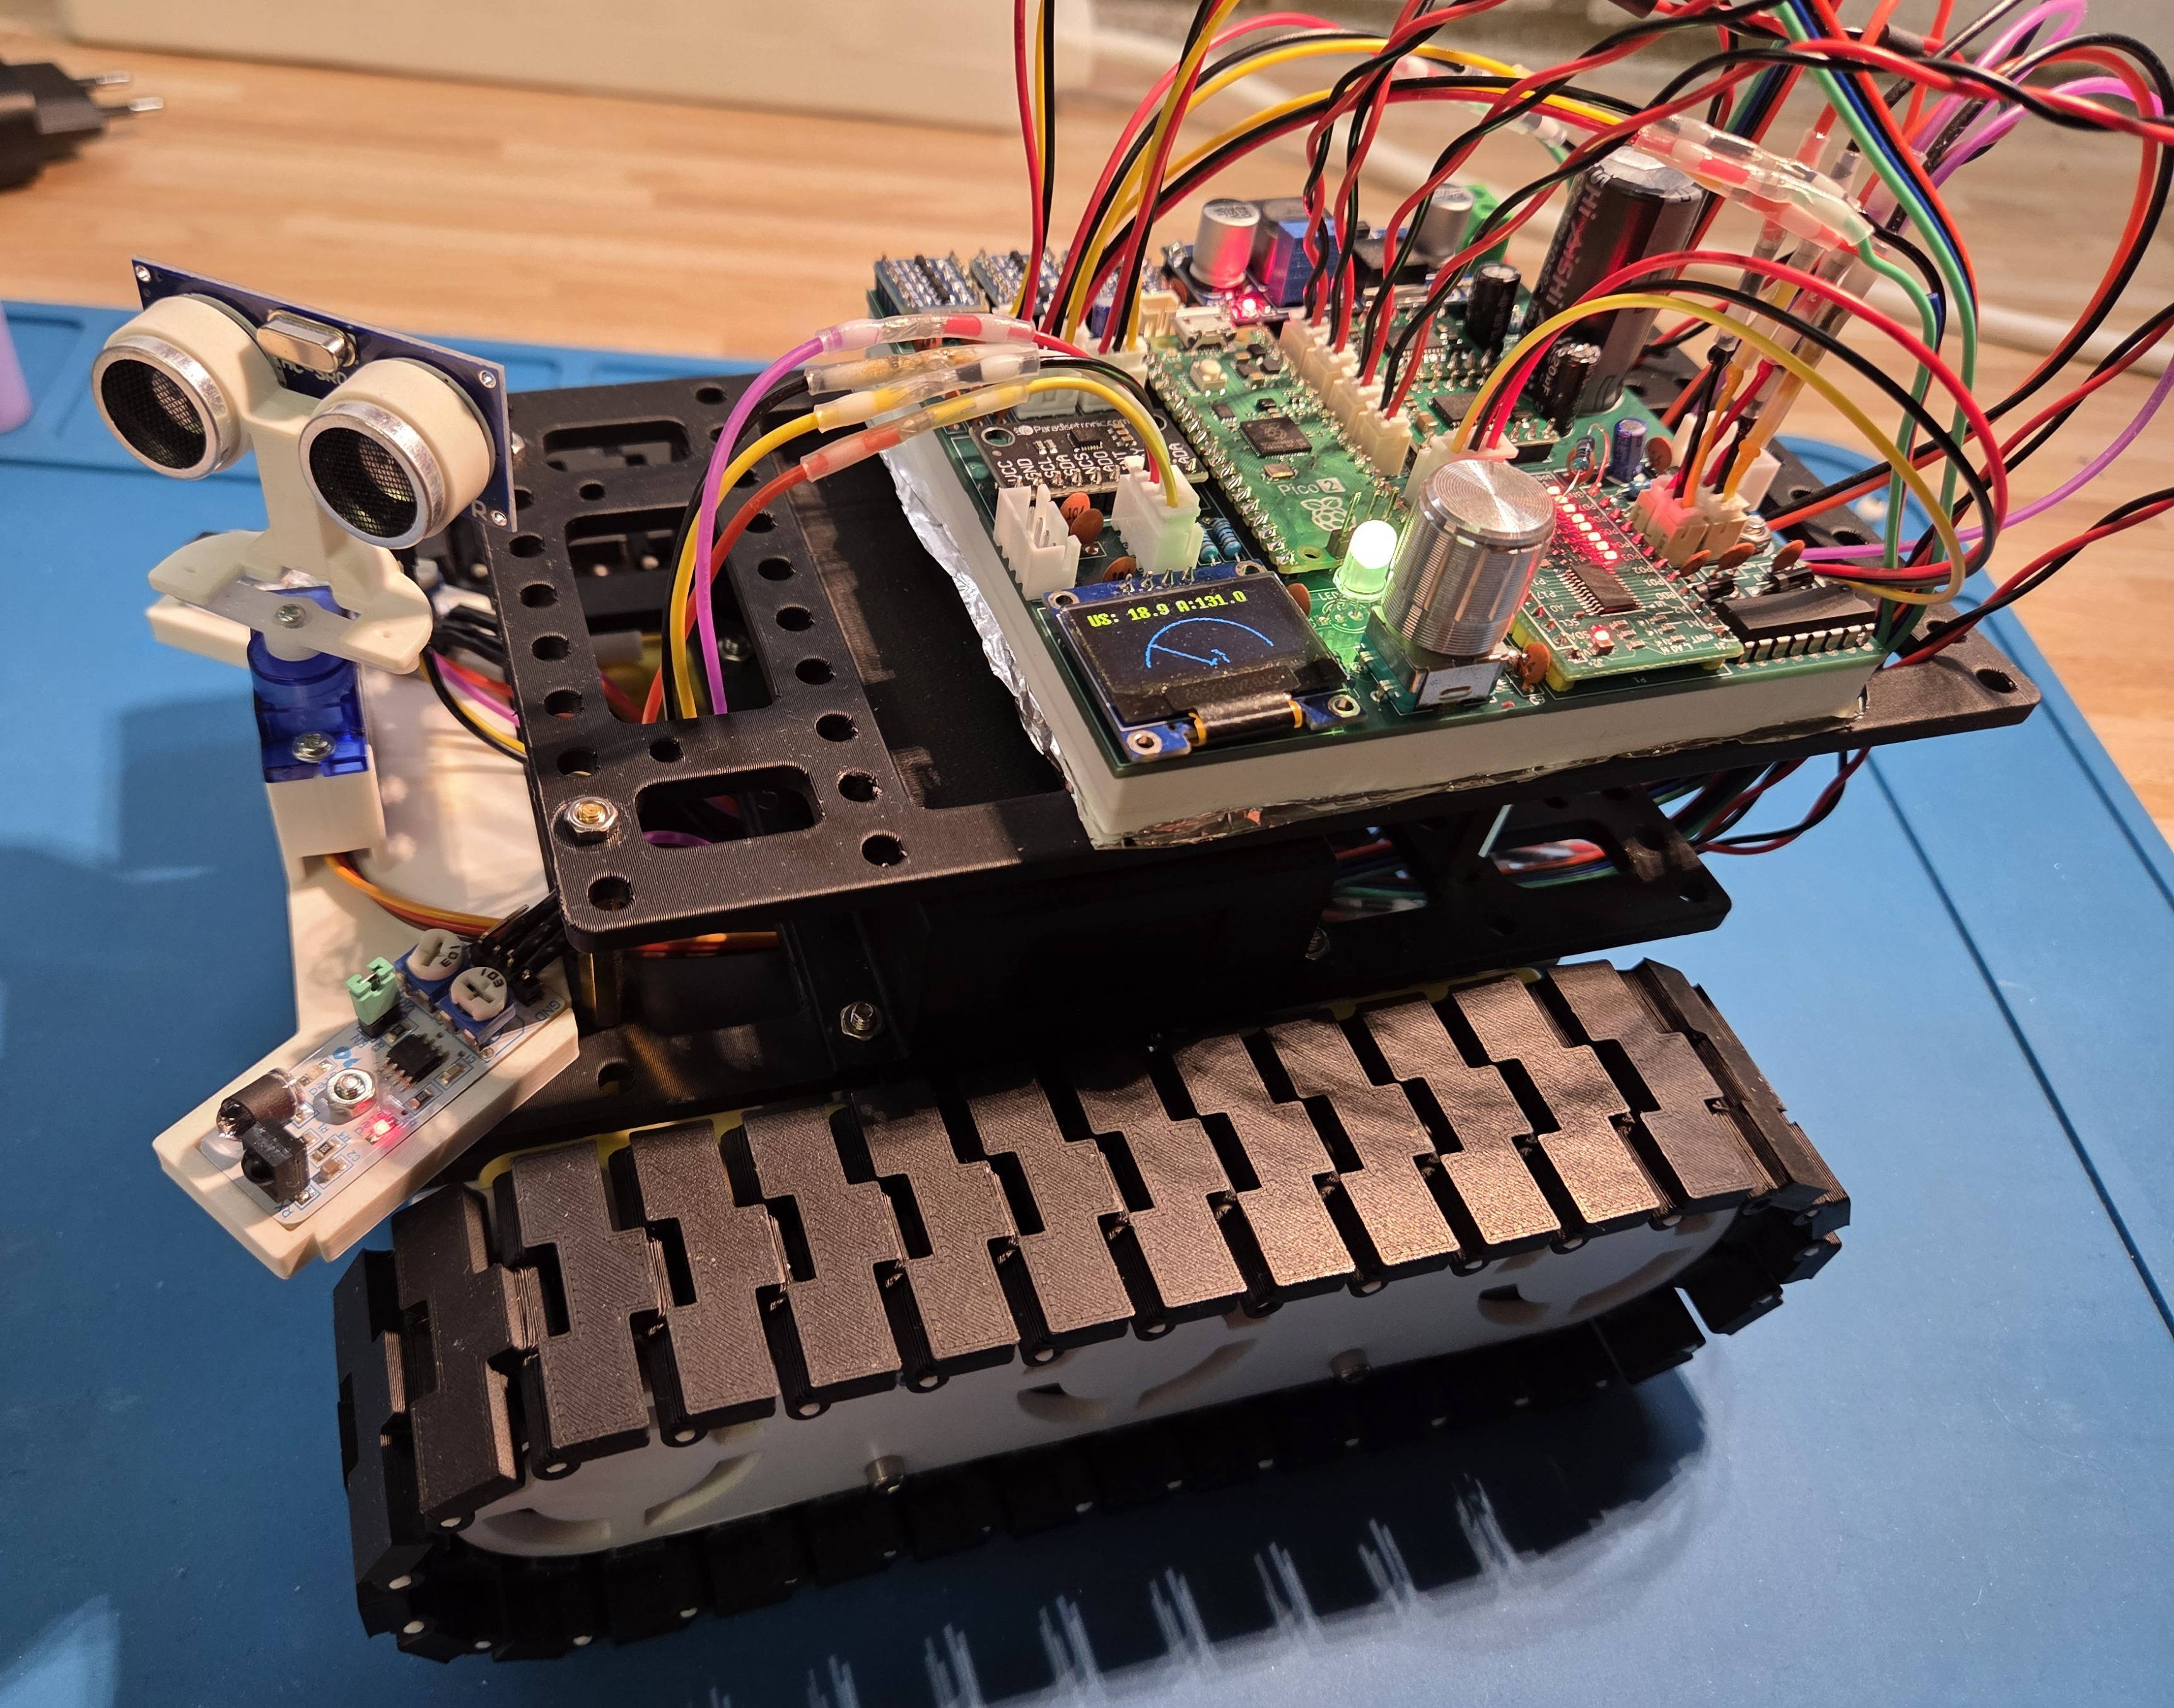
Main components on the Simple robot
Simple robot bill of materials (BOM)
67 components, 39 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | CD4049UB | DIP-16_W7.62mm_LongPads | U2 |
| 1 | MotLA | JST_PH_B2B-PH-K_1x02_P2.00mm_Vertical | J1 |
| 1 | MotLB | JST_PH_B2B-PH-K_1x02_P2.00mm_Vertical | J2 |
| 1 | JST03 Servo | JST_EH_B3B-EH-A_1x03_P2.50mm_Vertical | J3 |
| 1 | MotRA | JST_PH_B2B-PH-K_1x02_P2.00mm_Vertical | J4 |
| 1 | MotRB | JST_PH_B2B-PH-K_1x02_P2.00mm_Vertical | J5 |
| 1 | ENC_LF | JST_PH_B3B-PH-K_1x03_P2.00mm_Vertical | J6 |
| 1 | ENC_LR | JST_PH_B3B-PH-K_1x03_P2.00mm_Vertical | J7 |
| 1 | ENC_RF | JST_PH_B3B-PH-K_1x03_P2.00mm_Vertical | J8 |
| 1 | ENC_RR | JST_PH_B3B-PH-K_1x03_P2.00mm_Vertical | J9 |
| 1 | SCREW_TERMINAL_2_P5.00MM Screw_Terminal_2_P5.00mm | TerminalBlock_Phoenix_PT-1,5-2-5.0-H_1x02_P5.00mm_Horizontal | J10 |
| 1 | JSTHCSR04 | JST_EH_B4B-EH-A_1x04_P2.50mm_Vertical | J11 |
| 1 | IR_RF | JST_PH_B3B-PH-K_1x03_P2.00mm_Vertical | J12 |
| 1 | IR_LF | JST_PH_B3B-PH-K_1x03_P2.00mm_Vertical | J13 |
| 1 | JST_GV | JST_EH_B4B-EH-A_1x04_P2.50mm_Vertical | J14 |
| 1 | JST RF_Logic | JST_EH_B4B-EH-A_1x04_P2.50mm_Vertical | J15 |
| 1 | JST RF_PW | JST_EH_B2B-EH-A_1x02_P2.50mm_Vertical | J16 |
| 1 | Port Expander | PCA9555 Port Expander | P1 |
| 1 | LM2596 Module | LM2596_Module | B1 |
| 1 | ~ | ICM-20948-module | I1 |
Show 19 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 3 | Level Shifter | Level shifter 4 bi-dir | LS_1, LS_2, LS_3 |
| 1 | LeftTrack | TB6612FNG motor driver carrier | MD1 |
| 1 | RightTrack | TB6612FNG motor driver carrier | MD2 |
| 1 | ~ | SSD1306 | OLED1 |
| 1 | RotaryEncoder_Switch | RotaryEncoder_Alps_EC11E-Switch_Vertical_H20mm | SW1 |
| 1 | LED_5MM_RGB_KCOM_RKGB LED_5mm_RGB_Kcom_RKGB | LED_D5.0mm-4_RGB_Wide_Pins | LED1 |
| 2 | 1N5819 | D_DO-41_SOD81_P7.62mm_Horizontal | D1, D3 |
| 2 | 220UF 220uF | CP_Radial_D6.3mm_P2.50mm | C1, C7 |
| 21 | 100NF_CERAMIC 100nF_Ceramic | C_Disc_D5.0mm_W2.5mm_P2.50mm | C2, C3, C4, C5, C6, C8, C9, C10 +13 |
| 1 | 10UF_10V 10uF_10V | CP_Radial_D6.3mm_P2.50mm | C17 |
| 1 | 4700UF_16V 4700uF_16V | CP_Radial_D16.0mm_P7.50mm | C18 |
| 1 | 10UF_16V 10uF_16V | CP_Radial_D5.0mm_P2.00mm | C25 |
| 1 | 3K3 | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R1 |
| 2 | 47OHM 47ohm | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R2, R3 |
| 2 | 20K 20k | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R4, R7 |
| 2 | 1k | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R5, R6 |
| 1 | 10K 10k | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R8 |
| 1 | 330OHM 330ohm | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R9 |
| 2 | 220OHM 220ohm | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R10, R11 |
Simple robot design files
The KiCad project lives in the 1-rafael-1/simple-robot repository on GitHub; these links point at the commit this page was built from.
Simple robot: common questions
How big is the Simple robot PCB?
The Simple robot measures 100 × 100 mm, has 4 copper layers and is 1.6002 mm thick.
How many components are on the Simple robot?
67 components, from 39 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Simple robot design files?
From the 1-rafael-1/simple-robot repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the Simple robot design in my own project?
Yes, under the terms of its MIT license, which 1-rafael-1 chose for the repository.
Similar boards
BM28B0.6-24DSBreakout
scottbez1
15.2 × 35.6 mm3 parts2LApache-2.022.2k
LevelShifterBreakout
15.2 × 20.3 mm5 parts2LApache-2.022.2k
View base
81.2 × 81.2 mm81 parts2LApache-2.022.2k
View screen
35 × 35 mm12 parts2LApache-2.022.2k
Display eval
byrantech
52.1 × 22.6 mm12 parts4LMIT4.3k
ChainlinkDriverTester
198.1 × 95.3 mm123 parts2LApache-2.04.2k