
Rosario-ROV

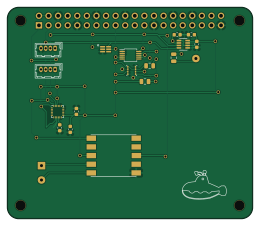
About the Rosario-ROV PCB
Rosario-ROV is an open source PCB design by dakriy, published on GitHub under the MIT license. It is a 2-layer board measuring 65 × 56 mm, with 18 components from 12 distinct parts.
Other key parts include the MPU-9250, BME280, LIGHT_TSL2591, LTC4316IDDPBF and AtlasOEM. By type, the board carries 6 ICs, 6 capacitors, 3 connectors and 3 resistors.
From the project
This project is to create a working ROV with features such as live video for the WWU Rosario Beach Marine Laboratory.
Main components on the Rosario-ROV
Rosario-ROV bill of materials (BOM)
18 components, 12 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | MPU-9250 | InvenSense_QFN-24_3x3mm_P0.4mm | U1 |
| 1 | BME280 | Bosch_LGA-8_2.5x2.5mm_P0.65mm_ClockwisePinNumbering | U2 |
| 1 | LIGHT_TSL2591 | DFN6_TAOS | U3 |
| 1 | LTC4316IDDPBF | MSOP-10_3x3mm_P0.5mm | U4 |
| 1 | AtlasOEM | OEM Board | U5 |
| 1 | LTC2451CTS8-TRMPBF | LTC2451CTS8-TRMPBF | U6 |
| 2 | Conn_01x04_Male | Hirose_DF13-04P-1.25DSA_1x04_P1.25mm_Vertical | J1, J2 |
| 1 | Conn_02x20_Odd_Even | PinSocket_2x20_P2.54mm_Vertical | P1 |
| 5 | 0.1uF | C_0603_1608Metric | C1, C2, C3, C5, C6 |
| 1 | 10uF | C_0603_1608Metric | C4 |
| 2 | 3k | R_0805_2012Metric | R1, R2 |
| 1 | 1k | R_0805_2012Metric | R3 |
Rosario-ROV design files
The KiCad project lives in the dakriy/Rosario-ROV repository on GitHub; these links point at the commit this page was built from.
Rosario-ROV: common questions
How big is the Rosario-ROV PCB?
The Rosario-ROV measures 65 × 56 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Rosario-ROV?
18 components, from 12 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Rosario-ROV design files?
From the dakriy/Rosario-ROV repository on GitHub, which has the KiCad layout and the BOM; the links under Design files point to each one.
Can I use the Rosario-ROV design in my own project?
Yes, under the terms of its MIT license, which dakriy chose for the repository.