
Assistive quadruped robot

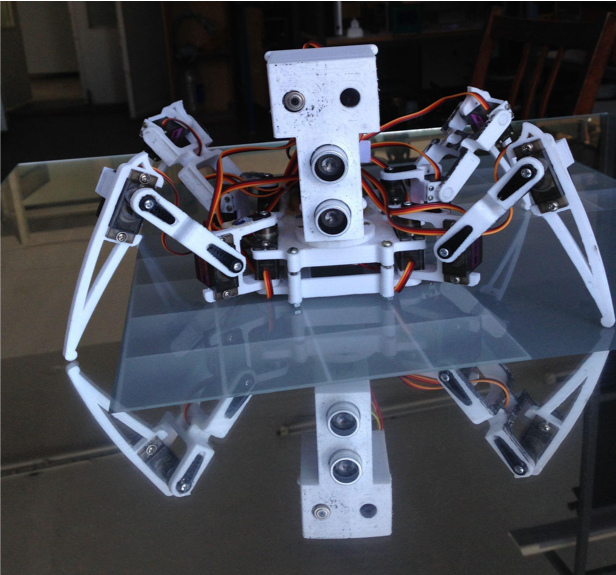
About the Assistive quadruped robot PCB
Assistive quadruped robot is an open source AVR/Arduino PCB design by firuzakhmad, published on GitHub under the MIT license. It is a board, with 27 components from 11 distinct parts.
Its main chip is the ARDUINO-PRO-MINI-, from the AVR/Arduino family. Other key parts include the 1X02_HEADER and DC-DC-STEP-DOWN-LM2596. By type, the board carries 4 jumpers, 3 ICs, 1 module, 1 connector, 1 switch and 1 LED.
It belongs with the robotics & motion, sensors and power & battery designs in this gallery.
From the project
Design and Implementation of a Semi-Autonomous Quadruped Assistive Robot for Remote Elderly Monitoring and COVID-19 Response
A low-cost, modular quadruped robot designed for autonomous and semi-autonomous assistive tasks in healthcare environments, such as elderly care and infectious disease monitoring. The robot features real-time video streaming, non-contact thermal sensing, and object tracking.
- Overview - Key Features - Hardware Design & Modifications - Bill of Materials (BOM) - Software & Firmware - Repository Structure - Build & Installation - Usage - Research Paper - Acknowledgements - License
Main components on the Assistive quadruped robot
Assistive quadruped robot bill of materials (BOM)
27 components, 11 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 2 | 1X02_HEADER | 1X02_HEADER | U$1, U$3 |
| 1 | DC-DC-STEP-DOWN-LM2596 | DC-DC-STEP-DOWN-LM2596 | U$2 |
| 1 | ARDUINO-PRO-MINI- | ARDUINO-PRO-MINI | M1 |
| 1 | POWER_JACK{dblquote} | POWER_JACK | J1 |
| 12 | M03PTH | 1X03 | COXA0, COXA1, COXA2, COXA3, FEMUR0, FEMUR1, FEMUR2, FEMUR3 +4 |
| 1 | BLUETOOTH_BOARDSTANDING | BT_BOARD_FOOTPRINT_STANDING | HC-06 |
| 2 | 1X04_HEADER{dblquote} | 1X04_HEADER | I2C_J1, I2C_J2 |
| 4 | M03PTH | 1X03 | JP1, JP2, JP3, JP4 |
| 1 | 9077-2 | 9077-2 | S1 |
| 1 | LED3MM | LED | LED1 |
| 1 | 10k | AXIAL-0.4 | R1 |
Assistive quadruped robot design files
The KiCad project lives in the firuzakhmad/assistive-quadruped-robot repository on GitHub; these links point at the commit this page was built from.
- Schematicpcb/Quadruped.kicad_sch
Assistive quadruped robot: common questions
What microcontroller does the Assistive quadruped robot use?
The Assistive quadruped robot is built around the ARDUINO-PRO-MINI-, from the AVR/Arduino family.
How many components are on the Assistive quadruped robot?
27 components, from 11 distinct parts. The full bill of materials is listed on this page.
Where can I download the Assistive quadruped robot design files?
From the firuzakhmad/assistive-quadruped-robot repository on GitHub, which has the schematic; the links under Design files point to each one.
Can I use the Assistive quadruped robot design in my own project?
Yes, under the terms of its MIT license, which firuzakhmad chose for the repository.
Can I test firmware for the Assistive quadruped robot without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug AVR/Arduino firmware against it before you order a PCB.
Similar boards
 AVR/Arduino
Magspoof
samyk
35 × 29 mm11 parts2LNo license4.2k AVR/Arduino
Redox keyboard
mattdibi
162.2 × 126.5 mm77 parts2LMIT2.0k AVR/Arduino
Labrador
espotek-org
36.8 × 34.7 mm75 parts2LNo license1.2k AVR/Arduino
V4
stuartpittaway
30 × 50 mm38 parts2LCC-BY-NC-4.01.1k AVR/Arduino
ModuleV450
30 × 61.4 mm39 parts2LCC-BY-NC-4.01.1k AVR/Arduino
Discipline
coseyfannitutti
304.9 × 122.8 mm170 parts2LCC-BY-NC-4.01.0k