
6-DOF-Robot-

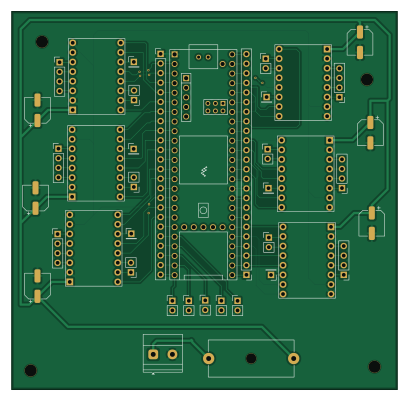
About the 6-DOF-Robot- PCB
6-DOF-Robot- is an open source NXP PCB design by hritesh94, published on GitHub under the MIT license. It is a 4-layer board measuring 102 × 100 mm, with 40 components from 10 distinct parts.
Its main chip is the Teensy4.1, from the NXP family. By type, the board carries 32 connectors, 1 IC and 1 fuse.
It belongs with the robotics & motion designs in this gallery.
From the project
6-DOF robot arm (open-source TW2KA) with my own KiCad PCB, Teensy 4.1 firmware and a browser controller with inverse kinematics and G-code drawing.
My own control board for the TW2KA arm: a Teensy 4.1 driving six TMC2209 stepper drivers, with endstop inputs. Designed in KiCad 10.
https://github.com/user-attachments/assets/b51a67fe-33f5-430a-8fab-c27dd11908fc
Pin map and endstop wiring: docs/02-hardware.md.
Opening the board works without the footprint libraries (footprints are stored inside the .kicadpcb). To edit footprints you also need the Tmc2209pinsocket.pretty folder and the Teensy footprint library (teensy.pretty`, available on GitHub).
Main components on the 6-DOF-Robot-
6-DOF-Robot- bill of materials (BOM)
40 components, 10 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | Teensy4.1 | Teensy41 | U1 |
| 6 | Conn_02x08_Odd_Even | TMC2209_MODULE | J1, J2, J3, J4, J5, J6 |
| 5 | Conn_01x02_Socket | PinHeader_1x02_P2.54mm_Vertical | J7, J8, J9, J10, J11 |
| 1 | Screw_Terminal_01x02 | TerminalBlock_Phoenix_MKDS-1,5-2-5.08_1x02_P5.08mm_Horizontal | J12 |
| 6 | Conn_01x04_Pin | PinHeader_1x04_P2.54mm_Vertical | J13, J14, J15, J16, J39, J40 |
| 6 | Conn_01x02_Pin | PinHeader_1x02_P2.54mm_Vertical | J17, J18, J19, J20, J21, J22 |
| 2 | Conn_01x24_Pin | PinHeader_1x24_P2.54mm_Vertical | J23, J25 |
| 6 | Conn_01x01_Pin | PinHeader_1x01_P2.54mm_Vertical | J24, J27, J28, J29, J30, J31 |
| 6 | C_Polarized_Small | CP_Elec_6.3x7.7 | 100uf1, 100uf2, 100uf3, 100uf4, 100uf5, 100uf6 |
| 1 | Fuse | Fuseholder_Cylinder-5x20mm_Schurter_0031_8201_Horizontal_Open | F1 |
6-DOF-Robot- design files
The KiCad project lives in the hritesh94/6-DOF-Robot- repository on GitHub; these links point at the commit this page was built from.
6-DOF-Robot-: common questions
What microcontroller does the 6-DOF-Robot- use?
The 6-DOF-Robot- is built around the Teensy4.1, from the NXP family.
How big is the 6-DOF-Robot- PCB?
The 6-DOF-Robot- measures 102 × 100 mm, has 4 copper layers and is 1.600198 mm thick.
How many components are on the 6-DOF-Robot-?
40 components, from 10 distinct parts. The full bill of materials is listed on this page.
Where can I download the 6-DOF-Robot- design files?
From the hritesh94/6-DOF-Robot- repository on GitHub, which has the KiCad layout and the schematic; the links under Design files point to each one.
Can I use the 6-DOF-Robot- design in my own project?
Yes, under the terms of its MIT license, which hritesh94 chose for the repository.
Can I test firmware for the 6-DOF-Robot- without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug NXP firmware against it before you order a PCB.
Similar boards
 NXP
32Bit shift register
MaltWhiskey
100 × 54 mm56 parts4LNo license763 NXP
Mega-Cube-Board
200 × 54 mm100 parts4LNo license763 NXP
MCL64
MicroCoreLabs
39.3 × 61.8 mm9 parts4LNo license532 NXP
ROM Emulator
21.5 × 37.1 mm5 parts2LNo license532 NXP
MCLZ8
37.1 × 61.5 mm6 parts4LNo license532 NXP
XTMAX
81 × 46 mm14 parts4LNo license532