
STM32-Quadcopter

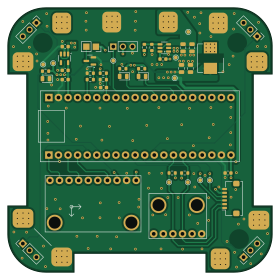
About the STM32-Quadcopter PCB
STM32-Quadcopter is an open source STM32 PCB design by I-M-Robotics-Lab, published on GitHub under the GPL-3.0 license. It is a 4-layer board measuring 70 × 70 mm, with 43 components from 34 distinct parts.
Its main chip is the STM32F411CEU1_PINS, from the STM32 family. Other key parts include the TLV73333P and TPS563200. By type, the board carries 13 connectors, 11 resistors, 10 capacitors, 3 ICs, 3 diodes and 1 transistor.
It belongs with the robotics & motion designs in this gallery.
From the project
Quadcopter design based on STM32F411CEU Blackpill flight controller. Compatible with INAV 6.0 firmware.
Website | Documentation | Community Discord | 3D Models & Prints
This is a quadcopter design based on the STM32F411CEU Blackpill flight controller. The flight controller is compatible with INAV 6.0 firmware. The flight controller uses an MPU6500 for inertial measurements and a BMP280 for altitude sensing, and also supports an optional GPS and magnetometer module.
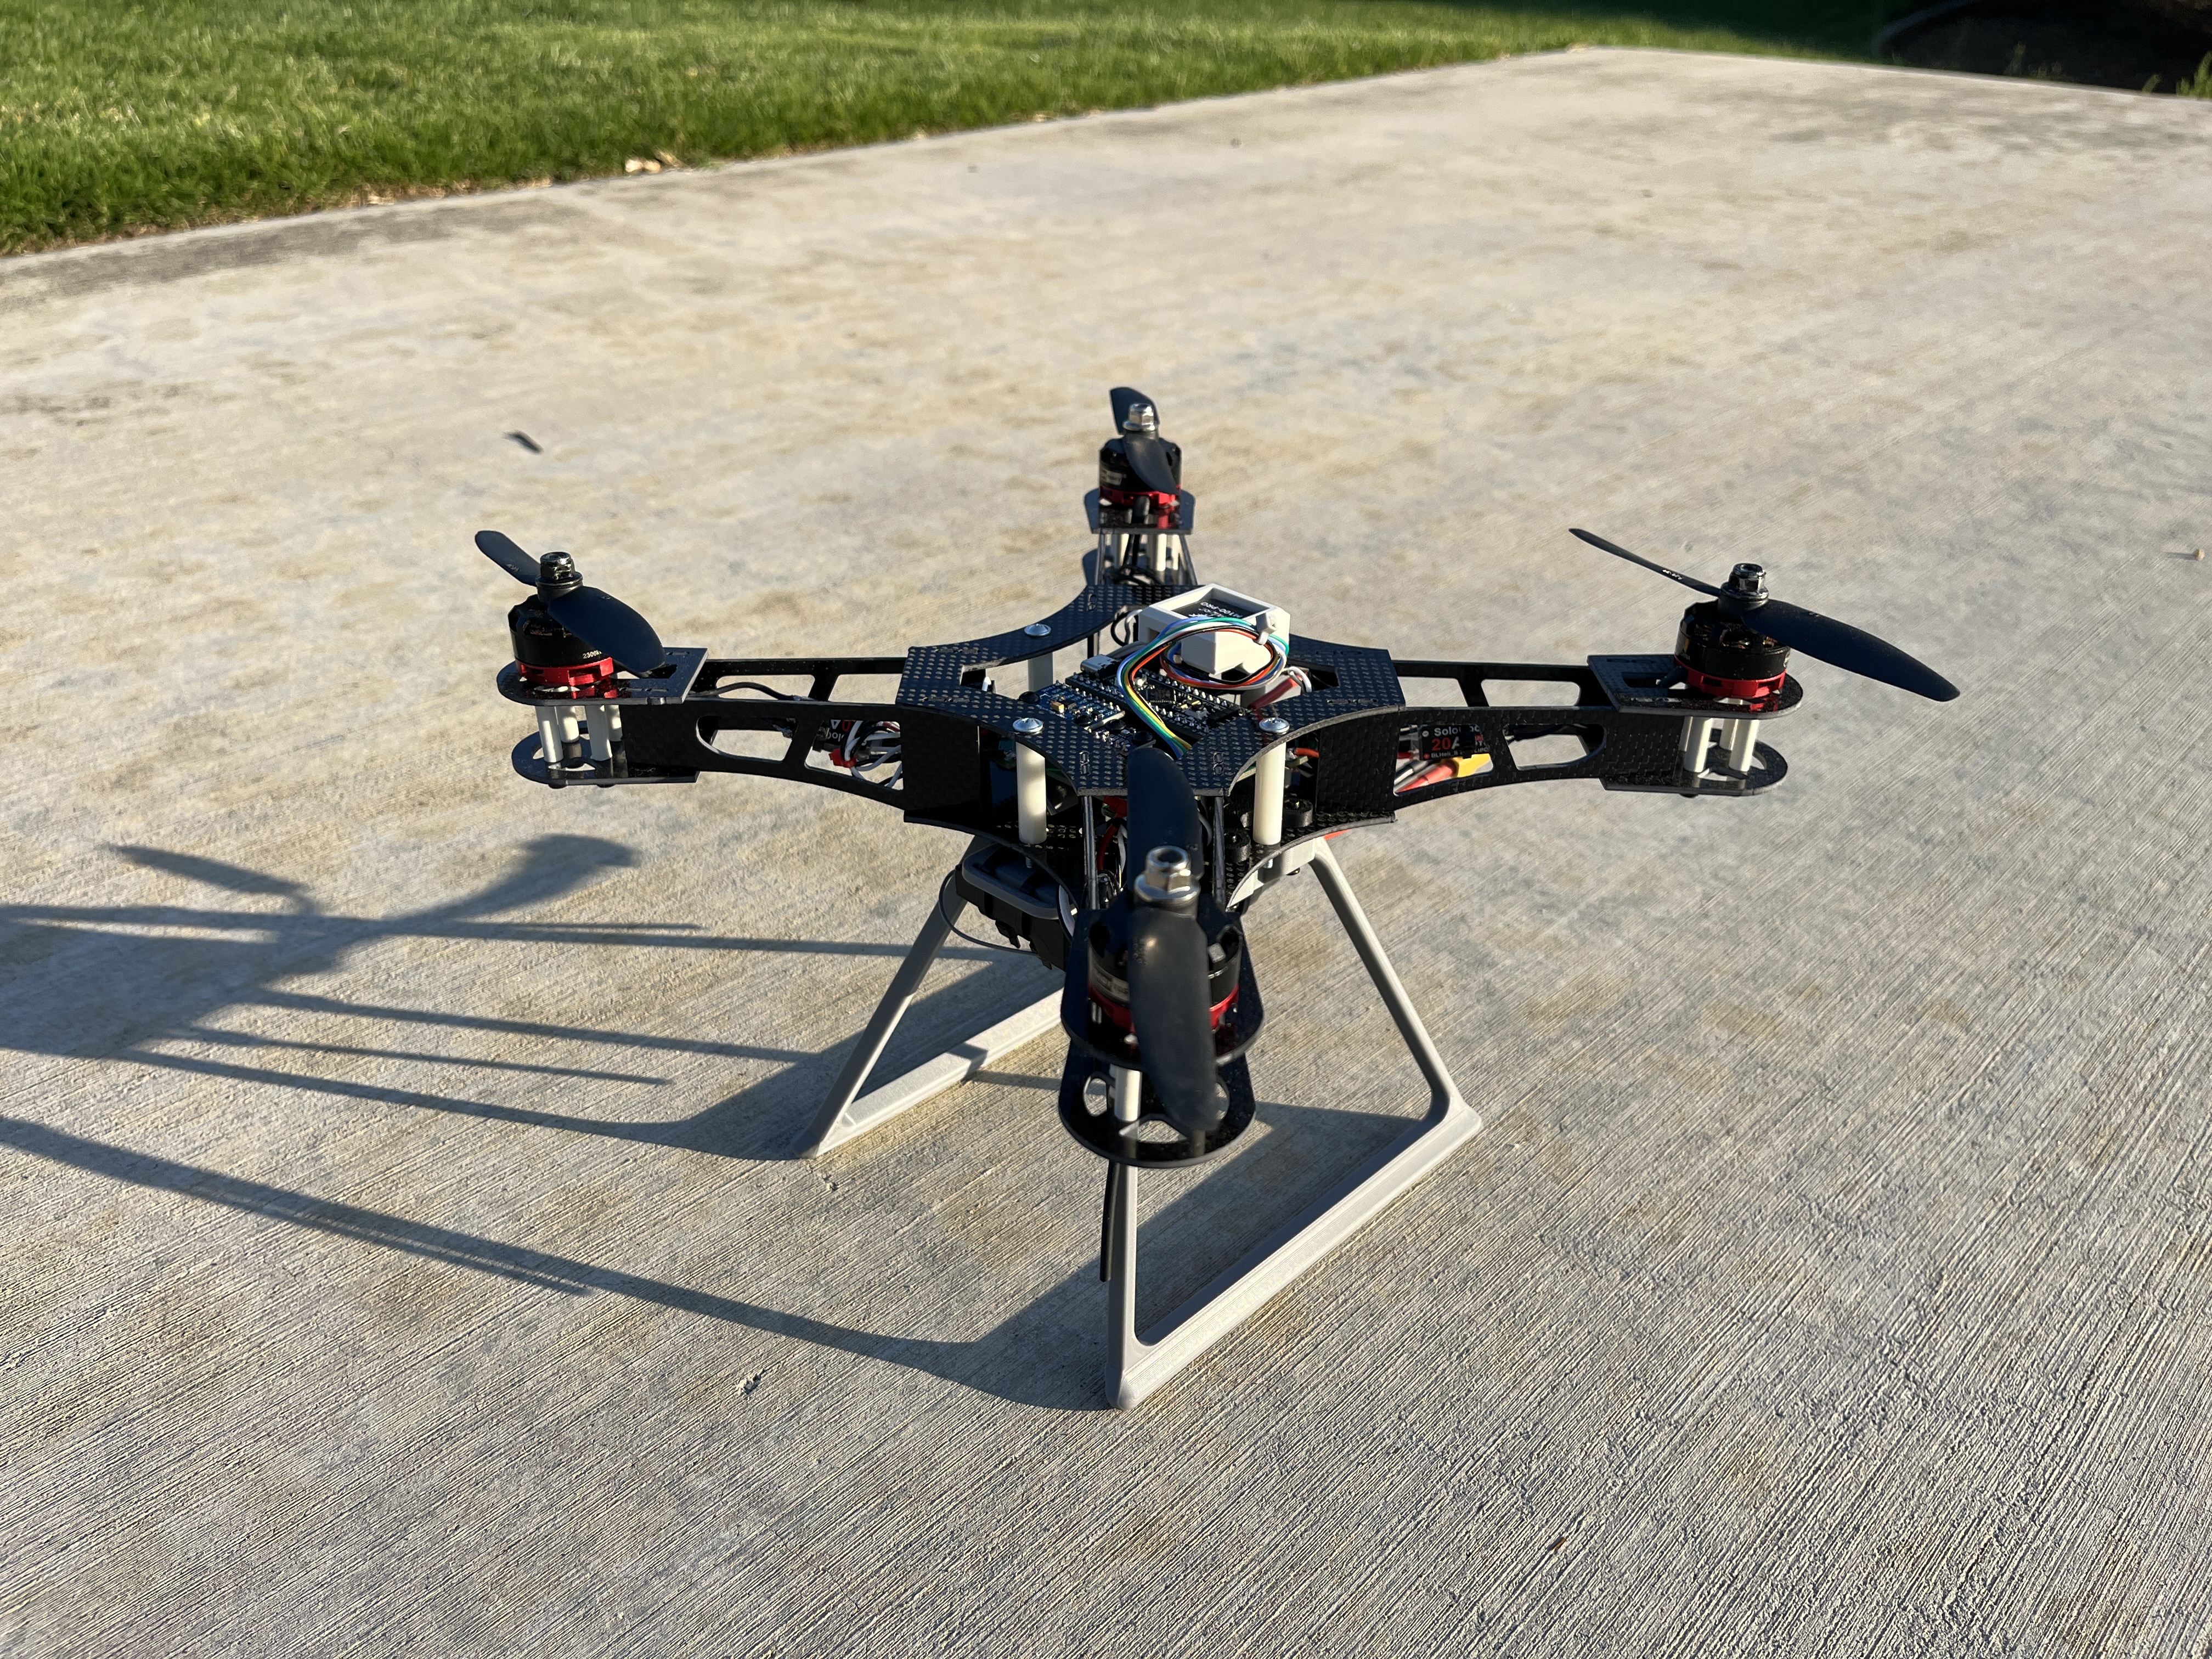
Main components on the STM32-Quadcopter
STM32-Quadcopter bill of materials (BOM)
43 components, 34 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | STM32F411CEU1_PINS STM32F411CEU1 | Stm32f411ceu_module | U1 |
| 1 | TLV73333P | SOT-23-5 | U2 |
| 1 | TPS563200 | SOT-23-6 | U3 |
| 1 | IRLML6344 | SOT-23 | Q1 |
| 1 | MPU9250_PINS MPU9250_Breakout | MPU9250_Mod | J1 |
| 1 | BMP280_PINS BMP280_Breakout | BMP280_Mod | J2 |
| 1 | GPS_Mag | JST_SHL_SM06B-SHLS-TF_1x06-1MP_P1.00mm_Horizontal | J3 |
| 1 | Receiver | PinHeader_1x03_P2.54mm_Vertical | J4 |
| 1 | PWM1 | PinHeader_1x03_P2.54mm_Vertical | J5 |
| 1 | PWM2 | PinHeader_1x03_P2.54mm_Vertical | J6 |
| 1 | PWM3 | PinHeader_1x03_P2.54mm_Vertical | J7 |
| 1 | PWM4 | PinHeader_1x03_P2.54mm_Vertical | J8 |
| 1 | M1 | PAD_1x02_5mm | J9 |
| 1 | M2 | PAD_1x02_5mm | J10 |
| 1 | M3 | PAD_1x02_5mm | J11 |
| 1 | M4 | PAD_1x02_5mm | J12 |
| 1 | VBAT | PAD_1x02_5mm | J13 |
| 1 | Buzzer | PinSocket_1x02_P2.54mm_Vertical | BZ1 |
| 1 | RED | LED_0805_2012Metric | D1 |
| 1 | GREEN | LED_0805_2012Metric | D2 |
Show 14 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | BLUE | LED_0805_2012Metric | D3 |
| 1 | 4.7U 4.7u | L_Wurth_WE-LHMI-7050 | L1 |
| 1 | 10u 25V | C_0805_2012Metric | C1 |
| 1 | 0.1u 25V | C_0805_2012Metric | C2 |
| 4 | 0.1u 10V | C_0603_1608Metric | C3, C8, C9, C10 |
| 1 | 22u 16V | C_0805_2012Metric | C4 |
| 1 | 22u 16V | C_0805_2012Metric | C5 |
| 2 | 1uF 10V | C_0603_1608Metric | C6, C7 |
| 1 | 54.9K 54.9k | R_0603_1608Metric | R1 |
| 3 | 10K 10k | R_0603_1608Metric | R2, R6, R8 |
| 2 | 4.7K 4.7k | R_0603_1608Metric | R3, R4 |
| 1 | 33K 33k | R_0603_1608Metric | R5 |
| 1 | 100 | R_0603_1608Metric | R7 |
| 3 | 470 | R_0603_1608Metric | R9, R10, R11 |
STM32-Quadcopter design files
The KiCad project lives in the I-M-Robotics-Lab/STM32-Quadcopter repository on GitHub; these links point at the commit this page was built from.
STM32-Quadcopter: common questions
What microcontroller does the STM32-Quadcopter use?
The STM32-Quadcopter is built around the STM32F411CEU1_PINS, from the STM32 family.
How big is the STM32-Quadcopter PCB?
The STM32-Quadcopter measures 70 × 70 mm, has 4 copper layers and is 1.6 mm thick.
How many components are on the STM32-Quadcopter?
43 components, from 34 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the STM32-Quadcopter design files?
From the I-M-Robotics-Lab/STM32-Quadcopter repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the STM32-Quadcopter design in my own project?
Yes, under the terms of its GPL-3.0 license, which I-M-Robotics-Lab chose for the repository.
Can I test firmware for the STM32-Quadcopter without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug STM32 firmware against it before you order a PCB.
Similar boards
 STM32
LumenPnP Motherboard
opulo-inc
149 × 95 mm296 parts4LCC-BY-SA-4.03.7k STM32
AxxSolder
AxxAxx
39 × 82.5 mm122 parts2LGPL-3.01.7k STM32
AIOC
skuep
21 × 31.5 mm47 parts2LMIT1.4k STM32
Ferris
pierrechevalier83
208.8 × 86.8 mm102 parts2LSHL-2.11.3k STM32
Module 16S
stuartpittaway
71.1 × 89.6 mm113 parts4LCC-BY-NC-4.01.1k STM32
Djinn
tzarc
192.3 × 150.5 mm216 parts2LCERN-OHL-S-2.0988