
Autonomous-Robot

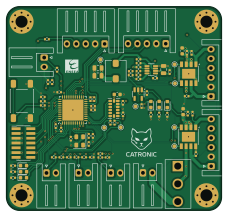
About the Autonomous-Robot PCB
Autonomous-Robot is an open source STM32 PCB design by IKRAMAFIF, published on GitHub. It is a 4-layer board measuring 57 × 54 mm, with 87 components from 42 distinct parts.
Its main chip is the STM32G4316B, from the STM32 family. Other key parts include the MP1475DJ-LF-P, ZXBM5210-SP and ADXL343BCCZ-RL. By type, the board carries 35 capacitors, 26 resistors, 10 connectors, 6 diodes, 5 ICs and 2 switches.
It belongs with the robotics & motion designs in this gallery.
From the project
Le robot CATRONIC est un système embarqué autonome conçu pour simuler un jeu de chat et de souris entre plusieurs robots identiques. Les robots évoluent sur une table sans bordures et sont capables de détecter les bords pour éviter toute chute.
Le robot CATRONIC est un système embarqué autonome conçu pour simuler un jeu de chat et de souris entre plusieurs robots identiques. Les robots évoluent sur une table sans bordures et sont capables de détecter les bords pour éviter toute chute.
La logique du robot est orchestrée par un noyau temps réel (FreeRTOS), permettant de gérer plusieurs tâches simultanément pour une réactivité maximale.
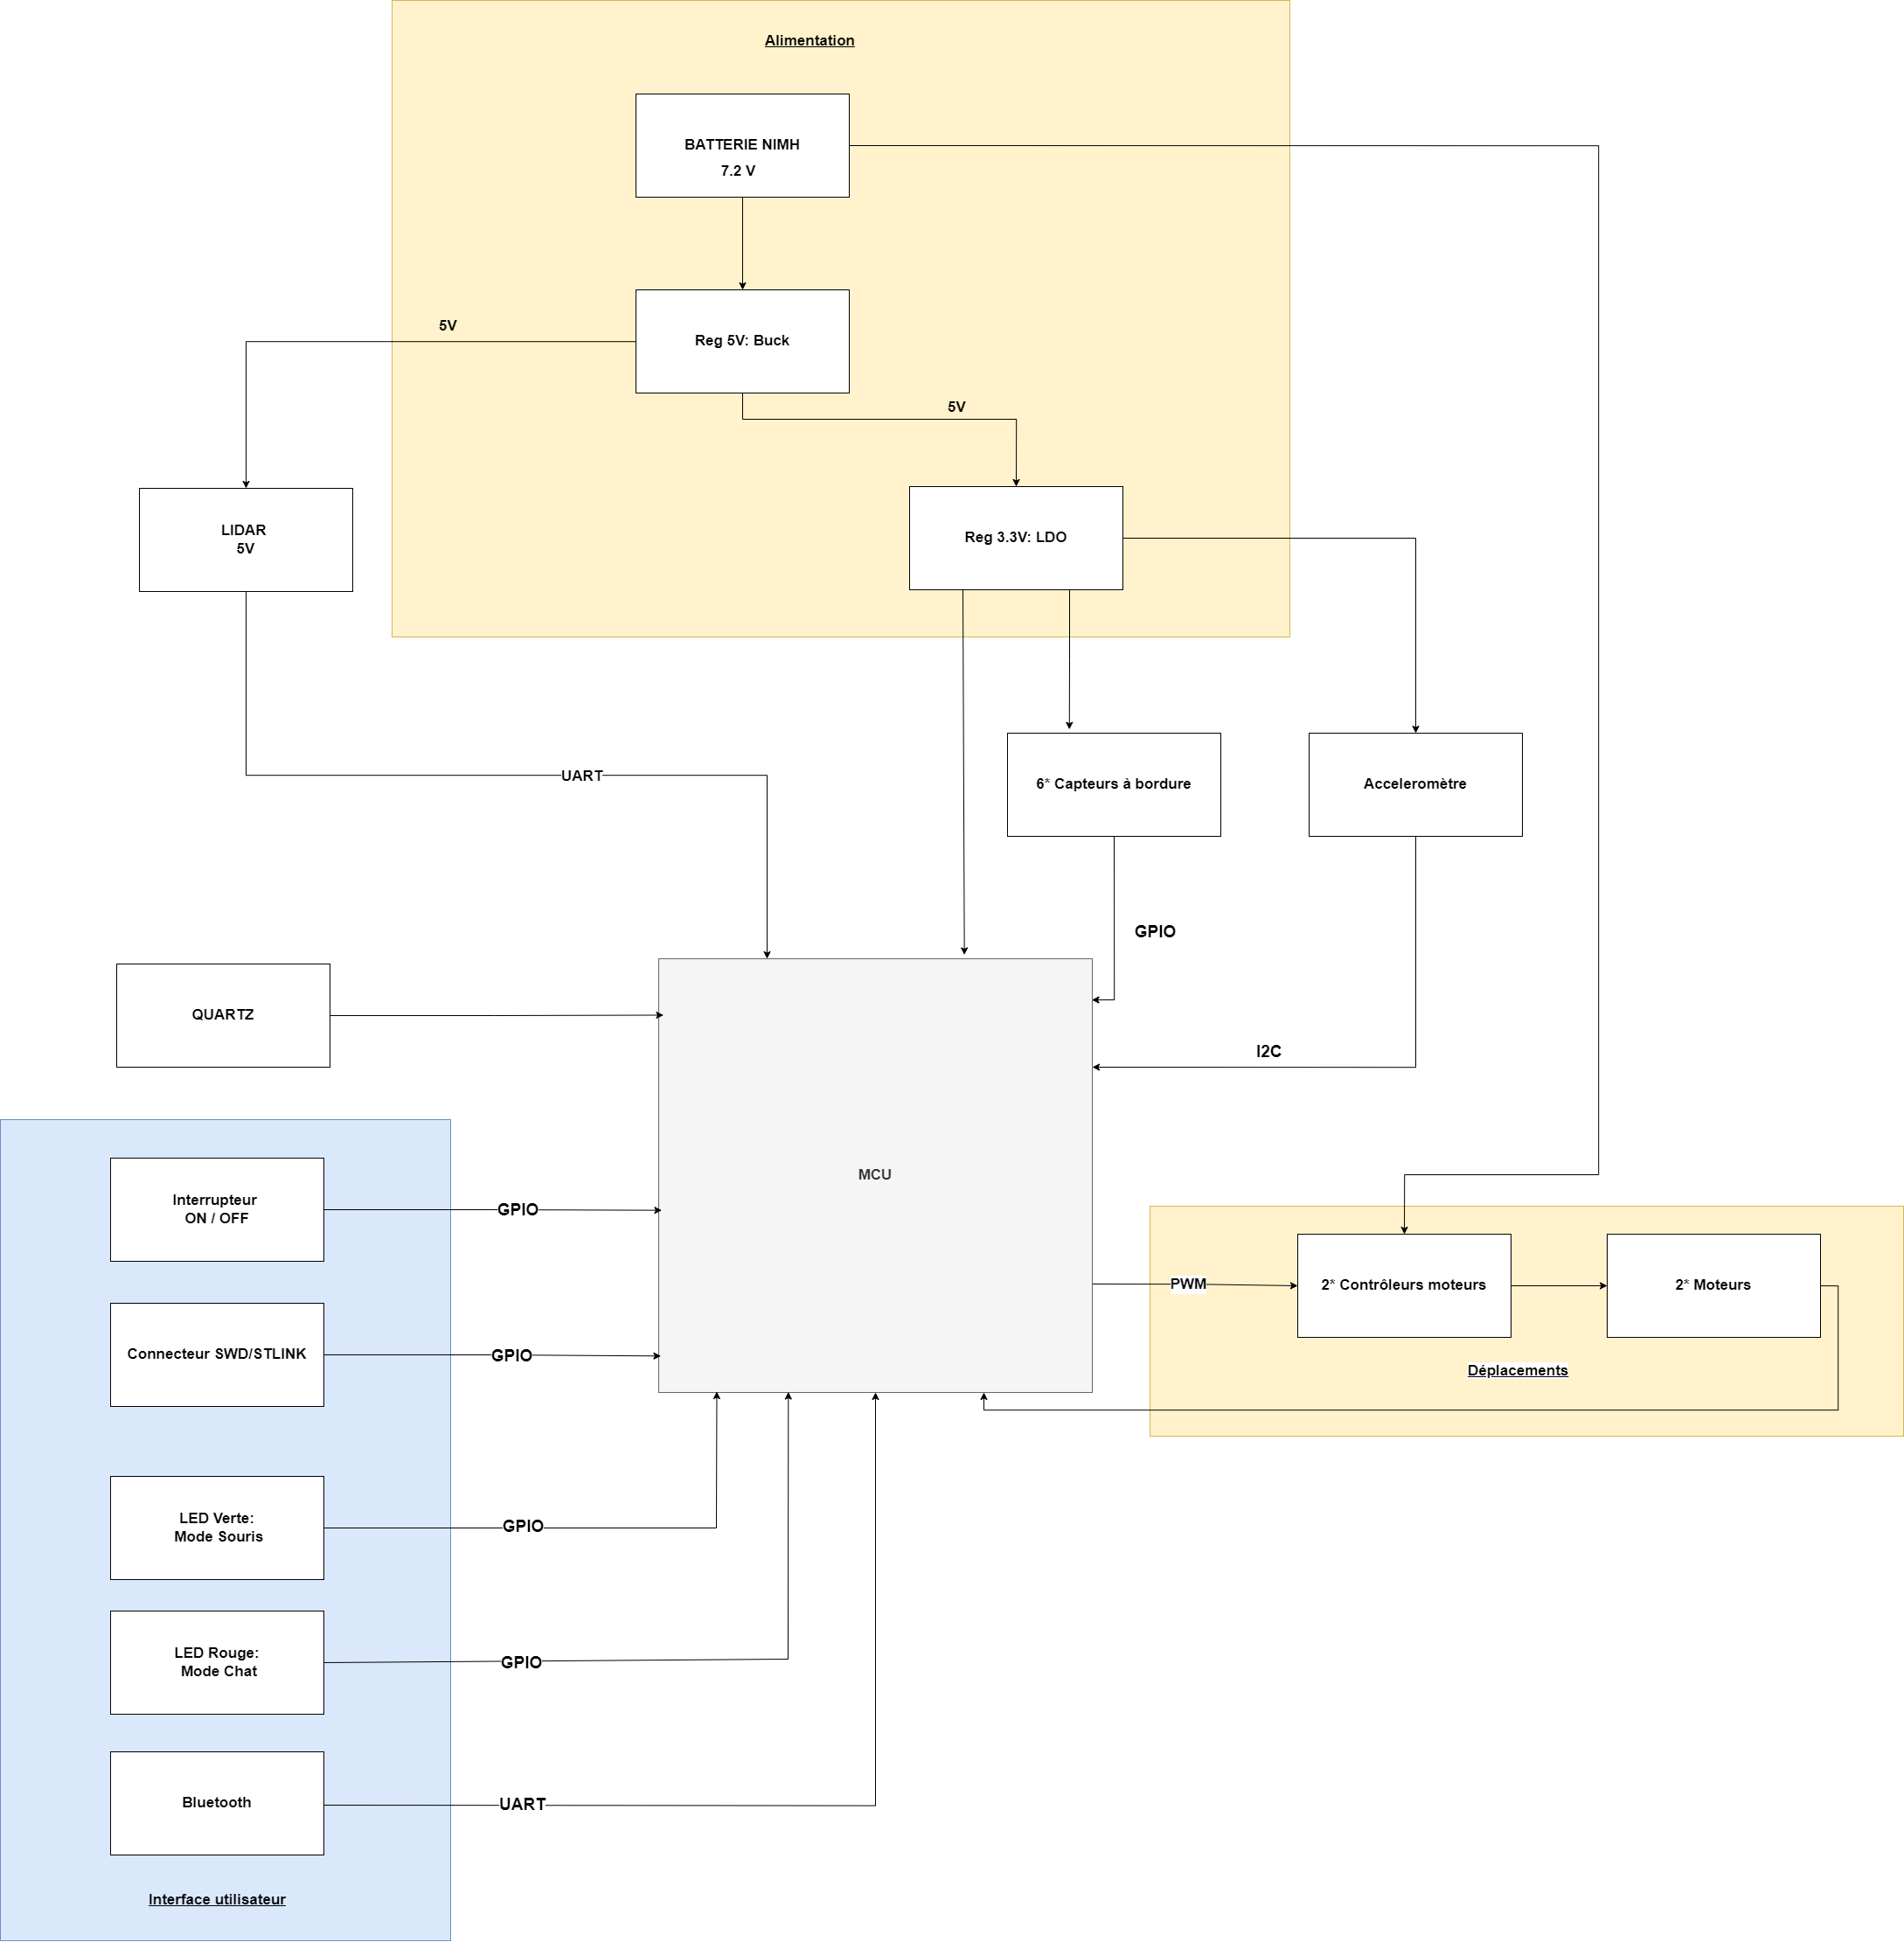
Main components on the Autonomous-Robot
Autonomous-Robot bill of materials (BOM)
87 components, 42 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | MP1475DJ-LF-P | TSOT-23-8 | IC1 |
| 1 | STM32G4316B STM32G431CBUx | QFN-48-1EP_7x7mm_P0.5mm_EP5.6x5.6mm | U1 |
| 2 | ZXBM5210-SP | Diodes_SO-8EP | U2, U3 |
| 1 | ADXL343BCCZ-RL ADXL343 | LGA-14_3x5mm_P0.8mm_LayoutBorder1x6y | U4 |
| 1 | Crystal_GND24_Small | Crystal_SMD_EuroQuartz_MT-4Pin_3.2x2.5mm | Y1 |
| 1 | SAMTEC FTSH-107-01-L-DV-K-A. Conn_ST_STDC14 | PinHeader_2x07_P1.27mm_Vertical_SMD | J1 |
| 1 | Screw_Terminal_01x02 | JST_XH_S2B-XH-A_1x02_P2.50mm_Horizontal | J2 |
| 2 | DfRobot FIT0521 Conn_01x06 | JST_XH_S6B-XH-A_1x06_P2.50mm_Horizontal | J3, J5 |
| 4 | BORDER | JST_XH_S2B-XH-A_1x02_P2.50mm_Horizontal | J4, J7, J8, J9 |
| 1 | YDLIDAR X2 Conn_01x05 | JST_XH_S5B-XH-A_1x05_P2.50mm_Horizontal | J6 |
| 1 | Conn_01x05 | JST_XH_S5B-XH-A_1x05_P2.50mm_Horizontal | J11 |
| 1 | BU33SD5WG-TR | TSOT-23-5 | PS1 |
| 1 | 1101M2S3CQE2 | sw wurth | S1 |
| 1 | SW_Push | SW_Push_1P1T_NO_E-Switch_TL3301NxxxxxG | SW2 |
| 4 | 150060RS55040 LED | LED_0603_1608Metric | D1, D2, D3, D3_PWR_3V1 |
| 1 | 150060GS55040 LED | LED_0603_1608Metric | D1_PWR_BATT1 |
| 1 | 150060BS55040 LED | LED_0603_1608Metric | D2_PWR_5V1 |
| 1 | 4.7uH | L_Wuerth_HCI-5040 | L2 |
| 2 | 10p | C_0402_1005Metric | C1, C2 |
| 1 | 4.7uF | C_0603_1608Metric | C3 |
Show 22 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | 0.47u | C_0402_1005Metric | C4 |
| 10 | 100n | C_0402_1005Metric | C5, C6, C7, C11, C12, C13, C16, C17 +2 |
| 5 | 10n | C_0402_1005Metric | C8, C31, C32, C33, C34 |
| 4 | 1u | C_0402_1005Metric | C9, C10, C15, C19 |
| 2 | 10u | C_0603_1608Metric | C14, C18 |
| 2 | 1uF | C_0402_1005Metric | C20, C23 |
| 3 | 100nF | C_0402_1005Metric | C21, C25, C26 |
| 3 | 22uF | C_0805_2012Metric | C24, C36, C37 |
| 1 | 100uF | C_0402_1005Metric | C27 |
| 1 | 15pF | C_0402_1005Metric | C30 |
| 1 | 10 | R_0402_1005Metric | R1 |
| 1 | 5k5 | R_0402_1005Metric | R2 |
| 1 | 3k3 | R_0402_1005Metric | R3 |
| 4 | 1k6 | R_0402_1005Metric | R4, R7, R8, R9 |
| 4 | 1k | R_0402_1005Metric | R5, R6, R24, R25 |
| 2 | 100k | R_0402_1005Metric | R10, R11 |
| 1 | 20R | R_0402_1005Metric | R12 |
| 1 | 40.2k | R_0402_1005Metric | R13 |
| 1 | 16k | R_0402_1005Metric | R14 |
| 1 | 7.68k | R_0402_1005Metric | R15 |
| 8 | 10k | R_0402_1005Metric | R16, R17, R18, R19, R20, R21, R22, R23 |
| 1 | 470R | R_0402_1005Metric | R26 |
Autonomous-Robot design files
The KiCad project lives in the IKRAMAFIF/Autonomous-Robot repository on GitHub; these links point at the commit this page was built from.
Autonomous-Robot: common questions
What microcontroller does the Autonomous-Robot use?
The Autonomous-Robot is built around the STM32G4316B, from the STM32 family.
How big is the Autonomous-Robot PCB?
The Autonomous-Robot measures 57 × 54 mm, has 4 copper layers and is 1.6 mm thick.
How many components are on the Autonomous-Robot?
87 components, from 42 distinct parts. The full bill of materials is listed on this page.
Where can I download the Autonomous-Robot design files?
From the IKRAMAFIF/Autonomous-Robot repository on GitHub, which has the KiCad layout and the schematic; the links under Design files point to each one.
Can I use the Autonomous-Robot design in my own project?
The repository has no license, so all rights stay with IKRAMAFIF. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the Autonomous-Robot without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug STM32 firmware against it before you order a PCB.
Similar boards
 STM32
LumenPnP Motherboard
opulo-inc
149 × 95 mm296 parts4LCC-BY-SA-4.03.7k STM32
Type g
google
169 × 30 mm24 parts2LApache-2.02.9k STM32
Main panel
234 × 84 mm26 parts4LApache-2.02.9k STM32
Base
52.3 × 52.3 mm36 parts2LApache-2.02.9k STM32
Type a
150 × 30 mm14 parts2LApache-2.02.9k STM32
Type c
188 × 30 mm17 parts2LApache-2.02.9k