
Balance bot

About the Balance bot PCB
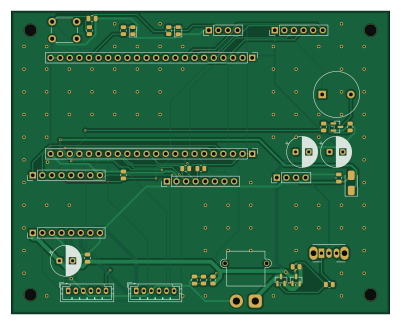
Balance bot is an open source PCB design by MarkDunne, published on GitHub. It is a 2-layer board measuring 100 × 80 mm, with 39 components from 15 distinct parts.
By type, the board carries 12 resistors, 11 connectors, 7 capacitors, 3 transistors, 3 diodes and 2 switches.
It belongs with the robotics & motion designs in this gallery.
From the project
Two-wheel self-balancing robot motherboard PCB — schematic in SKiDL, placement in pcbnew
A two-wheel self-balancing robot. This repo currently holds the hardware design: a passive motherboard PCB that every module plugs into.
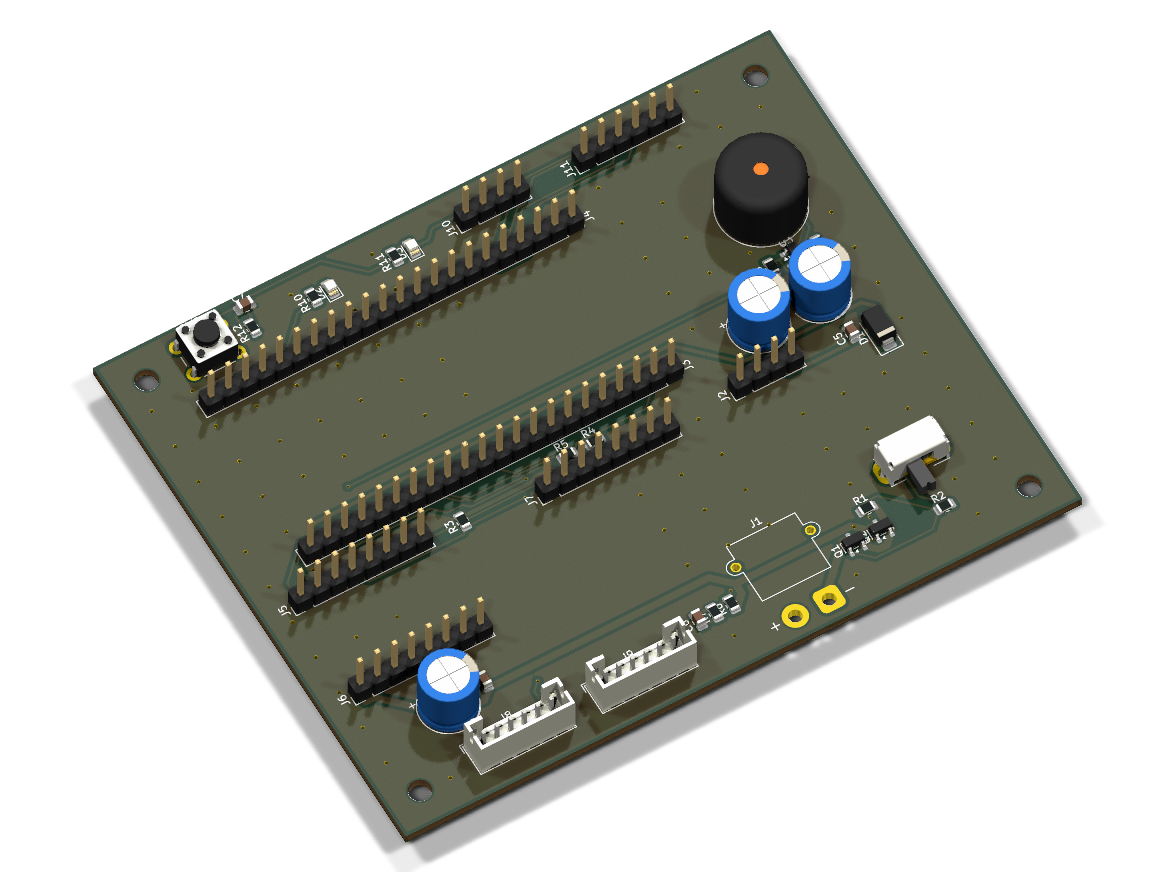
100 × 80mm, 2-layer, routed and poured, DRC-clean. Every image here is generated by just render from the board file — nothing is drawn by hand, including the routing.
- ESP32-S3-DevKitC-1 — controller, socketed - TB6612FNG breakout — dual motor driver, socketed - GY-521 / MPU6050 — 6-axis IMU, socketed - 2S Li-ion — 7.4V nominal, XT30 in, charged off-board - 2 × N20 encoder motors — 6-pin JST-PH each, winding and encoder together
Balance bot bill of materials (BOM)
39 components, 15 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 3 | SOT-23 | SOT-23 | Q1, Q2, Q3 |
| 1 | AMASS_XT30PW-M_1x02_P2.50mm_Horizontal | AMASS_XT30PW-M_1x02_P2.50mm_Horizontal | J1 |
| 2 | PinHeader_1x04_P2.54mm_Vertical | PinHeader_1x04_P2.54mm_Vertical | J2, J10 |
| 2 | PinHeader_1x22_P2.54mm_Vertical | PinHeader_1x22_P2.54mm_Vertical | J3, J4 |
| 3 | PinHeader_1x08_P2.54mm_Vertical | PinHeader_1x08_P2.54mm_Vertical | J5, J6, J7 |
| 2 | JST_PH_B6B-PH-K_1x06_P2.00mm_Vertical | JST_PH_B6B-PH-K_1x06_P2.00mm_Vertical | J8, J9 |
| 1 | PinHeader_1x06_P2.54mm_Vertical | PinHeader_1x06_P2.54mm_Vertical | J11 |
| 1 | Buzzer_12x9.5RM7.6 | Buzzer_12x9.5RM7.6 | BZ1 |
| 1 | SW_Slide_SPDT_Angled_CK_OS102011MA1Q | SW_Slide_SPDT_Angled_CK_OS102011MA1Q | SW1 |
| 1 | SW_PUSH_6mm_H5mm | SW_PUSH_6mm_H5mm | SW2 |
| 1 | D_SMA | D_SMA | D1 |
| 2 | LED_0805_2012Metric | LED_0805_2012Metric | D2, D3 |
| 3 | CP_Radial_D8.0mm_P3.50mm | CP_Radial_D8.0mm_P3.50mm | C1, C3, C4 |
| 4 | C_0805_2012Metric | C_0805_2012Metric | C2, C5, C6, C7 |
| 12 | R_0805_2012Metric | R_0805_2012Metric | R1, R2, R3, R4, R5, R6, R7, R8 +4 |
Balance bot design files
The KiCad project lives in the MarkDunne/balance-bot repository on GitHub; these links point at the commit this page was built from.
Balance bot: common questions
How big is the Balance bot PCB?
The Balance bot measures 100 × 80 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Balance bot?
39 components, from 15 distinct parts. The full bill of materials is listed on this page.
Where can I download the Balance bot design files?
From the MarkDunne/balance-bot repository on GitHub, which has the KiCad layout; the links under Design files point to each one.
Can I use the Balance bot design in my own project?
The repository has no license, so all rights stay with MarkDunne. Use it as a reference, and ask the author before reusing the design.
Similar boards
Stack chan
stack-chan
50 × 50 mm33 parts2LApache-2.01.7k
Cube batteryboard
willem-pennings
95 × 95 mm4 parts2LGPL-3.01.1k
11ua
rene-dev
57.3 × 19 mm26 parts2LGPL-3.0979
Trollerv2
100 × 75 mm33 parts4LGPL-3.0979
Powerstep
95.2 × 71.5 mm28 parts4LGPL-3.0979
Diff driver
32 × 22 mm14 parts2LGPL-3.0979