
Robotic manipulator

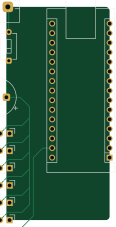
About the Robotic manipulator PCB
Robotic manipulator is an open source AVR/Arduino PCB design by mbed92, published on GitHub under the MIT license. It is a 2-layer board measuring 27.4 × 56.6 mm, with 10 components from 10 distinct parts.
Its main chip is the Arduino_Nano_v3.x, from the AVR/Arduino family. By type, the board carries 7 connectors, 1 module, 1 switch and 1 capacitor.
It belongs with the robotics & motion designs in this gallery.
From the project
Robotic manipulator
- Laptop USB -> Arduino USB - Arduino +5V -> PCA9685 VCC/VDD - Arduino GND -> PCA9685 GND/VSS - Arduino SDA (pin A4) -> PCA9685 SDA - Arduino SCL (pin A5) -> PCA9685 SCL - PSU +5V -> PCA9685 V+ - PSU GND -> PCA9685 GND - SERVO1..6 PWM -> PCA9685 CH1..6 PWM - SERVO1..6 5V -> PCA9685 CH1..6 5V - SERVO1..6 GND -> PCA9685 CH1..6 GND
- Arduino does NOT power the servos. - Servos are powered directly from PSU. - All grounds must be connected together. - PCA9685 generates hardware PWM signals.
Main components on the Robotic manipulator
Robotic manipulator bill of materials (BOM)
10 components, 10 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | Arduino_Nano_v3.x | Arduino_Nano | A1 |
| 1 | SERVO_BASE | PinHeader_1x03_P2.54mm_Vertical | J2 |
| 1 | SERVO_SHOULDER | PinHeader_1x03_P2.54mm_Vertical | J3 |
| 1 | SERVO_ELBOW | PinHeader_1x03_P2.54mm_Vertical | J4 |
| 1 | SERVO_WRIST_PITCH | PinHeader_1x03_P2.54mm_Vertical | J5 |
| 1 | SERVO_WRIST_ROT | PinHeader_1x03_P2.54mm_Vertical | J6 |
| 1 | SERVO_GRIPPER | PinHeader_1x03_P2.54mm_Vertical | J7 |
| 1 | POS-50-5-C2 | TerminalBlock_MaiXu_MX126-5.0-02P_1x02_P5.00mm | J14 |
| 1 | SW_SPST | SW_DIP_SPSTx01_Slide_6.7x4.1mm_W7.62mm_P2.54mm_LowProfile | SW1 |
| 1 | 1000uF / 25V | CP_Radial_D10.0mm_P5.00mm | C1 |
Robotic manipulator design files
The KiCad project lives in the mbed92/robotic-manipulator repository on GitHub; these links point at the commit this page was built from.
- Layoutpcb/project/project.kicad_pcb
- Schematicpcb/project/project.kicad_sch
Robotic manipulator: common questions
What microcontroller does the Robotic manipulator use?
The Robotic manipulator is built around the Arduino_Nano_v3.x, from the AVR/Arduino family.
How big is the Robotic manipulator PCB?
The Robotic manipulator measures 27.4 × 56.6 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Robotic manipulator?
10 components, from 10 distinct parts. The full bill of materials is listed on this page.
Where can I download the Robotic manipulator design files?
From the mbed92/robotic-manipulator repository on GitHub, which has the KiCad layout and the schematic; the links under Design files point to each one.
Can I use the Robotic manipulator design in my own project?
Yes, under the terms of its MIT license, which mbed92 chose for the repository.
Can I test firmware for the Robotic manipulator without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug AVR/Arduino firmware against it before you order a PCB.
Similar boards
 AVR/Arduino
Redox keyboard
mattdibi
162.2 × 126.5 mm77 parts2LMIT2.0k AVR/Arduino
ModuleV450
stuartpittaway
30 × 61.4 mm39 parts2LCC-BY-NC-4.01.1k AVR/Arduino
V4
30 × 50 mm38 parts2LCC-BY-NC-4.01.1k AVR/Arduino
Discipline
coseyfannitutti
304.9 × 122.8 mm170 parts2LCC-BY-NC-4.01.0k AVR/Arduino
Megadesk
gcormier
41.7 × 32.2 mm23 parts2LGPL-3.0818 AVR/Arduino
Easyduino Atmega Nano
Hanqaqa
43.4 × 18 mm30 parts4LCERN-OHL-P-2.0746