
DragonBot

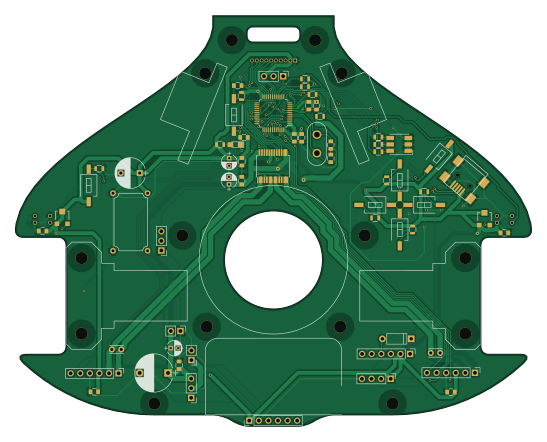
About the DragonBot PCB
DragonBot is an open source STM32 PCB design by OPRobots, published on GitHub under the GPL-2.0 license. It is a 2-layer board measuring 136.6 × 108.6 mm, with 70 components from 35 distinct parts.
Its main chip is the STM32F103C8T6, from the STM32 family. By type, the board carries 11 capacitors, 4 connectors, 4 battery holders, 2 diodes, 1 IC and 1 crystal.
It belongs with the robotics & motion designs in this gallery.
From the project
Robot siguelineas con succión centrifuga y STM32F1
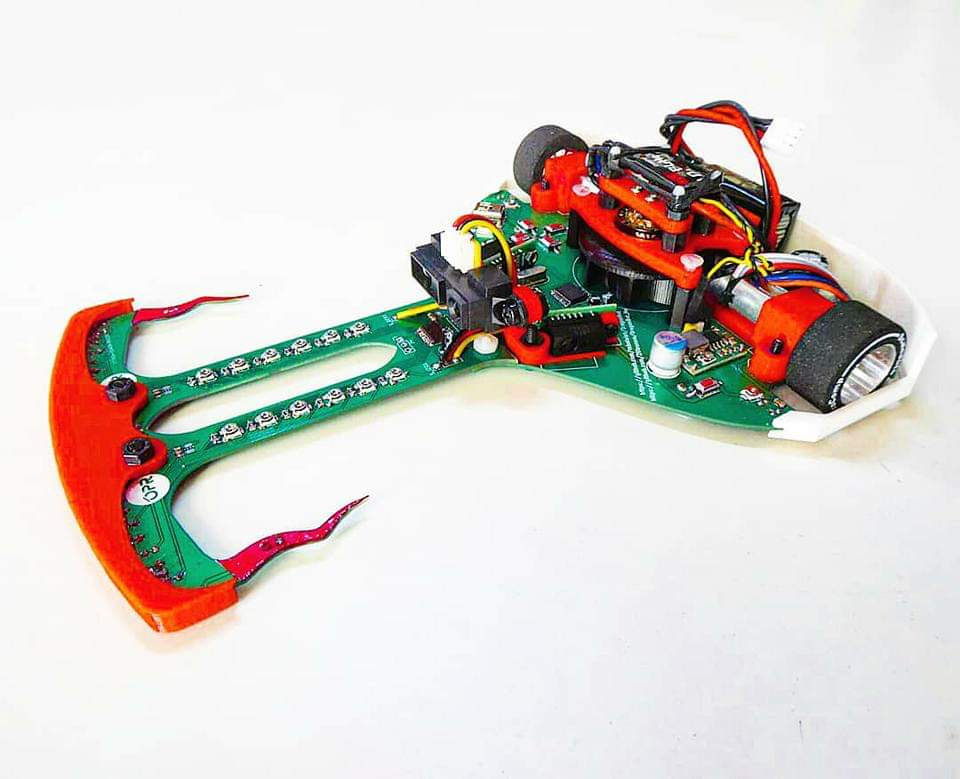
Main components on the DragonBot
DragonBot bill of materials (BOM)
70 components, 35 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | STM32F103C8T6 | LQFP-48_7x7mm_Pitch0.5mm | U1 |
| 1 | Crystal | Crystal_HC50_Vertical | Y2 |
| 1 | Conn_01x10_Male | Pin_Header_Angled_1x10_Pitch1.27mm | J1 |
| 1 | Conn_01x03 | Pin_Header_Straight_1x03_Pitch2.54mm | J2 |
| 1 | Conn_01x02 | Pin_Header_Straight_1x02_Pitch2.54mm | J3 |
| 1 | USB_OTG | USB_Mini-B | J4 |
| 1 | C | C_0805 | 2C100n1 |
| 1 | 100nf | C_0805 | 3C100n1 |
| 16 | R | R_0805 | 4K7R1, 4K7R2, 10K1, 10K2, 18k1, 20k1, 20k2, 36k1 +8 |
| 2 | C20p | C_0805 | 20p1, 20p2 |
| 2 | POT | Potentiometer_Trimmer-EVM3E | 50KP1, 50KP2 |
| 1 | 100K | R_0805 | 100K1 |
| 4 | SW_Push | SW_DIP_x1_W8.61mm_Slide_LowProfile | BT1, BT2, BT3, BT4 |
| 1 | 1000uf | CP_Radial_D10.0mm_P7.50mm | CE1 |
| 1 | 860uf | CP_Radial_D8.0mm_P5.00mm | CE2 |
| 3 | 10uf | CP_Radial_D4.0mm_P2.00mm | CE3, CE4, CE5 |
| 2 | 0.1uf | C_Disc_D3.4mm_W2.1mm_P2.50mm | CM1, CM3 |
| 1 | Conn_01x06_Female | Socket_Strip_Straight_1x06_Pitch2.54mm | FTID1 |
| 1 | Conn_01x02_Male | Pin_Header_Straight_1x02_Pitch2.54mm | JBAT1 |
| 3 | Conn_01x06 | Pin_Header_Straight_1x06_Pitch2.54mm | JGiro1, JM1, JM2 |
Show 15 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | Conn_01x03_Male | Pin_Header_Straight_1x03_Pitch2.54mm | JVENT1 |
| 1 | TB6612FNG | SSOP-24_5.3x8.2mm_Pitch0.65mm | PH1 |
| 2 | QRE1113 | QRE1113 | RBTR1, RBTR2 |
| 3 | SW_Push | SW_DIP_x1_W8.61mm_Slide_LowProfile | RST1, RST2, SWP1 |
| 1 | Step_down_chino | Step_down_chino | STEP1 |
| 1 | Conn_01x04 | Pin_Header_Straight_1x04_Pitch2.54mm | STLINK1 |
| 1 | ON/OFF | Pin_Header_Straight_1x03_Pitch2.54mm | SW1 |
| 1 | LED | LED_0805_HandSoldering | LED_V1 |
| 1 | DIODE | D_A-405_P7.62mm_Horizontal | D1 |
| 1 | LED_RGB | LED_RGB_5050-6 | D2 |
| 2 | C | C_0805 | C1u1, C1uf1 |
| 7 | 0.1uf | C_0805 | C2, C4, C5, C6, C7, C8, C9 |
| 1 | 4.7uF | C_0805 | C4.7u1 |
| 1 | 10nF | C_0805 | C10n1 |
| 1 | R | R_0805 | R150 |
DragonBot design files
The KiCad project lives in the OPRobots/DragonBot repository on GitHub; these links point at the commit this page was built from.
DragonBot: common questions
What microcontroller does the DragonBot use?
The DragonBot is built around the STM32F103C8T6, from the STM32 family.
How big is the DragonBot PCB?
The DragonBot measures 136.6 × 108.6 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the DragonBot?
70 components, from 35 distinct parts. The full bill of materials is listed on this page.
Where can I download the DragonBot design files?
From the OPRobots/DragonBot repository on GitHub, which has the KiCad layout; the links under Design files point to each one.
Can I use the DragonBot design in my own project?
Yes, under the terms of its GPL-2.0 license, which OPRobots chose for the repository.
Can I test firmware for the DragonBot without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug STM32 firmware against it before you order a PCB.
More boards in DragonBot
Similar boards
 STM32
LumenPnP Motherboard
opulo-inc
149 × 95 mm296 parts4LCC-BY-SA-4.03.7k STM32
Type g
google
169 × 30 mm24 parts2LApache-2.02.9k STM32
Main panel
234 × 84 mm26 parts4LApache-2.02.9k STM32
Base
52.3 × 52.3 mm36 parts2LApache-2.02.9k STM32
Type a
150 × 30 mm14 parts2LApache-2.02.9k STM32
Type c
188 × 30 mm17 parts2LApache-2.02.9k