
Quaternion attitude control

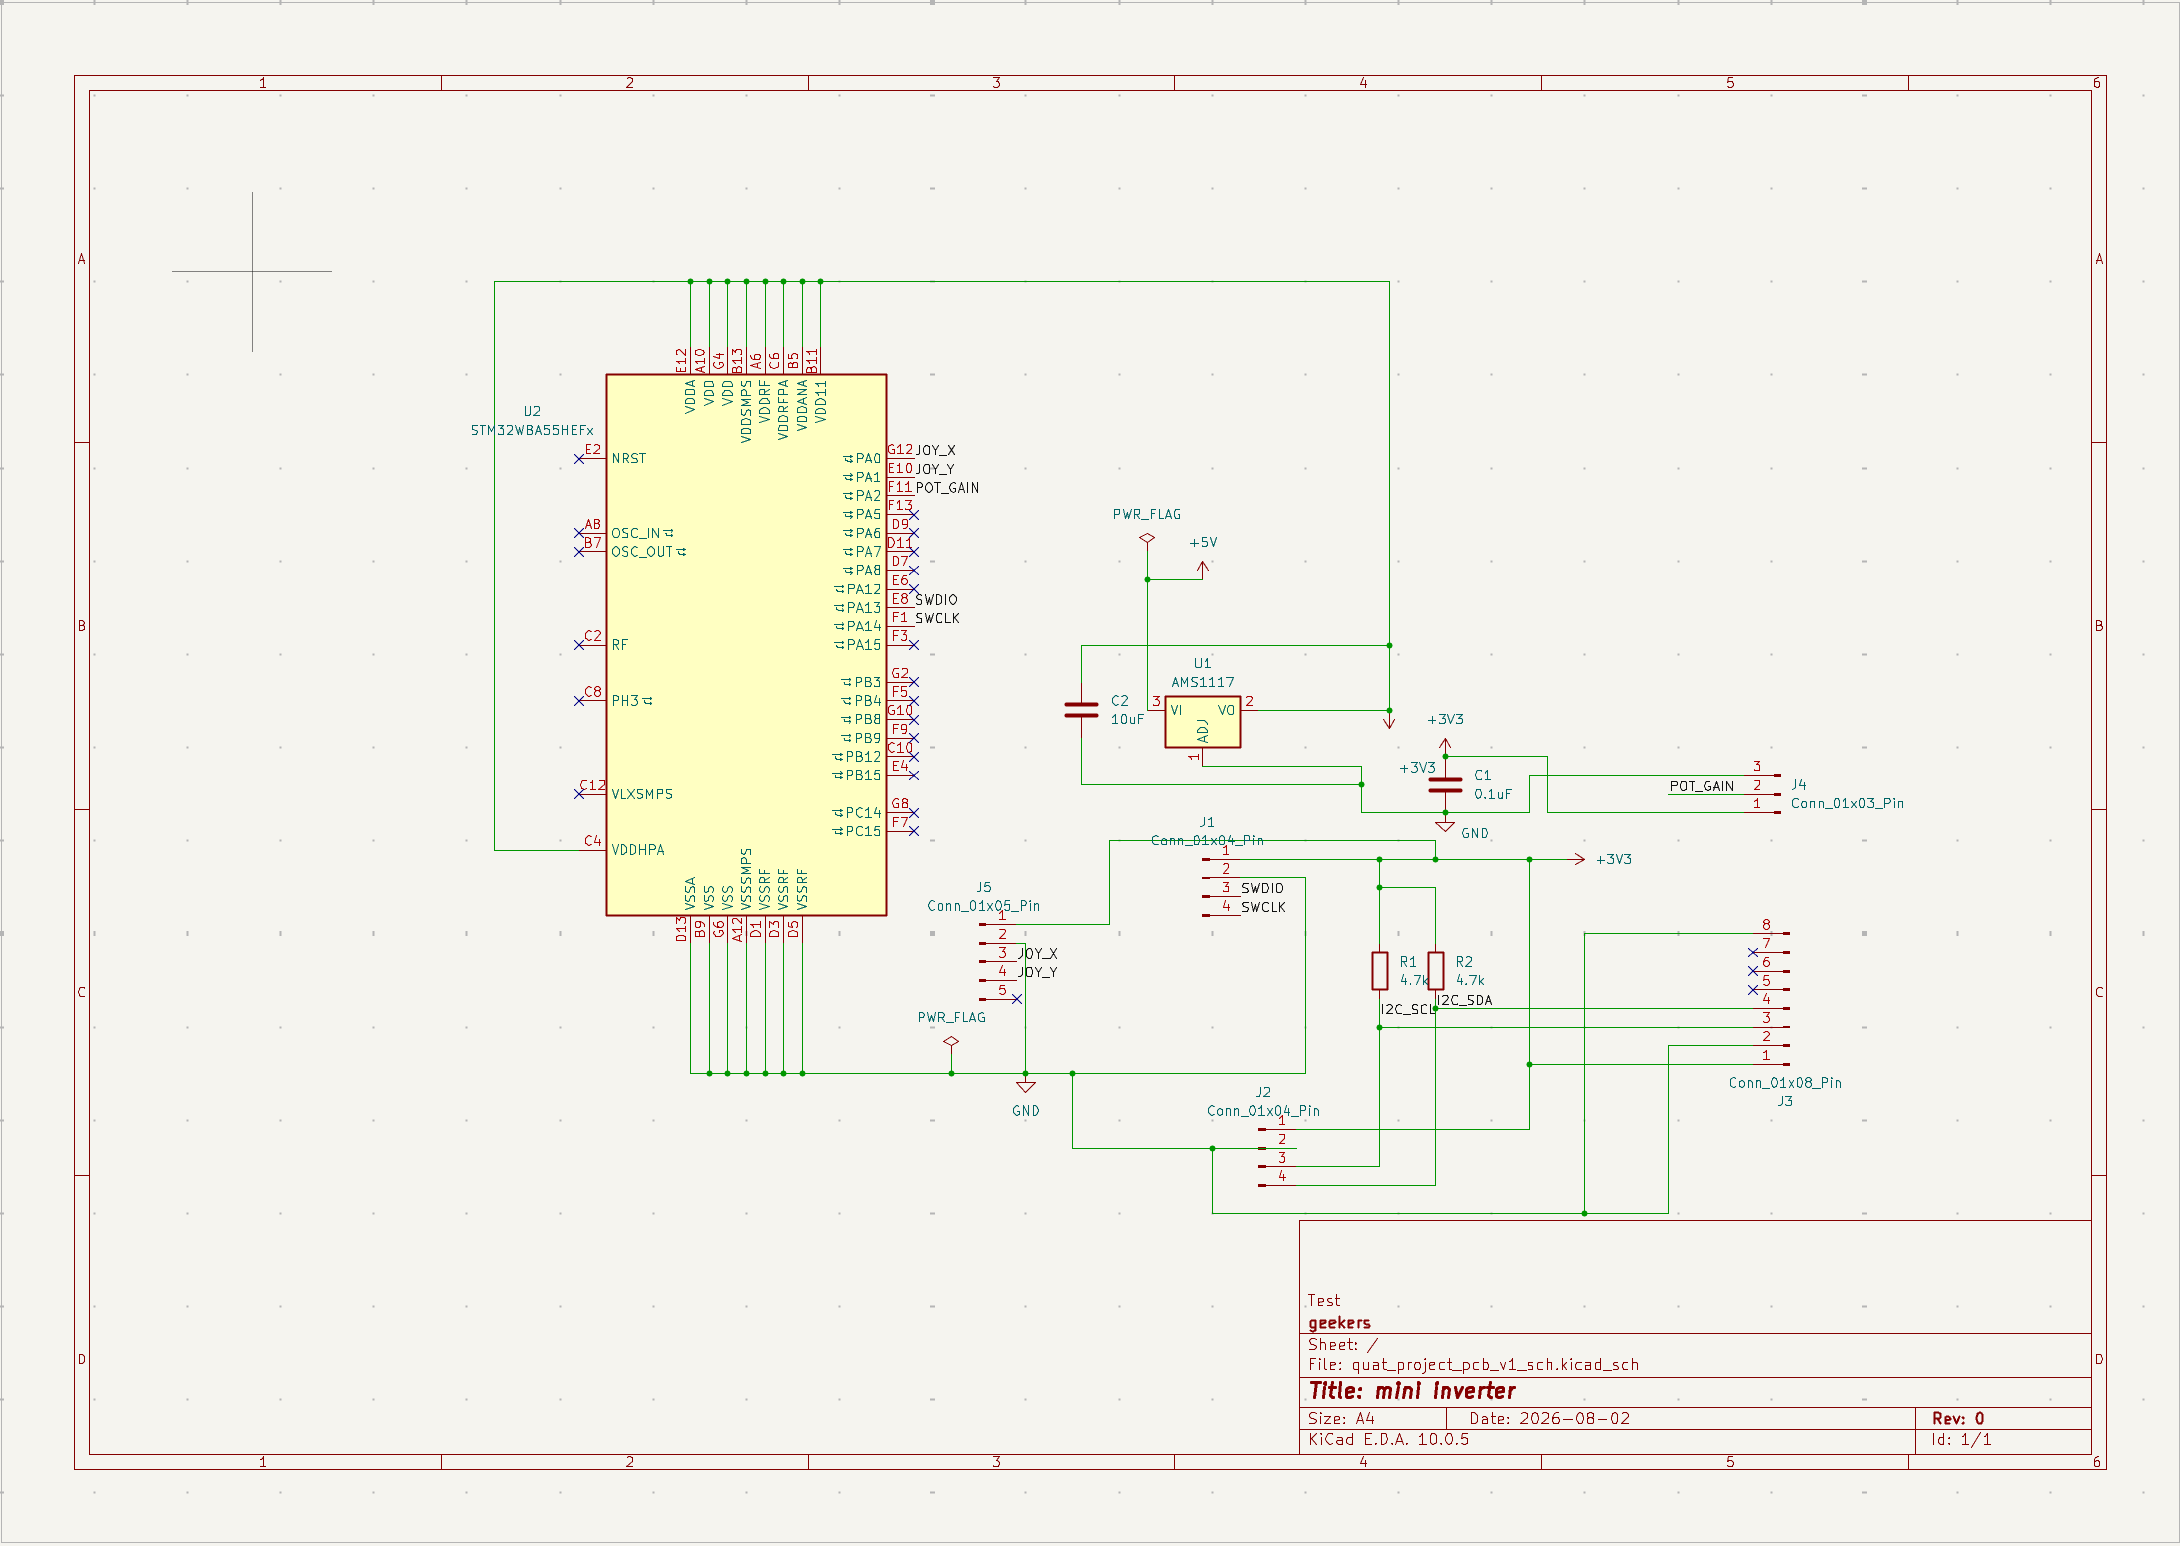
About the Quaternion attitude control PCB
Quaternion attitude control is an open source STM32 PCB design by raahimnawaz, published on GitHub under the MIT license. It is a board, with 11 components from 10 distinct parts.
Its main chip is the STM32WBA55HEFx, from the STM32 family. Other key parts include the AMS1117. By type, the board carries 5 connectors, 2 ICs, 2 capacitors and 2 resistors.
It belongs with the sensors and displays & leds designs in this gallery.
From the project
Quaternion attitude estimation and control on an FPU-less ATmega2560 against a simulated rigid-body plant: Mahony fusion, PD on quaternion error, and an honest read of what the unwinding fix does and does not buy.
Quaternion-based attitude determination and control for a rigid body in orbit, running on an ATmega2560 against a physics plant simulated in a custom Wokwi chip. The MCU never sees the true attitude — it estimates it from a noisy accelerometer and gyroscope, and closes a PD loop on quaternion error.
The interesting constraint is that the AVR has no floating-point unit. Every sin, sqrt and quaternion product is a software routine, and the control loop still has to close at a usable rate.
Main components on the Quaternion attitude control
Quaternion attitude control bill of materials (BOM)
11 components, 10 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | AMS1117 | SOT-223-3_TabPin2 | U1 |
| 1 | STM32WBA55HEFx | ST_WLCSP-41_2.98x2.76mm_Layout13x7_P0.4mm_Stagger | U2 |
| 1 | Conn_01x04_Pin | PinSocket_1x04_P2.54mm_Vertical | J1 |
| 1 | Conn_01x04_Pin | PinHeader_1x04_P2.54mm_Vertical | J2 |
| 1 | Conn_01x08_Pin | PinHeader_1x08_P2.54mm_Vertical | J3 |
| 1 | Conn_01x03_Pin | PinSocket_1x03_P2.54mm_Vertical | J4 |
| 1 | Conn_01x05_Pin | PinSocket_1x05_P2.54mm_Vertical | J5 |
| 1 | 0.1uF | C_0805_2012Metric | C1 |
| 1 | 10uF | C_0805_2012Metric | C2 |
| 2 | 4.7k | R_0805_2012Metric | R1, R2 |
Quaternion attitude control design files
The KiCad project lives in the raahimnawaz/quaternion-attitude-control repository on GitHub; these links point at the commit this page was built from.
Quaternion attitude control: common questions
What microcontroller does the Quaternion attitude control use?
The Quaternion attitude control is built around the STM32WBA55HEFx, from the STM32 family.
How many components are on the Quaternion attitude control?
11 components, from 10 distinct parts. The full bill of materials is listed on this page.
Where can I download the Quaternion attitude control design files?
From the raahimnawaz/quaternion-attitude-control repository on GitHub, which has the schematic; the links under Design files point to each one.
Can I use the Quaternion attitude control design in my own project?
Yes, under the terms of its MIT license, which raahimnawaz chose for the repository.
Can I test firmware for the Quaternion attitude control without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug STM32 firmware against it before you order a PCB.
Similar boards
 STM32
LumenPnP Motherboard
opulo-inc
149 × 95 mm296 parts4LCC-BY-SA-4.03.7k STM32
Type c
google
188 × 30 mm17 parts2LApache-2.02.9k STM32
Base
52.3 × 52.3 mm36 parts2LApache-2.02.9k STM32
Main panel
234 × 84 mm26 parts4LApache-2.02.9k STM32
Type a
150 × 30 mm14 parts2LApache-2.02.9k STM32
Type e
140.5 × 30 mm13 parts2LApache-2.02.9k