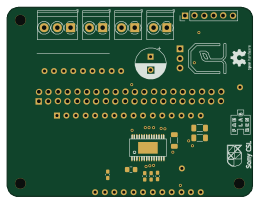
Cablebot controller

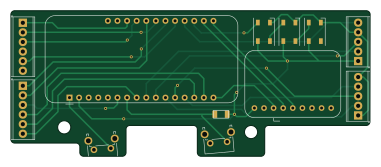
About the Cablebot controller PCB
Cablebot controller is an open source PCB design by romi, published on GitHub under the GPL-3.0 license. It is a 2-layer board measuring 95.1 × 38.5 mm, with 12 components from 8 distinct parts.
Other key parts include the Adafruit_Feather_M0_Basic_Proto. By type, the board carries 4 connectors, 3 diodes, 2 switches, 1 module and 1 resistor.
From the project
Just one set is needed either small or big, depending on cable tension (big is better for high tension).
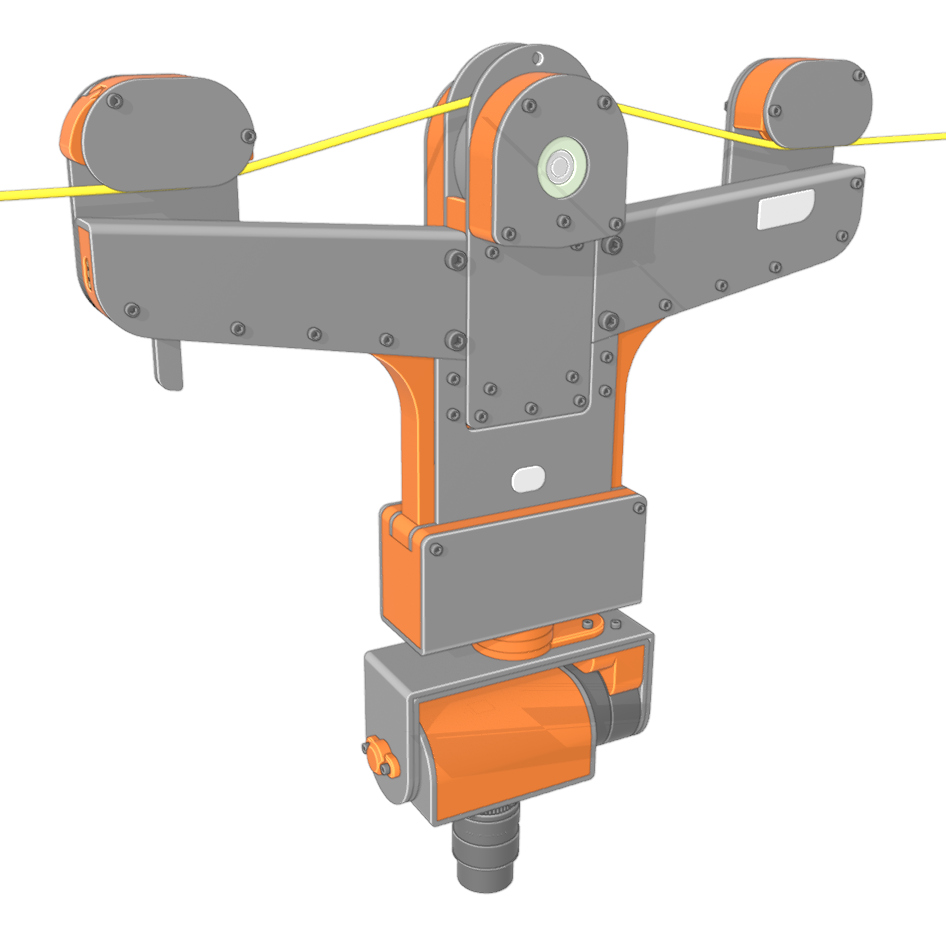
Main components on the Cablebot controller
Cablebot controller bill of materials (BOM)
12 components, 8 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | Adafruit_Feather_M0_Basic_Proto | Adafruit_Feather | A1 |
| 2 | Screw_Terminal_01x06 | TerminalBlock_Phoenix_MPT-0,5-6-2.54_1x06_P2.54mm_Horizontal | J2, J3 |
| 2 | Screw_Terminal_01x05 | TerminalBlock_Phoenix_MPT-0,5-5-2.54_1x05_P2.54mm_Horizontal | J4, J5 |
| 1 | ACCEL | Adafruit-LSM6DSOX-PCB | JN1 |
| 1 | SW_SPST | SW_Tactile_SPST_Angled_PTS645Vx83-2LFS | SW1 |
| 1 | SW_SPST | SW_Tactile_SPST_Angled_PTS645Vx58-2LFS | SW2 |
| 3 | WS2812B | LED_WS2812B_PLCC4_5.0x5.0mm_P3.2mm | D1, D2, D3 |
| 1 | 1kΩ | fab-R1206FAB | R1 |
Cablebot controller design files
The KiCad project lives in the romi/romi-cablebot repository on GitHub; these links point at the commit this page was built from.
Cablebot controller: common questions
How big is the Cablebot controller PCB?
The Cablebot controller measures 95.1 × 38.5 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Cablebot controller?
12 components, from 8 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Cablebot controller design files?
From the romi/romi-cablebot repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the Cablebot controller design in my own project?
Yes, under the terms of its GPL-3.0 license, which romi chose for the repository.