
Rosmo ESC

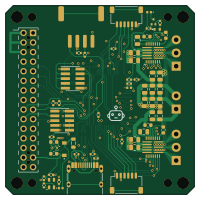
About the Rosmo ESC PCB
Rosmo ESC is an open source STM32 PCB design by rosmo-robot, published on GitHub under the CERN-OHL-P-2.0 license. It is a 4-layer board measuring 50 × 50 mm, with 105 components from 41 distinct parts.
Its main chip is the STM32G491MET6, from the STM32 family. Other key parts include the PRTR5V0U2F, MPS6540H and MIC5524-3.3YMT-T5. By type, the board carries 46 capacitors, 34 resistors, 10 connectors, 6 diodes, 5 ICs and 1 transistor.
It belongs with the robotics & motion and sensors designs in this gallery.
From the project
Dual brushless motor ESC in #M5Stack module format
Design for Rosmo ESC - in M5Stack format.
Dual brushless motor ESC in M5-Stack module format Drives 2x 3-phase BLDC motors with up to 40V and 5A (cooling needed - to be tested) 2x SPI sensors supported, such as MA732, MA730, AS5048A, AS5047, etc... Control inputs via SPI, I2C (and GPIO:question:) * Grove port for I2C input/output
:warning: In development, prototype boards on order.
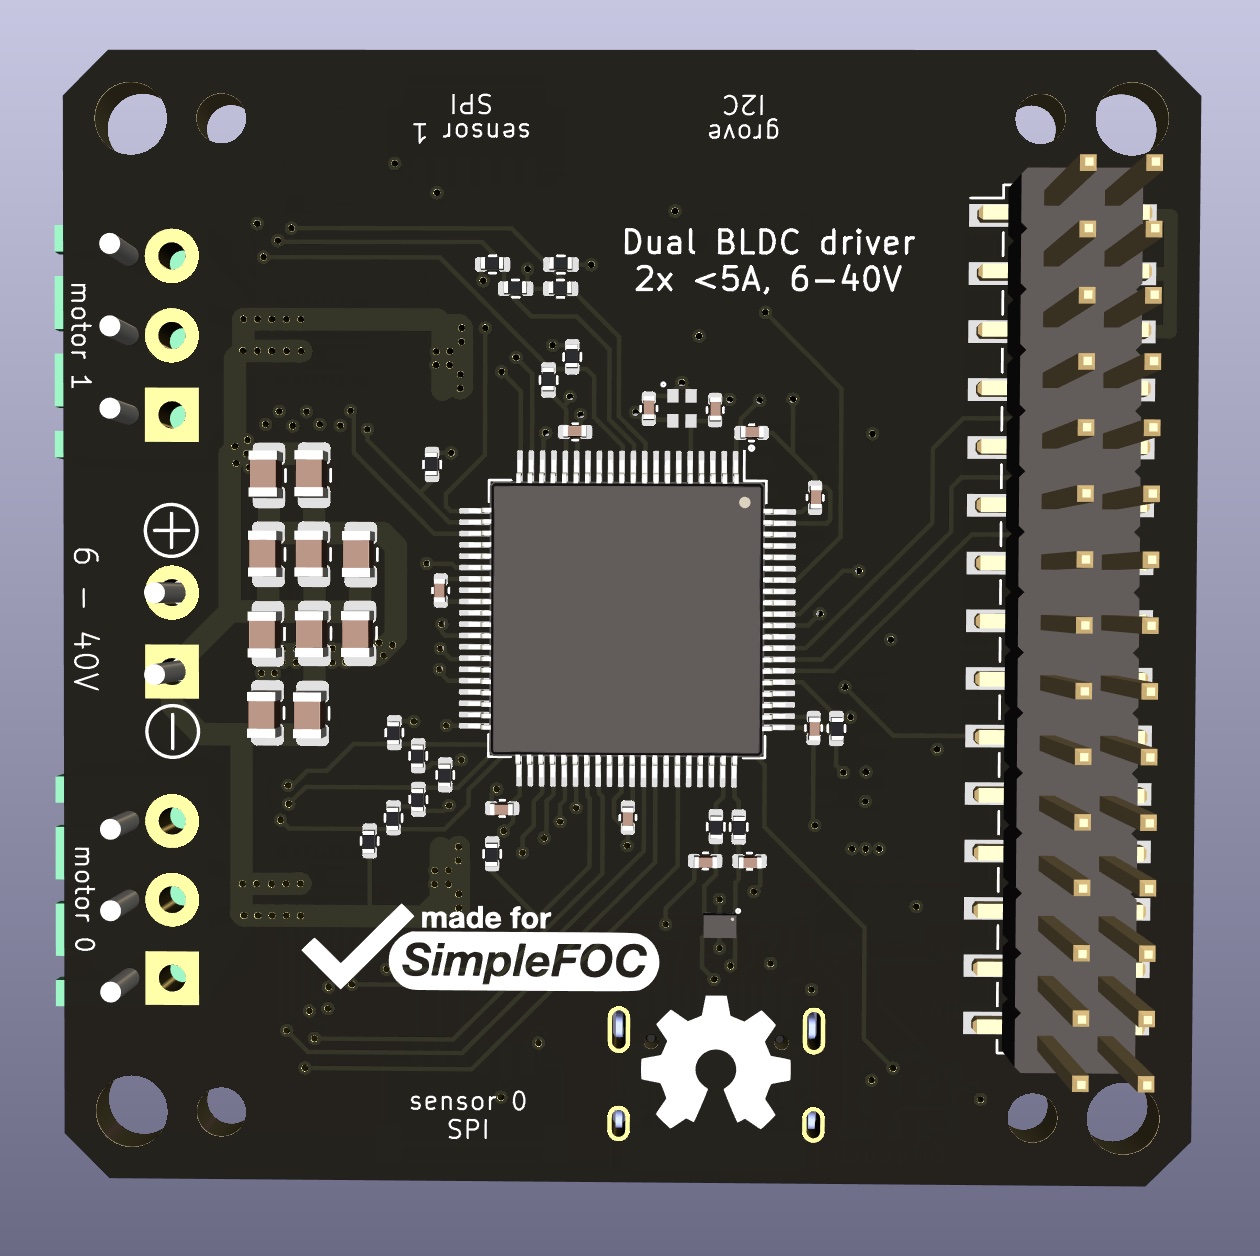
Main components on the Rosmo ESC
Rosmo ESC bill of materials (BOM)
105 components, 41 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | STM32G491MET6 | LQFP-80_12x12mm_P0.5mm | U1 |
| 1 | PRTR5V0U2F | SOT-886 | U2 |
| 2 | MPS6540H | MPS6540H | U3, U4 |
| 1 | MIC5524-3.3YMT-T5 | TDFN-4-1EP_1x1mm_P0.65mm_EP0.5x0.5mm | U5 |
| 1 | BC847BTT1G | SOT-416 | Q1 |
| 1 | 25MHz | Oscillator_SMD_Abracon_ASCO-4Pin_1.6x1.2mm | X1 |
| 1 | M-BUS | BF@M5Stack_MBUS | J1 |
| 1 | USB_C_Receptacle_USB2.0 | USB_C_Receptacle_HRO_TYPE-C-31-M-12 | J2 |
| 1 | Conn_01x04_MountingPin | Grove_A2006WF-04A | J3 |
| 2 | Conn_02x05 | PinHeader_2x05_P1.27mm_Vertical_SMD | J4, J10 |
| 2 | JST_SH_SM06B-SRSS-TB_1x06-1MP | JST_SH_SM06B-SRSS-TB_1x06-1MP_P1.00mm_Horizontal | J5, J6 |
| 2 | Conn_01x03 | TerminalBlock_Phoenix_PT-1,5-3-3.5-H_1x03_P3.50mm_Horizontal | J7, J8 |
| 1 | Conn_01x02 | TerminalBlock_Phoenix_PT-1,5-2-3.5-H_1x02_P3.50mm_Horizontal | J9 |
| 1 | M-BUS | PinHeader_2x15_P2.54mm_Vertical_SMD | JB1 |
| 1 | PMEG40T10ER | D_SOD-123 | D1 |
| 2 | green | LED_0402_1005Metric | D2, D3 |
| 1 | SK6805 | LED_SK6805_PLCC4_2.4x2.7mm_P1.3mm | D4 |
| 1 | SC1333-01ETG | D_0402_1005Metric | D5 |
| 1 | 2.84V | D_SOD-523 | D6 |
| 1 | 40Ω@100Mhz | L_0805_2012Metric | FB1 |
Show 21 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 9 | 100nF 6.3V | C_0402_1005Metric | C1, C3, C4, C5, C6, C7, C8, C12 +1 |
| 1 | 10pF 6.3V 5% | C_0402_1005Metric | C2 |
| 2 | 47pF 10V | C_0402_1005Metric | C9, C10 |
| 1 | 10nF 10V | C_0402_1005Metric | C11 |
| 1 | 100nF 50V 5% | C_0402_1005Metric | C13 |
| 2 | 10nF 75V | C_0805_2012Metric | C14, C19 |
| 4 | 100nF 75V | C_0805_2012Metric | C15, C17, C20, C22 |
| 2 | 1uF 16V | C_0603_1608Metric | C16, C21 |
| 2 | 4.7uF 16V | C_0603_1608Metric | C18, C23 |
| 20 | 10uF 50V | C_0805_2012Metric | C25, C26, C27, C28, C29, C30, C31, C32 +12 |
| 2 | 2.2uF 16V | C_0603_1608Metric | C45, C46 |
| 4 | 2k2 | R_0402_1005Metric | R1, R2, R32, R33 |
| 8 | 5k1 | R_0402_1005Metric | R3, R4, R8, R9, R10, R11, R14, R34 |
| 2 | 27R | R_0402_1005Metric | R5, R6 |
| 1 | 4k7 | R_0402_1005Metric | R7 |
| 1 | 47k 1% | R_0402_1005Metric | R12 |
| 3 | 10k | R_0402_1005Metric | R13, R18, R25 |
| 1 | 300R | R_0402_1005Metric | R15 |
| 1 | 2.2k 1% | R_0402_1005Metric | R16 |
| 1 | 200Ω | R_0402_1005Metric | R17 |
| 12 | 2k2 0.5% | R_0402_1005Metric | R19, R20, R21, R22, R23, R24, R26, R27 +4 |
Rosmo ESC design files
The KiCad project lives in the rosmo-robot/Rosmo_ESC repository on GitHub; these links point at the commit this page was built from.
- LayoutRosmo_ESC.kicad_pcb
- SchematicRosmo_ESC.kicad_sch
Rosmo ESC: common questions
What microcontroller does the Rosmo ESC use?
The Rosmo ESC is built around the STM32G491MET6, from the STM32 family.
How big is the Rosmo ESC PCB?
The Rosmo ESC measures 50 × 50 mm, has 4 copper layers and is 1.72 mm thick.
How many components are on the Rosmo ESC?
105 components, from 41 distinct parts. The full bill of materials is listed on this page.
Where can I download the Rosmo ESC design files?
From the rosmo-robot/Rosmo_ESC repository on GitHub, which has the KiCad layout and the schematic; the links under Design files point to each one.
Can I use the Rosmo ESC design in my own project?
Yes, under the terms of its CERN-OHL-P-2.0 license, which rosmo-robot chose for the repository.
Can I test firmware for the Rosmo ESC without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug STM32 firmware against it before you order a PCB.
Similar boards
 STM32
LumenPnP Motherboard
opulo-inc
149 × 95 mm296 parts4LCC-BY-SA-4.03.7k STM32
AxxSolder
AxxAxx
39 × 82.5 mm122 parts2LGPL-3.01.7k STM32
AIOC
skuep
21 × 31.5 mm47 parts2LMIT1.4k STM32
Ferris
pierrechevalier83
208.8 × 86.8 mm102 parts2LSHL-2.11.3k STM32
176 pin board
rusefi
61.8 × 73.2 mm76 parts2LGPL-3.01.2k STM32
Brain board STM32F407
61.8 × 73.2 mm69 parts2LGPL-3.01.2k