
IMU-Turntable

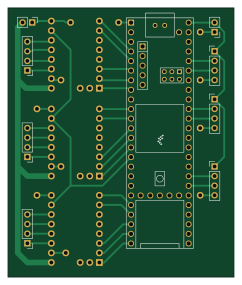
About the IMU-Turntable PCB
IMU-Turntable is an open source NXP PCB design by UpsidedownFalcon, published on GitHub under the GPL-3.0 license. It is a 2-layer board measuring 59.7 × 71.1 mm, with 12 components from 12 distinct parts.
Its main chip is the Teensy4.1, from the NXP family. Other key parts include the TMC2209_X, TMC2209_Y and TMC2209_Z. By type, the board carries 8 connectors and 4 ICs.
It belongs with the sensors and robotics & motion designs in this gallery.
From the project
Open source IMU turntable research project
# High-Tech Fidget Spinner: 3-Axis IMU Turntable
This is an open-source project for the construction of a 3-DoF IMU turntable, called the "High-Tech Fidget Spinner". It is a low-cost alternative to commercial solutions which can cost in the 5 to 6-figure USD range, to be used for the validation and characterisation of IMU sensors.
The repository contains supporting files to the conference paper titled "High-Tech Fidget Spinner: Open-Source 3-Axis Turntable" from UbiComp Companion ’25, October 12–16, 2025, Espoo, Finland: https://doi.org/10.1145/3714394.3756256
Main components on the IMU-Turntable
IMU-Turntable bill of materials (BOM)
12 components, 12 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | Teensy4.1 | Teensy41 | U1 |
| 1 | TMC2209_X | TMC2209 | U2 |
| 1 | TMC2209_Y | TMC2209 | U3 |
| 1 | TMC2209_Z | TMC2209 | U4 |
| 1 | +24V | PinHeader_1x02_P2.54mm_Vertical | J1 |
| 1 | +5V | PinHeader_1x02_P2.54mm_Vertical | J2 |
| 1 | Stepper Motor_X | PinHeader_1x04_P2.54mm_Vertical | J3 |
| 1 | Stepper Motor_Y | PinHeader_1x04_P2.54mm_Vertical | J4 |
| 1 | Stepper Motor_Z | PinHeader_1x04_P2.54mm_Vertical | J5 |
| 1 | Rotary Encoder_X | PinHeader_1x04_P2.54mm_Vertical | J6 |
| 1 | Rotary Encoder_Y | PinHeader_1x04_P2.54mm_Vertical | J7 |
| 1 | Rotary Encoder_Z | PinHeader_1x04_P2.54mm_Vertical | J8 |
IMU-Turntable design files
The KiCad project lives in the UpsidedownFalcon/IMU-Turntable repository on GitHub; these links point at the commit this page was built from.
IMU-Turntable: common questions
What microcontroller does the IMU-Turntable use?
The IMU-Turntable is built around the Teensy4.1, from the NXP family.
How big is the IMU-Turntable PCB?
The IMU-Turntable measures 59.7 × 71.1 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the IMU-Turntable?
12 components, from 12 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the IMU-Turntable design files?
From the UpsidedownFalcon/IMU-Turntable repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the IMU-Turntable design in my own project?
Yes, under the terms of its GPL-3.0 license, which UpsidedownFalcon chose for the repository.
Can I test firmware for the IMU-Turntable without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug NXP firmware against it before you order a PCB.
Similar boards
 NXP
32Bit shift register
MaltWhiskey
100 × 54 mm56 parts4LNo license763 NXP
Mega-Cube-Board
200 × 54 mm100 parts4LNo license763 NXP
MCL6809
MicroCoreLabs
32.3 × 61 mm7 parts4LNo license532 NXP
MCL68
31.6 × 84.1 mm13 parts4LNo license532 NXP
MCL65+
72.6 × 64.1 mm6 parts2LNo license532 NXP
MCLZ8
37.1 × 61.5 mm6 parts4LNo license532