
Pheeno robot electronic schematics

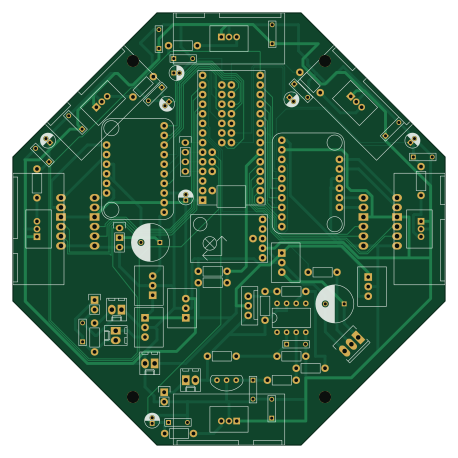
About the Pheeno robot electronic schematics PCB
Pheeno robot electronic schematics is an open source NXP PCB design by ACSLaboratory, published on GitHub under the BSD-3-Clause license. It is a 2-layer board measuring 114.3 × 114.3 mm, with 70 components from 33 distinct parts.
Its main chip is the Teensy3.2, from the NXP family. Other key parts include the LP2950 and OKI-78SR. By type, the board carries 23 capacitors, 16 resistors, 9 connectors, 7 ICs, 2 switches and 1 transistor.
It belongs with the robotics & motion designs in this gallery.
From the project
Electronic schematics for the Pheeno robot!
This is the ACSLab GitHub repository for the files relating to the electronic construction of the Pheeno robot platform. Pheeno is designed to be an inexpensive (cost of parts = $420), research-level platform for multi-robot experiments, robotics education, and outreach activities. This repository will be updated with additional modules, code, and improvements to existing modules as they are developed.
Main components on the Pheeno robot electronic schematics
Pheeno robot electronic schematics bill of materials (BOM)
70 components, 33 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | LP2950 | LP2950 | U1 |
| 5 | OKI-78SR | OKI-78SR | U2, U3, U4, U5, U7 |
| 1 | Teensy3.2 | Teensy3.2 | U6 |
| 1 | IRF9530 | IRF9530 | Q1 |
| 1 | 12V Power | Molex_KK-6410-02_02x2.54mm_Straight | P1 |
| 1 | Raspberry Pi Power | Pin_Header_Straight_1x02 | P2 |
| 1 | Color Control GPIO | Socket_MOLEX-KK-RM2-54mm_Lock_3pin_straight | P3 |
| 1 | Camera Servo Control | Pin_Header_Straight_1x03 | P4 |
| 1 | RHBridge_Right Motor Connector | Molex_KK-6410-06_06x2.54mm_Straight | P5 |
| 1 | RHBridge_Left Motor Connector | Molex_KK-6410-06_06x2.54mm_Straight | P6 |
| 1 | LHBridge_Right Motor Connector | Molex_KK-6410-06_06x2.54mm_Straight | P7 |
| 1 | LHBridge_Left Motor Connector | Molex_KK-6410-06_06x2.54mm_Straight | P8 |
| 1 | GPIO JUMPER | Pin_Header_Straight_1x04 | P9 |
| 1 | 11.1V | Pin_Header_Straight_1x02 | BT1 |
| 1 | Pololu_MinIMU_v5 | Pololu_MiniIMU_v5 | IMU1 |
| 6 | GP2Y0A41SK0F | GP2Y0A41SK0F | IRB1, IRF1, IRL1, IRLF1, IRR1, IRRF1 |
| 2 | AdaFruit_TB6612 | AdaFruit_TB6612 | MD1, MD2 |
| 1 | ICL7611 | ICL7611 | OA1 |
| 1 | MainPowerSwitch | Molex_KK-6410-02_02x2.54mm_Straight | SW1 |
| 1 | RPi_PowerSwitch | Molex_KK-6410-02_02x2.54mm_Straight | SW2 |
Show 13 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | LED | Molex_KK-6410-02_02x2.54mm_Straight | D1 |
| 2 | 1uF | C_Rect_L7_W2_P5 | C1, C2 |
| 12 | 0.1uF | C_Rect_L7_W2_P5 | C3, C7, C8, C9, C10, C11, C12, C13 +4 |
| 1 | 1000uF | C_Radial_D10_L25_P5 | C4 |
| 1 | 470uF | C_Radial_D10_L16_P5 | C5 |
| 7 | 10uF | C_Radial_D4_P1.5 | C6, C18, C19, C20, C21, C22, C23 |
| 1 | 61.9k | Resistor_Horizontal_RM7mm | R1 |
| 3 | 49.9k | Resistor_Horizontal_RM7mm | R2, R3, R5 |
| 2 | 1M | Resistor_Horizontal_RM7mm | R4, R6 |
| 1 | 121 | Resistor_Horizontal_RM7mm | R7 |
| 1 | 30k | Resistor_Horizontal_RM7mm | R8 |
| 7 | 10k | Resistor_Horizontal_RM7mm | R9, R14, R15, R16, R17, R18, R19 |
| 1 | 499 | Resistor_Horizontal_RM7mm | R10 |
Pheeno robot electronic schematics design files
The KiCad project lives in the ACSLaboratory/pheeno_robot_electronic_schematics repository on GitHub; these links point at the commit this page was built from.
Pheeno robot electronic schematics: common questions
What microcontroller does the Pheeno robot electronic schematics use?
The Pheeno robot electronic schematics is built around the Teensy3.2, from the NXP family.
How big is the Pheeno robot electronic schematics PCB?
The Pheeno robot electronic schematics measures 114.3 × 114.3 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Pheeno robot electronic schematics?
70 components, from 33 distinct parts. The full bill of materials is listed on this page.
Where can I download the Pheeno robot electronic schematics design files?
From the ACSLaboratory/pheeno_robot_electronic_schematics repository on GitHub, which has the KiCad layout; the links under Design files point to each one.
Can I use the Pheeno robot electronic schematics design in my own project?
Yes, under the terms of its BSD-3-Clause license, which ACSLaboratory chose for the repository.
Can I test firmware for the Pheeno robot electronic schematics without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug NXP firmware against it before you order a PCB.
Similar boards
 NXP
32Bit shift register
MaltWhiskey
100 × 54 mm56 parts4LNo license763 NXP
Mega-Cube-Board
200 × 54 mm100 parts4LNo license763 NXP
MCL6809
MicroCoreLabs
32.3 × 61 mm7 parts4LNo license532 NXP
MCL68
31.6 × 84.1 mm13 parts4LNo license532 NXP
MCL65+
72.6 × 64.1 mm6 parts2LNo license532 NXP
MCLZ8
37.1 × 61.5 mm6 parts4LNo license532