
Ball balancing robot

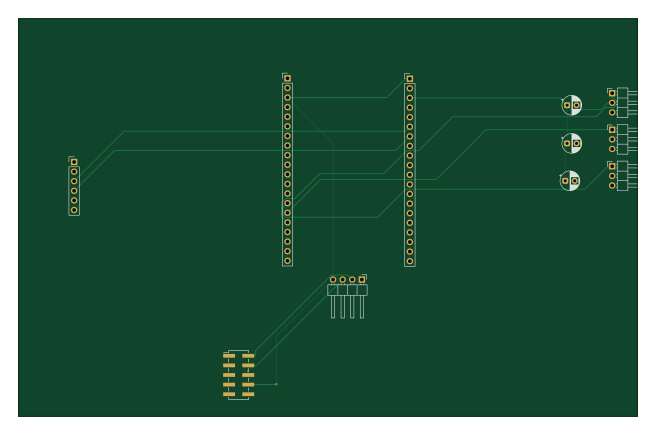
About the Ball balancing robot PCB
Ball balancing robot is an open source PCB design by ahmed-salama7, published on GitHub under the MIT license. It is a 2-layer board measuring 163.7 × 105.2 mm, with 11 components from 6 distinct parts.
By type, the board carries 5 connectors, 3 modules and 3 capacitors.
It belongs with the robotics & motion designs in this gallery.
From the project
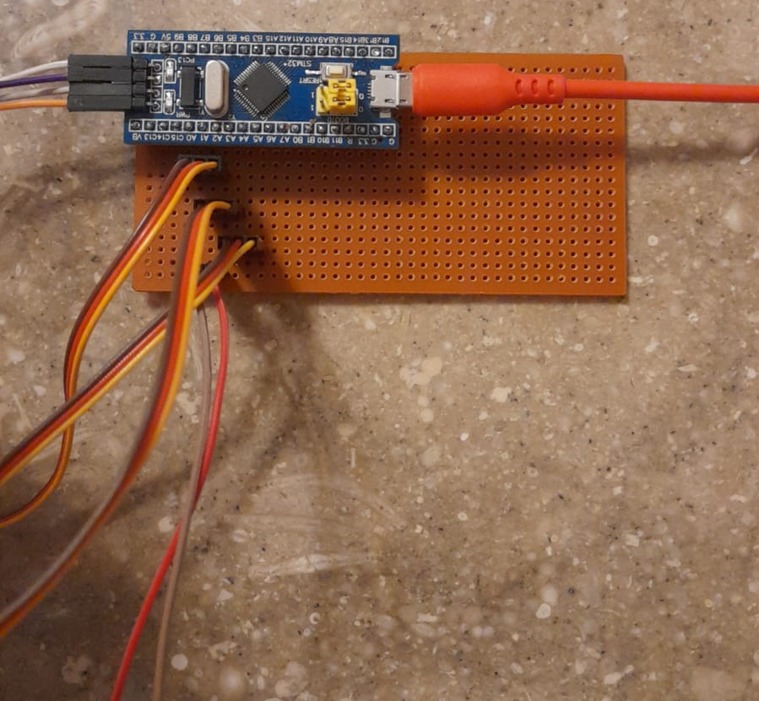
The custom PCB and wiring for the ball-balancing platform.
The custom PCB and wiring for the ball-balancing platform.
The PCB is a carrier/breakout that connects the Blue Pill to the three servos and the ST-Link, distributing the external 5 V servo power and a common ground.
- Never power the servos from the Blue Pill's on-board regulator — three servos under load can momentarily draw amps and will brown out the MCU. - Use a dedicated 5 V adapter sized for your servos, and tie all grounds together (PC USB ground, MCU ground, servo-supply ground).
Ball balancing robot bill of materials (BOM)
11 components, 6 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 3 | Motor_Servo | PinHeader_1x03_P2.54mm_Horizontal | M1, M2, M3 |
| 2 | Conn_01x20_Pin | PinHeader_1x20_P2.54mm_Vertical | J1, J2 |
| 1 | Conn_01x04_Pin | PinHeader_1x04_P2.54mm_Horizontal | J3 |
| 1 | Conn_02x05_Odd_Even | PinHeader_2x05_P2.54mm_Vertical_SMD | J4 |
| 1 | Conn_01x06_Pin | PinHeader_1x06_P2.54mm_Vertical | J5 |
| 3 | C | CP_Radial_D5.0mm_P2.50mm | C1, C2, C3 |
Ball balancing robot design files
The KiCad project lives in the ahmed-salama7/ball-balancing-robot repository on GitHub; these links point at the commit this page was built from.
Ball balancing robot: common questions
How big is the Ball balancing robot PCB?
The Ball balancing robot measures 163.7 × 105.2 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Ball balancing robot?
11 components, from 6 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Ball balancing robot design files?
From the ahmed-salama7/ball-balancing-robot repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the Ball balancing robot design in my own project?
Yes, under the terms of its MIT license, which ahmed-salama7 chose for the repository.
Similar boards

Stack chan
stack-chan
50 × 50 mm33 parts2LApache-2.01.7k
Cube batteryboard
willem-pennings
95 × 95 mm4 parts2LGPL-3.01.1k
Trollerv2
rene-dev
100 × 75 mm33 parts4LGPL-3.0979
Powerstep
95.2 × 71.5 mm28 parts4LGPL-3.0979
11ua
57.3 × 19 mm26 parts2LGPL-3.0979
Diff driver
32 × 22 mm14 parts2LGPL-3.0979