
Emg hand manipulation

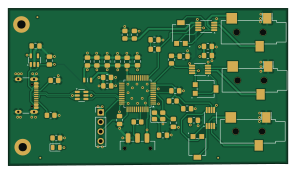
About the Emg hand manipulation PCB
Emg hand manipulation is an open source STM32 PCB design by ajama0609, published on GitHub. It is a 4-layer board measuring 73.9 × 41.5 mm, with 47 components from 22 distinct parts.
Its main chip is the STM32F103C8T6, from the STM32 family. Other key parts include the USBLC6-2SC6, INA333AIDGKR and MIC5504-3.3YM5. By type, the board carries 20 capacitors, 9 resistors, 6 ICs, 5 connectors, 1 crystal and 1 switch.
It belongs with the audio and sensors designs in this gallery.
From the project
emg HIL with arduino matlab manipulation of allegroHand
Surface electromyography (sEMG) is a non-invasive technique for measuring muscle electrical activity and is widely used in human–machine interfaces, prosthetics, and rehabilitation systems. Reliable sEMG systems require low-noise analog front-ends, high common-mode rejection, stable power delivery, and careful PCB layout to preserve signal integrity, particularly given the low-amplitude (µV–mV) nature of EMG signals.
Main components on the Emg hand manipulation
Emg hand manipulation bill of materials (BOM)
47 components, 22 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | USBLC6-2SC6 STMicroelectronics | SOT-23-6 | U1 |
| 1 | STM32F103C8T6 STMicroelectronics | LQFP-48_7x7mm_P0.5mm | U2 |
| 3 | INA333AIDGKR INA333xxDGK Texas Instruments | VSSOP-8_3x3mm_P0.65mm | U3, U4, U5 |
| 1 | MIC5504-3.3YM5 Microchip Technology | SOT-23-5 | U6 |
| 1 | 16MHZ 16MHz EPSON | Crystal_SMD_3225-4Pin_3.2x2.5mm | Y1 |
| 1 | USB4105-GF-A USB_C_Receptacle_USB2.0_16P GCT | USB_C_Receptacle_GCT_USB4105-xx-A_16P_TopMnt_Horizontal | J1 |
| 1 | 61300411121 Conn_01x04_Pin Würth Elektronik | PinHeader_1x04_P2.54mm_Vertical | J2 |
| 3 | SJ-3523-SMT AudioJack3 CUI Devices | Jack_3.5mm_CUI_SJ-3523-SMT_Horizontal | J4, J5, J6 |
| 1 | JS102011SAQN SW_SPDT C&K | SW_SPDT_CK_JS102011SAQN | SW1 |
| 3 | 3314G-1-101E Vishay / Sfernice | 3314G-1 | VR1, VR2, VR4 |
| 1 | APT2012SURCK RED Kingbright | D_0805_2012Metric | D1 |
| 1 | BLM21AG102SN1D 120R Murata Electronics | BLM21AG102BH1J | FB1 |
| 1 | C2012X5R1E106M125AB 10uF TDK | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C1 |
| 11 | GA0805Y104KBBBT31G 100nF Vishay / Vitramon | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C2, C3, C4, C5, C6, C16, C17, C18 +3 |
| 1 | C0805X103JCRAC3316 10nF KEMET | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C7 |
| 4 | C0805X105J5RACAUTO 1uF KEMET | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C8, C9, C11, C12 |
| 1 | GA0805Y104KBBBT31G 100n Vishay / Vitramon | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C13 |
| 2 | C0805C100KDTACTU 10p KEMET | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C14, C15 |
| 3 | RR1220P-103-D 10k Susumu | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R1, R3, R4 |
| 1 | RC0805JR-071K5L 1k5 YAGEO | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R2 |
Show 2 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 2 | RC0402JR-074K7L 5k1 YAGEO | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R8, R9 |
| 3 | RG2012L-332-L-T05 3.3k Susumu | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R11, R12, R14 |
Emg hand manipulation design files
The KiCad project lives in the ajama0609/emg_hand_manipulation repository on GitHub; these links point at the commit this page was built from.
Emg hand manipulation: common questions
What microcontroller does the Emg hand manipulation use?
The Emg hand manipulation is built around the STM32F103C8T6, from the STM32 family.
How big is the Emg hand manipulation PCB?
The Emg hand manipulation measures 73.9 × 41.5 mm, has 4 copper layers and is 1.6062 mm thick.
How many components are on the Emg hand manipulation?
47 components, from 22 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Emg hand manipulation design files?
From the ajama0609/emg_hand_manipulation repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the Emg hand manipulation design in my own project?
The repository has no license, so all rights stay with ajama0609. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the Emg hand manipulation without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug STM32 firmware against it before you order a PCB.
Similar boards
 STM32
LumenPnP Motherboard
opulo-inc
149 × 95 mm296 parts4LCC-BY-SA-4.03.7k STM32
Type g
google
169 × 30 mm24 parts2LApache-2.02.9k STM32
Main panel
234 × 84 mm26 parts4LApache-2.02.9k STM32
Base
52.3 × 52.3 mm36 parts2LApache-2.02.9k STM32
Type a
150 × 30 mm14 parts2LApache-2.02.9k STM32
Type c
188 × 30 mm17 parts2LApache-2.02.9k