
Cybergear canbus

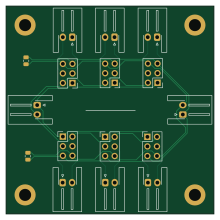
About the Cybergear canbus PCB
Cybergear canbus is an open source PCB design by cybergear-robotics, published on GitHub under the MIT license. It is a 2-layer board measuring 55 × 55 mm, with 16 components from 10 distinct parts.
By type, the board carries 8 connectors, 6 switches and 2 resistors.
It belongs with the usb & debug tools designs in this gallery.
From the project
Star-Topology Connector Board for CAN-Bus with Debugging Port
This is a small extension board located on the CyberBot. It distributes the CAN-bus to all 6 cybergears and provides a debug port. Each cybergear CAN-bus sink can be switched between CAN-bus or debug port. The can-bus is designed as star topology, which works in small setups.
The switches are missing in the production files and you need to solder these on your own. The required switches are MSS22D18 Mini DIP Slide Switch 2x03.

Cybergear canbus bill of materials (BOM)
16 components, 10 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | Cybergear 1 | JST_XH_S2B-XH-A-1_1x02_P2.50mm_Horizontal | J1 |
| 1 | Cybergear 2 | JST_XH_S2B-XH-A-1_1x02_P2.50mm_Horizontal | J2 |
| 1 | Cybergear 3 | JST_XH_S2B-XH-A-1_1x02_P2.50mm_Horizontal | J3 |
| 1 | Cybergear 4 | JST_XH_S2B-XH-A-1_1x02_P2.50mm_Horizontal | J4 |
| 1 | Cybergear 5 | JST_XH_S2B-XH-A-1_1x02_P2.50mm_Horizontal | J5 |
| 1 | Cybergear 6 | JST_XH_S2B-XH-A-1_1x02_P2.50mm_Horizontal | J6 |
| 1 | Debug | JST_XH_S2B-XH-A-1_1x02_P2.50mm_Horizontal | J7 |
| 1 | Cyberboard | JST_XH_S2B-XH-A-1_1x02_P2.50mm_Horizontal | J8 |
| 6 | SW_Slide_DPDT | MSS22D18 Mini DIP Slide Switch 2x03 | SW1, SW2, SW3, SW4, SW5, SW6 |
| 2 | 120 | R_0805_2012Metric | R1, R2 |
Cybergear canbus design files
The KiCad project lives in the cybergear-robotics/cybergear-canbus-pcb repository on GitHub; these links point at the commit this page was built from.
- Layoutcan_board.kicad_pcb
- Schematiccan_board.kicad_sch
Cybergear canbus: common questions
How big is the Cybergear canbus PCB?
The Cybergear canbus measures 55 × 55 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Cybergear canbus?
16 components, from 10 distinct parts. The full bill of materials is listed on this page.
Where can I download the Cybergear canbus design files?
From the cybergear-robotics/cybergear-canbus-pcb repository on GitHub, which has the KiCad layout and the schematic; the links under Design files point to each one.
Can I use the Cybergear canbus design in my own project?
Yes, under the terms of its MIT license, which cybergear-robotics chose for the repository.
Similar boards
XG Station Power
osy
54.3 × 91 mm9 parts2LCC-BY-4.0703
USB Hub Test
50 × 50 mm85 parts4LCC-BY-4.0703
FW-EC-DongleHiderPlus
LeoDJ
28.2 × 26.1 mm14 parts4LCERN-OHL-W-2.0490
Adapter tsop48
bbogush
48 × 33 mm3 parts2LGPL-3.0389
Adapter tsop48 solder
48 × 33 mm3 parts2LGPL-3.0389
Adapter soic8 solder
48 × 20 mm3 parts2LGPL-3.0389