
Robo-328p

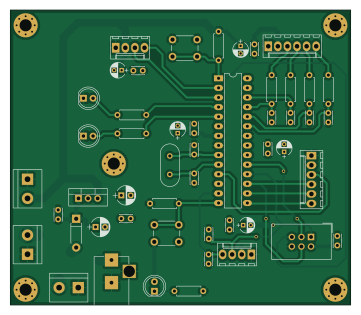
About the Robo-328p PCB
Robo-328p is an open source AVR/Arduino PCB design by eavcodes, published on GitHub under the MIT license. It is a 2-layer board measuring 90 × 78 mm, with 50 components from 28 distinct parts.
Its main chip is the ATmega328P-PU, from the AVR/Arduino family. Other key parts include the LM7805_TO220. By type, the board carries 23 capacitors, 9 connectors, 9 resistors, 4 diodes, 2 ICs and 2 switches.
It belongs with the robotics & motion designs in this gallery.
From the project
Projeto de placa com 328P para experiencias com robotica e sensores
Main components on the Robo-328p
Robo-328p bill of materials (BOM)
50 components, 28 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | ATmega328P-PU | DIP-28_W7.62mm_LongPads | U1 |
| 1 | LM7805_TO220 | TO-220-3_Vertical | U2 |
| 1 | 16Mhz | Crystal_HC49-U_Vertical | Y1 |
| 1 | ultrassom | Molex_KK-6410-04_04x2.54mm_Straight | J1 |
| 1 | reflectancia-entrada | Molex_KK-6410-06_06x2.54mm_Straight | J2 |
| 1 | SERIAL UART | Molex_KK-6410-04_04x2.54mm_Straight | J3 |
| 1 | ponte H PWM | Molex_KK-6410-06_06x2.54mm_Straight | J4 |
| 1 | PWR OUT | TerminalBlock_bornier-2_P5.08mm | J5 |
| 1 | ICSP2 | IDC-Header_2x03_Pitch2.54mm_Straight | J6 |
| 1 | PWR IN | TerminalBlock_bornier-2_P5.08mm | J7 |
| 1 | PWR JACK | BARREL_JACK | J8 |
| 1 | 5VOUT | TerminalBlock_bornier-2_P5.08mm | J9 |
| 1 | RESET | SW_PUSH_6mm_h4.3mm | SW1 |
| 1 | START | SW_PUSH_6mm_h4.3mm | SW2 |
| 1 | STATUS | LED_D5.0mm | D1 |
| 1 | INIT | LED_D5.0mm | D2 |
| 1 | 1N4007 | D_DO-41_SOD81_P7.62mm_Horizontal | D3 |
| 1 | PWR | LED_D5.0mm | D4 |
| 8 | 0.1uF | C_Disc_D3.4mm_W2.1mm_P2.50mm | C1, C4, C6, C9, C17, C21, C22, C25 |
| 5 | 10uF | CP_Radial_D4.0mm_P2.00mm | C2, C5, C7, C10, C18 |
Show 8 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 4 | 0.22u | C_Disc_D3.4mm_W2.1mm_P2.50mm | C3, C8, C15, C16 |
| 2 | 22pF | C_Disc_D3.4mm_W2.1mm_P2.50mm | C11, C14 |
| 2 | 100pF | C_Disc_D3.4mm_W2.1mm_P2.50mm | C12, C13 |
| 1 | 100uF | CP_Radial_D5.0mm_P2.50mm | C23 |
| 1 | 47uF | CP_Radial_D5.0mm_P2.50mm | C24 |
| 4 | 1k | R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R1, R2, R3, R5 |
| 2 | 10k | R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R4, R7 |
| 3 | 470R | R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R6, R8, R9 |
Robo-328p design files
The KiCad project lives in the eavcodes/robo-328p repository on GitHub; these links point at the commit this page was built from.
Robo-328p: common questions
What microcontroller does the Robo-328p use?
The Robo-328p is built around the ATmega328P-PU, from the AVR/Arduino family.
How big is the Robo-328p PCB?
The Robo-328p measures 90 × 78 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Robo-328p?
50 components, from 28 distinct parts. The full bill of materials is listed on this page.
Where can I download the Robo-328p design files?
From the eavcodes/robo-328p repository on GitHub, which has the KiCad layout; the links under Design files point to each one.
Can I use the Robo-328p design in my own project?
Yes, under the terms of its MIT license, which eavcodes chose for the repository.
Can I test firmware for the Robo-328p without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug AVR/Arduino firmware against it before you order a PCB.
Similar boards
 AVR/Arduino
Magspoof
samyk
35 × 29 mm11 parts2LNo license4.2k AVR/Arduino
Redox keyboard
mattdibi
162.2 × 126.5 mm77 parts2LMIT2.0k AVR/Arduino
Labrador
espotek-org
36.8 × 34.7 mm75 parts2LNo license1.2k AVR/Arduino
V4
stuartpittaway
30 × 50 mm38 parts2LCC-BY-NC-4.01.1k AVR/Arduino
ModuleV450
30 × 61.4 mm39 parts2LCC-BY-NC-4.01.1k AVR/Arduino
Discipline
coseyfannitutti
304.9 × 122.8 mm170 parts2LCC-BY-NC-4.01.0k