
UniversalRobotController

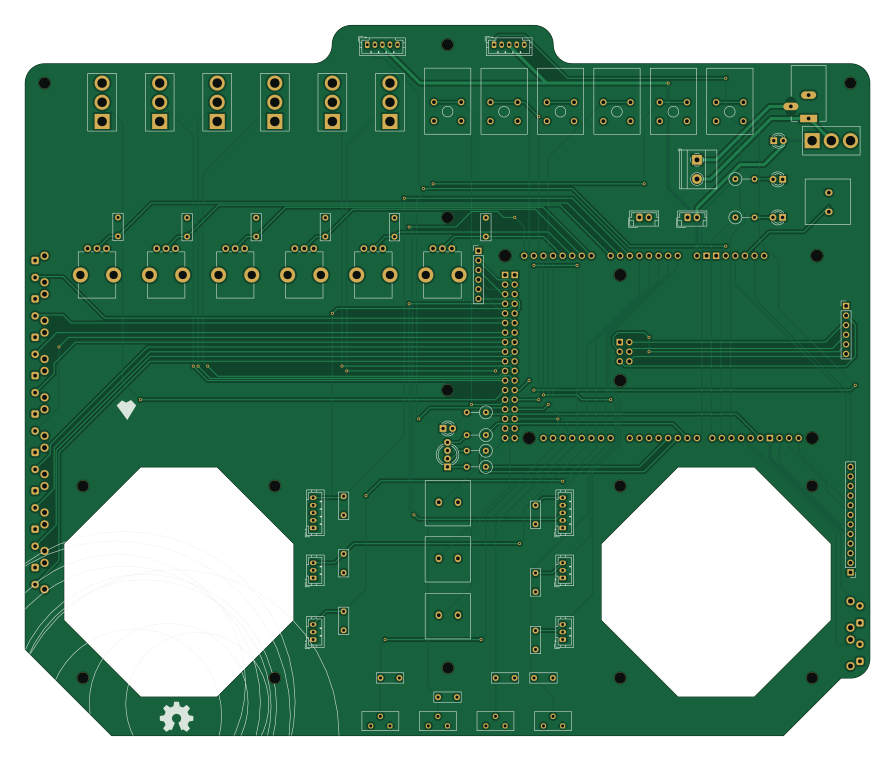
About the UniversalRobotController PCB
UniversalRobotController is an open source AVR/Arduino PCB design by falue, published on GitHub. It is a 2-layer board measuring 223.5 × 188 mm, with 81 components from 60 distinct parts.
Its main chip is the Arduino_Mega2560_R3_Shield, from the AVR/Arduino family. By type, the board carries 28 switches, 16 capacitors, 15 connectors, 6 resistors, 5 diodes and 1 module.
From the project
DIY RC transmitter and receiver
This repository includes transmitter (TX) and receiver (RX) arduino files for a remote controlled robot of any form.
The transmitter is a custom build to have full control over input mixing, skewing and do all sorts of dependencies. It depends on a custom PCB, or like a thousand wires. The receiver end can be a robot or whatever.
This relies on OrangeRx products by hobbyking for Tx/Rx and uses the (legacy) DSM2/DSMX† protocols for a reliable, digital communication. with a "range of up to 3km (line of sight)". I'm sure though this works with any RC transmitter that uses iBUs / ppm.
Main components on the UniversalRobotController
UniversalRobotController bill of materials (BOM)
81 components, 60 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | Arduino_Mega2560_R3_Shield | Arduino_Mega2560_R3_Shield | A1 |
| 1 | L-Z | JST_PH_B5B-PH-K_1x05_P2.00mm_Vertical | J1 |
| 1 | R-Z | JST_PH_B5B-PH-K_1x05_P2.00mm_Vertical | J2 |
| 1 | BATTERY INPUT 7-12V | TerminalBlock_Phoenix_MKDS-1,5-2-5.08_1x02_P5.08mm_Horizontal | J3 |
| 1 | Transmitter 1 | JST_PH_B5B-PH-K_1x05_P2.00mm_Vertical | J4 |
| 1 | Transmitter 2 | JST_PH_B5B-PH-K_1x05_P2.00mm_Vertical | J5 |
| 1 | R-Y | JST_PH_B3B-PH-K_1x03_P2.00mm_Vertical | J6 |
| 1 | R-X | JST_PH_B3B-PH-K_1x03_P2.00mm_Vertical | J7 |
| 1 | L-X | JST_PH_B3B-PH-K_1x03_P2.00mm_Vertical | J8 |
| 1 | L-Y | JST_PH_B3B-PH-K_1x03_P2.00mm_Vertical | J9 |
| 2 | Not used | PinHeader_1x06_P2.54mm_Vertical | J10, J14 |
| 1 | VOLTAGE METER | JST_EH_B2B-EH-A_1x02_P2.50mm_Vertical | J11 |
| 1 | In: 7-12V | BarrelJack_Kycon_KLDX-0202-xC_Horizontal | J12 |
| 1 | Not used | PinHeader_1x12_P2.54mm_Vertical | J13 |
| 1 | 5V LED | JST_EH_B2B-EH-A_1x02_P2.50mm_Vertical | J15 |
| 1 | poti 1 | Potentiometer_Bourns_PTV09A-1_Single_Vertical | RV1 |
| 1 | poti 2 | Potentiometer_Bourns_PTV09A-1_Single_Vertical | RV2 |
| 1 | poti 3 | Potentiometer_Bourns_PTV09A-1_Single_Vertical | RV3 |
| 1 | poti 4 | Potentiometer_Bourns_PTV09A-1_Single_Vertical | RV4 |
| 1 | poti 5 | Potentiometer_Bourns_PTV09A-1_Single_Vertical | RV5 |
Show 40 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | poti 6 | Potentiometer_Bourns_PTV09A-1_Single_Vertical | RV6 |
| 1 | trimL-X | Potentiometer_Bourns_3386X_Horizontal | RV7 |
| 1 | trimR-Y | Potentiometer_Bourns_3386X_Horizontal | RV11 |
| 1 | trimR-X | Potentiometer_Bourns_3386X_Horizontal | RV12 |
| 1 | trimL-Y | Potentiometer_Bourns_3386X_Horizontal | RV13 |
| 1 | user switch 01 | Toggle_switch_3P_5.08 | SW1 |
| 1 | user push 1 | SW_TH_Tactile_FL_thingy | SW2 |
| 1 | system push 1 | Drucktaster_FL_Mentor_1852.6231 | SW3 |
| 1 | system push 2 | Drucktaster_FL_Mentor_1852.6231 | SW4 |
| 1 | system push 3 | Drucktaster_FL_Mentor_1852.6231 | SW5 |
| 1 | reset arduino | Drucktaster_FL_Mentor_1852.6231 | SW6 |
| 1 | main I/O | Toggle_switch_3P_5.08 | SW7 |
| 1 | user push 2 | SW_TH_Tactile_FL_thingy | SW8 |
| 1 | user push 3 | SW_TH_Tactile_FL_thingy | SW9 |
| 1 | user push 4 | SW_TH_Tactile_FL_thingy | SW10 |
| 1 | user push 5 | SW_TH_Tactile_FL_thingy | SW11 |
| 1 | user push 6 | SW_TH_Tactile_FL_thingy | SW12 |
| 1 | user switch 03 | Toggle_switch_3P_5.08 | SW13 |
| 1 | user switch 02 | Toggle_switch_3P_5.08 | SW14 |
| 1 | user switch 05 | Toggle_switch_3P_5.08 | SW15 |
| 1 | user switch 06 | Toggle_switch_3P_5.08 | SW16 |
| 1 | user switch 04 | Toggle_switch_3P_5.08 | SW17 |
| 1 | user push 7 | SW_Push_1P2T_Horizontal_FL_RND_210-00255 | SW18 |
| 1 | user push 8 | SW_Push_1P2T_Horizontal_FL_RND_210-00255 | SW19 |
| 1 | user push 9 | SW_Push_1P2T_Horizontal_FL_RND_210-00255 | SW20 |
| 1 | user push 10 | SW_Push_1P2T_Horizontal_FL_RND_210-00255 | SW21 |
| 1 | user push 11 | SW_Push_1P2T_Horizontal_FL_RND_210-00255 | SW22 |
| 1 | user push 12 | SW_Push_1P2T_Horizontal_FL_RND_210-00255 | SW23 |
| 1 | user push 13 | SW_Push_1P2T_Horizontal_FL_RND_210-00255 | SW24 |
| 1 | user push 14 | SW_Push_1P2T_Horizontal_FL_RND_210-00255 | SW25 |
| 1 | user push 15 | SW_Push_1P2T_Horizontal_FL_RND_210-00255 | SW26 |
| 1 | user push 16 | SW_Push_1P2T_Horizontal_FL_RND_210-00255 | SW27 |
| 1 | user push 17 | SW_Push_1P2T_Horizontal_FL_RND_210-00255 | SW28 |
| 1 | SYSTEM LED | LED_D3.0mm | D1 |
| 1 | SYS RGB LED | LED_D5.0mm-4_RGB_Wide_Pins | D2 |
| 1 | TX 1 LED | LED_D3.0mm | D3 |
| 1 | TX 2 LED | LED_D3.0mm | D4 |
| 1 | 12V POWER LED | LED_D3.0mm | D5 |
| 16 | 0.33uF | C_Disc_D7.0mm_W2.5mm_P5.00mm | C1, C2, C3, C4, C5, C6, C7, C8 +8 |
| 6 | R=220Ω | R_Axial_DIN0309_L9.0mm_D3.2mm_P5.08mm_Vertical | R1, R2, R3, R4, R5, R6 |
UniversalRobotController design files
The KiCad project lives in the falue/universalRobotController repository on GitHub; these links point at the commit this page was built from.
UniversalRobotController: common questions
What microcontroller does the UniversalRobotController use?
The UniversalRobotController is built around the Arduino_Mega2560_R3_Shield, from the AVR/Arduino family.
How big is the UniversalRobotController PCB?
The UniversalRobotController measures 223.5 × 188 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the UniversalRobotController?
81 components, from 60 distinct parts. The full bill of materials is listed on this page.
Where can I download the UniversalRobotController design files?
From the falue/universalRobotController repository on GitHub, which has the KiCad layout and the schematic; the links under Design files point to each one.
Can I use the UniversalRobotController design in my own project?
The repository has no license, so all rights stay with falue. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the UniversalRobotController without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug AVR/Arduino firmware against it before you order a PCB.
Similar boards
 AVR/Arduino
Magspoof
samyk
35 × 29 mm11 parts2LNo license4.2k AVR/Arduino
Redox keyboard
mattdibi
162.2 × 126.5 mm77 parts2LMIT2.0k AVR/Arduino
Labrador
espotek-org
36.8 × 34.7 mm75 parts2LNo license1.2k AVR/Arduino
V4
stuartpittaway
30 × 50 mm38 parts2LCC-BY-NC-4.01.1k AVR/Arduino
ModuleV450
30 × 61.4 mm39 parts2LCC-BY-NC-4.01.1k AVR/Arduino
Discipline
coseyfannitutti
304.9 × 122.8 mm170 parts2LCC-BY-NC-4.01.0k