
Flatmcu

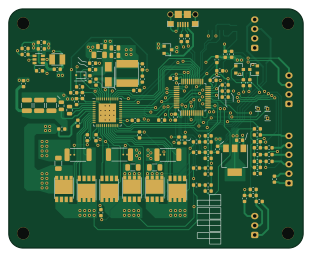
About the Flatmcu PCB
Flatmcu is an open source STM32 PCB design by GyrocopterLLC, published on GitHub under the MIT license. It is a 4-layer board measuring 77.8 × 63.2 mm, with 115 components from 50 distinct parts.
Its main chip is the STM32G431CBTx, from the STM32 family. Other key parts include the AP1117-33, DRV8353RS and TPS563240. By type, the board carries 50 capacitors, 35 resistors, 8 transistors, 6 connectors, 4 ICs and 4 diodes.
It belongs with the robotics & motion and power & battery designs in this gallery.
From the project
Hardware design for the flatmcu - an STM32G4 based BLDC / FOC motor controller.
The controller is based on the STM32G473CB microcontroller from ST Microelectronics. It contains an ARM Cortex-M4 core at up to 170MHz. The three-phase bridge driver is the TI DRV8353RS, which also contains shunt resistor current sensors and a 95V buck regulator.
The MOSFETs in the three-phase bridge (Toshiba TPW4R50ANH) are dual-side cooling. There's a large metal pad on top of them. A heatsink should be attached there. The opposite side of the board is intended for soldering on the large battery and phase wires.
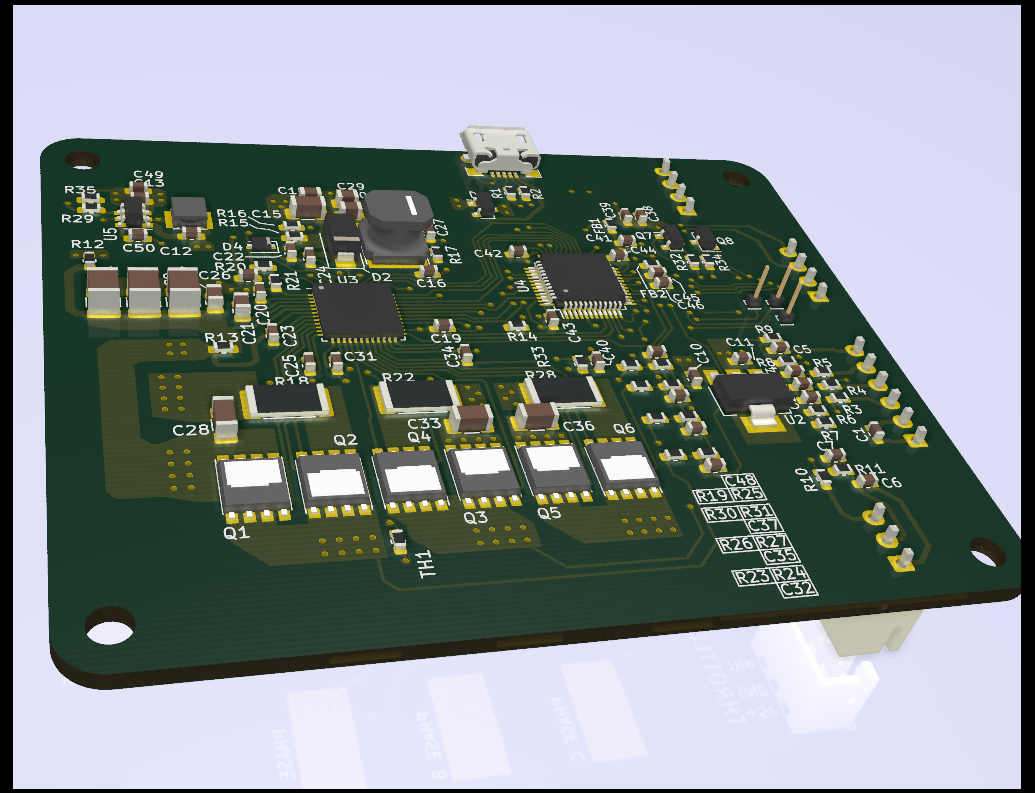
Main components on the Flatmcu
Flatmcu bill of materials (BOM)
115 components, 50 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | AP1117-33 | SOT-223-3_TabPin2 | U2 |
| 1 | DRV8353RS | TI-RGZ-48-QFN | U3 |
| 1 | STM32G431CBTx | LQFP-48_7x7mm_P0.5mm | U4 |
| 1 | TPS563240 | SOT-23-6 | U5 |
| 6 | TPW4R50ANH | Toshiba_DSOP-Advance | Q1, Q2, Q3, Q4, Q5, Q6 |
| 2 | Q_NMOS_GSD | SOT-23 | Q7, Q8 |
| 1 | Hall | JST_XH_B6B-XH-A_1x06_P2.50mm_Vertical | J1 |
| 1 | USB_B_Micro | USB_Micro_B_Female_10118193-0001LF | J2 |
| 1 | Throttle | JST_XH_B3B-XH-A_1x03_P2.50mm_Vertical | J3 |
| 1 | SW Debug | JST_SH_SM05B-SRSS-TB_1x05-1MP_P1.00mm_Horizontal | J7 |
| 1 | UART to HBD | JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | J8 |
| 1 | UART to BMS | JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | J9 |
| 1 | Thermistor | R_0603_1608Metric | TH1 |
| 3 | TestPoint | PinHeader_1x01_P1.00mm_Vertical | TP1, TP2, TP3 |
| 1 | PMEG4005 | SOT-23 | D1 |
| 1 | SS1H10-E3/61T | D_SMA | D2 |
| 1 | LED_Dual_AACC | LED_RGB_1210 | D3 |
| 1 | PMEG2020 | D_SOD-323F | D4 |
| 2 | BLM18AG601SN1D | R_0603_1608Metric | FB1, FB2 |
| 1 | 100u | NR6045 | L1 |
Show 30 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | 1.5u | Bourns_SRN3015 | L2 |
| 12 | 100n | C_0603_1608Metric | C1, C6, C10, C19, C38, C39, C42, C43 +4 |
| 9 | 1n | C_0603_1608Metric | C2, C3, C4, C5, C7, C25, C31, C34 +1 |
| 1 | 1u | C_1210_3225Metric | C8 |
| 2 | 4.7u | C_1210_3225Metric | C9, C14 |
| 7 | 1u | C_0603_1608Metric | C11, C13, C16, C20, C22, C23, C45 |
| 1 | 10u | C_0603_1608Metric | C12 |
| 4 | 1u | C_1206_3216Metric | C15, C28, C33, C36 |
| 2 | 100n | C_0805_2012Metric | C17, C18 |
| 1 | 47n | C_0805_2012Metric | C21 |
| 3 | 10n | C_0603_1608Metric | C24, C40, C46 |
| 1 | 330p | C_0603_1608Metric | C26 |
| 1 | 47n | C_0603_1608Metric | C27 |
| 2 | 4.7u | C_0805_2012Metric | C29, C30 |
| 3 | 2.2n | C_0603_1608Metric | C32, C35, C37 |
| 1 | 4.7u | C_0603_1608Metric | C41 |
| 2 | 22 | R_0603_1608Metric | R1, R2 |
| 8 | 1k | R_0603_1608Metric | R3, R4, R5, R14, R21, R24, R27, R31 |
| 7 | 10k | R_0603_1608Metric | R6, R7, R8, R9, R11, R33, R35 |
| 1 | 4.99k | R_0603_1608Metric | R10 |
| 1 | DNP | R_0603_1608Metric | R12 |
| 1 | 0 | R_0603_1608Metric | R13 |
| 2 | 100k | R_0603_1608Metric | R15, R19 |
| 1 | 220k | R_0603_1608Metric | R16 |
| 1 | 8.2k | R_0603_1608Metric | R17 |
| 3 | 2.5m | R_2512_6332Metric | R18, R22, R28 |
| 2 | 4.02k | R_0603_1608Metric | R20, R25 |
| 3 | 22k | R_0603_1608Metric | R23, R26, R30 |
| 1 | 73.2k | R_0603_1608Metric | R29 |
| 2 | 330 | R_0603_1608Metric | R32, R34 |
Flatmcu design files
The KiCad project lives in the GyrocopterLLC/flatmcu repository on GitHub; these links point at the commit this page was built from.
- Layoutdesign/flatmcu.kicad_pcb
- Schematicdesign/flatmcu.kicad_sch
- BOMdesign/flatmcu_bom.csv
Flatmcu: common questions
What microcontroller does the Flatmcu use?
The Flatmcu is built around the STM32G431CBTx, from the STM32 family.
How big is the Flatmcu PCB?
The Flatmcu measures 77.8 × 63.2 mm, has 4 copper layers and is 1.6 mm thick.
How many components are on the Flatmcu?
115 components, from 50 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Flatmcu design files?
From the GyrocopterLLC/flatmcu repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the Flatmcu design in my own project?
Yes, under the terms of its MIT license, which GyrocopterLLC chose for the repository.
Can I test firmware for the Flatmcu without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug STM32 firmware against it before you order a PCB.
Similar boards
 STM32
AxxSolder
AxxAxx
39 × 82.5 mm122 parts2LGPL-3.01.7k STM32
AIOC
skuep
21 × 31.5 mm47 parts2LMIT1.4k STM32
Ferris
pierrechevalier83
208.8 × 86.8 mm102 parts2LSHL-2.11.3k STM32
Module 16S
stuartpittaway
71.1 × 89.6 mm113 parts4LCC-BY-NC-4.01.1k STM32
Djinn
tzarc
192.3 × 150.5 mm216 parts2LCERN-OHL-S-2.0988 STM32
Ghoul
228.6 × 79.4 mm163 parts2LCERN-OHL-S-2.0988