
Autopilot

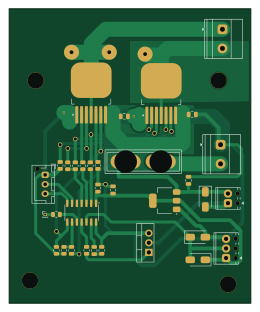
About the Autopilot PCB
Autopilot is an open source AVR/Arduino PCB design by ieb, published on GitHub. It is a 2-layer board measuring 64 × 78 mm, with 33 components from 23 distinct parts.
Its main chip is the ATtiny3224-SS, from the AVR/Arduino family. Other key parts include the AMS1117-3.3. By type, the board carries 12 resistors, 6 connectors, 5 capacitors, 4 diodes, 3 transistors and 2 ICs.
From the project
An ML Autopilot designed and written almost entirely by Google AntiGravity.
- Rudder position from pot and ADC - HBridge Rgiving the ram - INS 219 current sensor - 2x PWM HBridge drive - ElectroMagnetic Clutch using Mosfet - Serial interface to Raspberry Pi - Motor current monitoring - Voltage monitoring
Open actuator-board.kicadsch` in KiCad 9 for the full schematic with design notes.
Unfortunately Cursor failed to create a viable schematic, loads of halucinations, pins that didnt exist, and although KiCad files are text, all it did was copy text into the file which displayed as text. Models tried Gemini 3 adn Claud Opus 4.5. Neither produced a viable design.
Main components on the Autopilot
Autopilot bill of materials (BOM)
33 components, 23 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | ATtiny3224-SS | SOIC-14_3.9x8.7mm_P1.27mm | U2 |
| 1 | AMS1117-3.3 | SOT-223-3_TabPin2 | U3 |
| 1 | IRF540N | TO-220-3_Vertical | Q1 |
| 1 | BTN7960TA | TO-263-7_TabPin8 | Q2 |
| 1 | BTN7960 | TO-263-7_TabPin8 | Q3 |
| 1 | RudderSense | TerminalBlock_Phoenix_MPT-0,5-3-2.54_1x03_P2.54mm_Horizontal | J1 |
| 1 | 12V | TerminalBlock_Phoenix_MKDS-1,5-2-5.08_1x02_P5.08mm_Horizontal | J2 |
| 1 | Motor | TerminalBlock_Phoenix_MKDS-1,5-2-5.08_1x02_P5.08mm_Horizontal | J3 |
| 1 | UDPI | PinHeader_1x01_P1.00mm_Vertical | J4 |
| 1 | Clutch | TerminalBlock_Phoenix_MPT-0,5-2-2.54_1x02_P2.54mm_Horizontal | J5 |
| 1 | SerialToPi | JST_XH_B3B-XH-AM_1x03_P2.50mm_Vertical | J7 |
| 1 | 30A | Fuse_Blade_ATO_directSolder | F2 |
| 1 | SS34 | D_SMA | D1 |
| 2 | US1J | D_SMA | D2, D3 |
| 1 | LED | C_0805_2012Metric | D4 |
| 1 | 100nF | C_0805_2012Metric | C1 |
| 2 | 10uF | C_0805_2012Metric | C2, C4 |
| 2 | 470nF | C_0805_2012Metric | C3, C5 |
| 1 | 470R | R_0805_2012Metric | R1 |
| 1 | 100R | R_0805_2012Metric | R2 |
Show 3 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | 4K7 | R_0805_2012Metric | R3 |
| 5 | 1K | R_0805_2012Metric | R4, R5, R6, R9, R12 |
| 4 | 10K | R_0805_2012Metric | R7, R8, R10, R11 |
Autopilot design files
The KiCad project lives in the ieb/autopilot repository on GitHub; these links point at the commit this page was built from.
Autopilot: common questions
What microcontroller does the Autopilot use?
The Autopilot is built around the ATtiny3224-SS, from the AVR/Arduino family.
How big is the Autopilot PCB?
The Autopilot measures 64 × 78 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Autopilot?
33 components, from 23 distinct parts. The full bill of materials is listed on this page.
Where can I download the Autopilot design files?
From the ieb/autopilot repository on GitHub, which has the KiCad layout and the schematic; the links under Design files point to each one.
Can I use the Autopilot design in my own project?
The repository has no license, so all rights stay with ieb. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the Autopilot without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug AVR/Arduino firmware against it before you order a PCB.
Similar boards
 AVR/Arduino
Magspoof
samyk
35 × 29 mm11 parts2LNo license4.2k AVR/Arduino
Redox keyboard
mattdibi
162.2 × 126.5 mm77 parts2LMIT2.0k AVR/Arduino
Labrador
espotek-org
36.8 × 34.7 mm75 parts2LNo license1.2k AVR/Arduino
V4
stuartpittaway
30 × 50 mm38 parts2LCC-BY-NC-4.01.1k AVR/Arduino
ModuleV450
30 × 61.4 mm39 parts2LCC-BY-NC-4.01.1k AVR/Arduino
Discipline
coseyfannitutti
304.9 × 122.8 mm170 parts2LCC-BY-NC-4.01.0k