
Quad copter

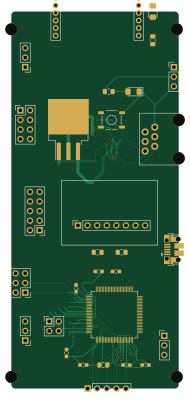
About the Quad copter PCB
Quad copter is an open source PIC PCB design by mtilson115, published on GitHub under the GPL-2.0 license. It is a 2-layer board measuring 44.3 × 99.8 mm, with 40 components from 32 distinct parts.
Its main chip is the LM22670TJE-ADJ/NOPB, from the PIC family. Other key parts include the SN74ALVC244NSR and XC5VLX110-3FFG1760C. By type, the board carries 12 capacitors, 10 connectors, 10 resistors, 3 ICs, 3 diodes and 1 crystal.
It belongs with the sensors designs in this gallery.
From the project
Microchip PIC32MX795F512L With uCOS RTOS and Accel Gyro driver port from arduino
Microchip PIC32MX795F512L With uCOS RTOS and Accel Gyro driver port from arduino
1. Install the xc32 compiler from microchip 2. Modify Makefile to point CC to the to where the compiler is located 3. type make
A binary (same as a .elf) and a .hex file will be placed in the BIN directory
In side Makefile, you can modify the DIRS variable to include new folders to compile.
Main components on the Quad copter
Quad copter bill of materials (BOM)
40 components, 32 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | SN74ALVC244NSR LT1085-3.3 | TO-263-3_TabPin2 | U1 |
| 1 | XC5VLX110-3FFG1760C accel_gyro_conn | PinSocket_1x08_P2.54mm_Vertical | U3 |
| 1 | LM22670TJE-ADJ/NOPB PIC32MX795F512L-X_PT | TQFP-100_12x12mm_P0.4mm | U4 |
| 1 | Crystal_8MHz | HC49UP | Y1 |
| 2 | 12226-8250-00FR Conn_01x03_Male | PinHeader_1x03_P2.54mm_Vertical | J1, J4 |
| 1 | 141-0701-201 Conn_01x03_Male | PinHeader_1x03_P2.54mm_Vertical | J2 |
| 1 | Conn_01x03_Male | PinHeader_1x03_P2.54mm_Vertical | J3 |
| 1 | 2-5177986-5 Conn_02x05_Odd_Even | PinHeader_2x05_P2.54mm_Vertical | J5 |
| 1 | 961103-6404-AR Conn_02x02_Odd_Even | PinHeader_2x02_P2.54mm_Vertical | J6 |
| 1 | 961103-6404-AR Conn_02x04_Odd_Even | PinHeader_2x04_P2.54mm_Vertical | J8 |
| 1 | 87831-1420 Conn_02x03_Odd_Even | PinHeader_2x03_P2.54mm_Vertical | J10 |
| 1 | ASP-134488-01 Conn_01x05 | PinHeader_1x05_P2.54mm_Vertical | J11 |
| 1 | ASP-134488-01 USB_B_Micro | USB_Micro-B_Amphenol_10103594-0001LF_Horizontal | J12 |
| 1 | MOMENTARY-SWITCH-SPST-2-SMD-5.2MM | TACTILE_SWITCH_SMD_5.2MM | S1 |
| 2 | B540C-13-F LED | LED_1206_3216Metric_Pad1.42x1.75mm_HandSolder | D1, D2 |
| 1 | APHCM2012CGCK-F01 LED | LED_1206_3216Metric_Pad1.42x1.75mm_HandSolder | D3 |
| 1 | ECJ-0EB1E103K C_10uF | C_0805_2012Metric_Pad1.15x1.40mm_HandSolder | C1 |
| 1 | ECJ-0EB1E103K C_22uF | C_1206_3216Metric_Pad1.42x1.75mm_HandSolder | C2 |
| 2 | ECJ-0EB1E103K C26pF | C_0603_1608Metric_Pad1.05x0.95mm_HandSolder | C4, C5 |
| 1 | ECJ-0EB1E103K C10uF | C_0603_1608Metric_Pad1.05x0.95mm_HandSolder | C6 |
Show 12 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 2 | ECJ-0EB1E103K C.1uF | C_0603_1608Metric_Pad1.05x0.95mm_HandSolder | C7, C8 |
| 2 | ECJ-0EB1E103K C_.1uF | C_0603_1608Metric_Pad1.05x0.95mm_HandSolder | C9, C10 |
| 2 | C.1uF | C_0603_1608Metric_Pad1.05x0.95mm_HandSolder | C11, C13 |
| 1 | T520L337M2R5ATE025 C.1uF | C_0603_1608Metric_Pad1.05x0.95mm_HandSolder | C12 |
| 1 | ERJ-2GEJ271X R_56 | R_0805_2012Metric_Pad1.15x1.40mm_HandSolder | R1 |
| 2 | ERJ-2GEJ271X R10K | R_0805_2012Metric_Pad1.15x1.40mm_HandSolder | R2, R4 |
| 1 | ERJ-2GEJ271X R2.8k | R_0805_2012Metric_Pad1.15x1.40mm_HandSolder | R3 |
| 1 | ERJ-2GEJ271X R470 | R_0603_1608Metric_Pad1.05x0.95mm_HandSolder | R5 |
| 2 | ERJ-2GEJ331X R_56 | R_0805_2012Metric_Pad1.15x1.40mm_HandSolder | R8, R9 |
| 1 | ERJ-6ENF6192V R2.4k | R_0805_2012Metric_Pad1.15x1.40mm_HandSolder | R12 |
| 1 | ERJ-6ENF1581V R2.4k | R_0805_2012Metric_Pad1.15x1.40mm_HandSolder | R13 |
| 1 | ERJ-6ENF1001V R10 | R_0805_2012Metric_Pad1.15x1.40mm_HandSolder | R14 |
Quad copter design files
The KiCad project lives in the mtilson115/quad_copter repository on GitHub; these links point at the commit this page was built from.
Quad copter: common questions
What microcontroller does the Quad copter use?
The Quad copter is built around the LM22670TJE-ADJ/NOPB, from the PIC family.
How big is the Quad copter PCB?
The Quad copter measures 44.3 × 99.8 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Quad copter?
40 components, from 32 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Quad copter design files?
From the mtilson115/quad_copter repository on GitHub, which has the KiCad layout and the BOM; the links under Design files point to each one.
Can I use the Quad copter design in my own project?
Yes, under the terms of its GPL-2.0 license, which mtilson115 chose for the repository.
Can I test firmware for the Quad copter without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug PIC firmware against it before you order a PCB.
Similar boards
 PIC
Pslab hardware
fossasia
99 × 53.3 mm187 parts4LApache-2.01.7k PIC
Lens
ervanalb
80 × 80 mm53 parts4LNo license515 PIC
Micro 8088
skiselev
152.4 × 101.6 mm71 partsGPL-3.0414 PIC
GB-CART256K-A
Gekkio
51.4 × 61 mm17 parts2LCC-BY-4.0379 PIC
GB-CARTPP-DIY
100 × 100 mm22 parts2LCC-BY-4.0379 PIC
GB-LIVE32
51.4 × 61 mm46 parts4LCC-BY-4.0379