
Emg robotic hand

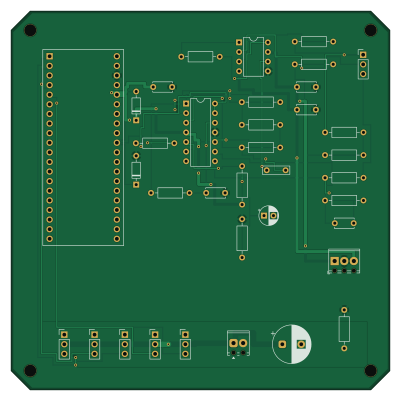
About the Emg robotic hand PCB
Emg robotic hand is an open source RP2040/RP2350 PCB design by Pai-88, published on GitHub under the MIT license. It is a 2-layer board measuring 100 × 100 mm, with 36 components from 27 distinct parts.
Its main chip is the Pico / RP2040, from the RP2040/RP2350 family. Other key parts include the AD623AN and MCP6004. By type, the board carries 15 resistors, 9 connectors, 8 capacitors, 2 ICs and 2 diodes.
It belongs with the robotics & motion designs in this gallery.
From the project
Single-channel surface-EMG front end (AD623 + driven-right-leg) on a Raspberry Pi Pico. Board fabricated and telemetry verified on hardware; analog front end and on-body EMG still in bring-up.
A wearable single-channel surface-EMG front end that reads how hard a forearm muscle contracts and drives a robotic gripper proportionally. The whole control loop runs on a Raspberry Pi Pico rather than on a PC: squeeze harder and the grip closes further, relax and it opens.
The rev E board is built and the digital side works on real hardware. The analog front end has not been powered yet, so no EMG has been recorded from skin. What has been checked so far:
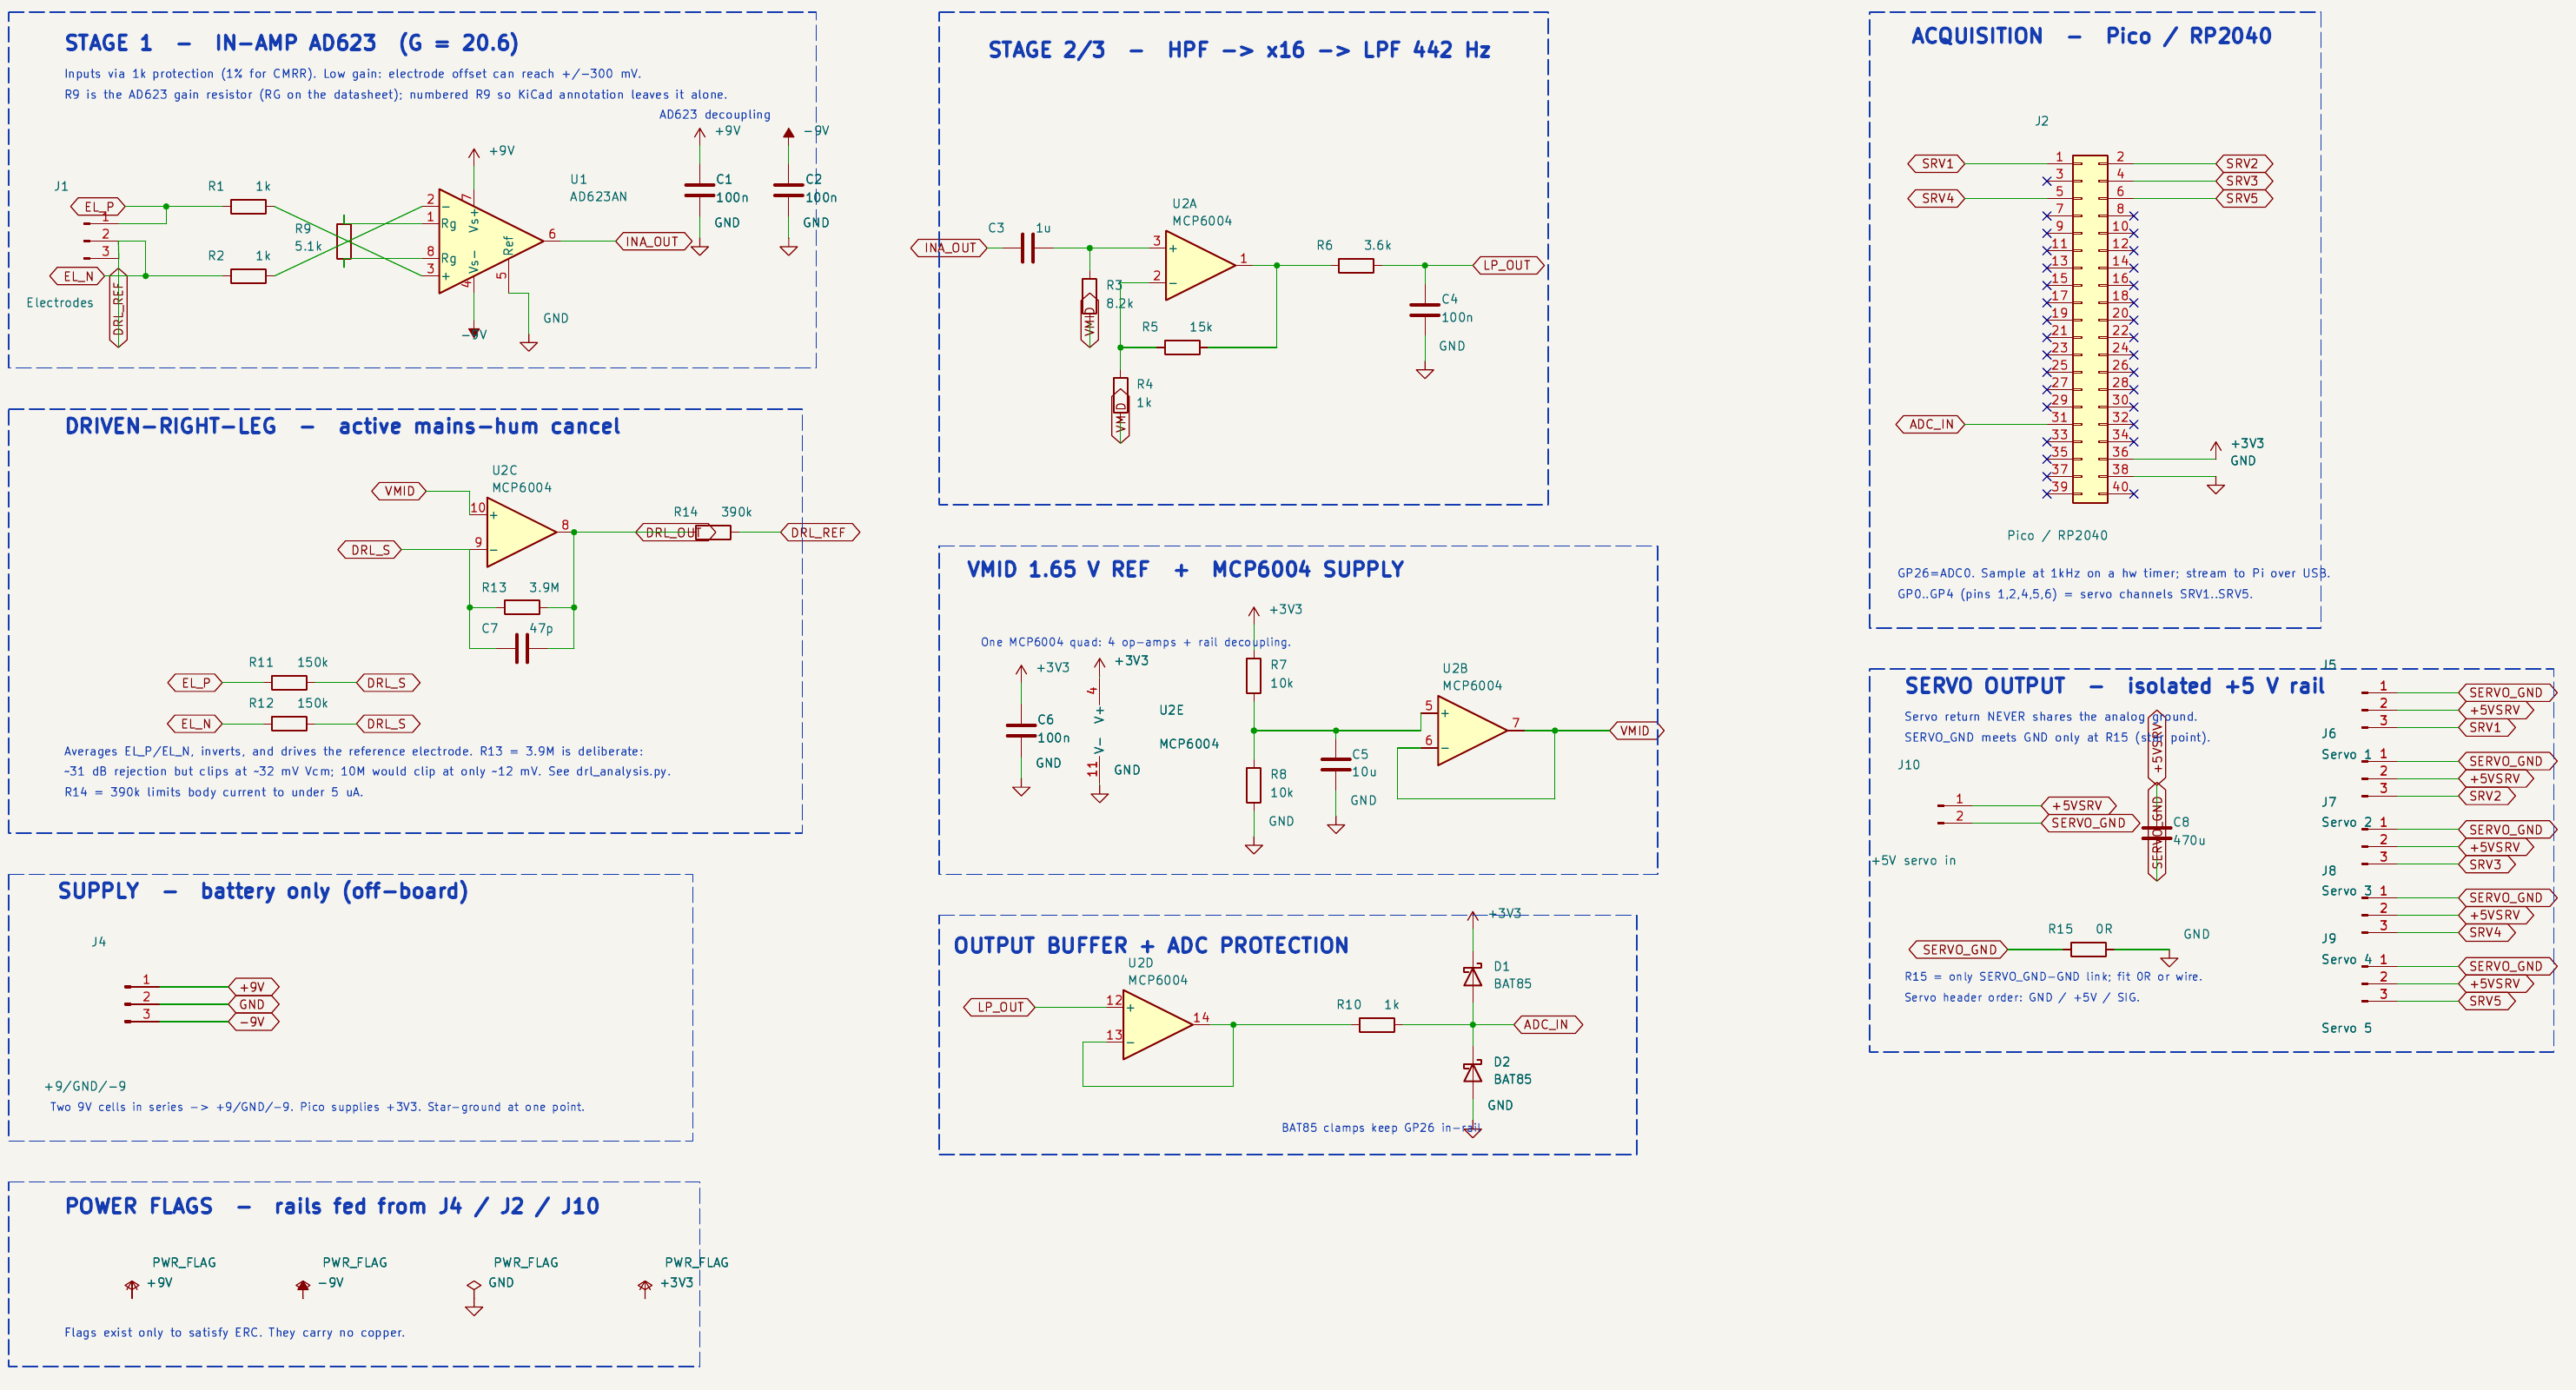
Main components on the Emg robotic hand
Emg robotic hand bill of materials (BOM)
36 components, 27 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | AD623AN | DIP-8_W7.62mm | U1 |
| 1 | MCP6004 | DIP-14_W7.62mm | U2 |
| 1 | Electrodes | PinHeader_1x03_P2.54mm_Vertical | J1 |
| 1 | Pico / RP2040 | Pico_Socket_2x1x20 | J2 |
| 1 | +9/GND/-9 | TerminalBlock_Phoenix_MPT-0,5-3-2.54_1x03_P2.54mm_Horizontal | J4 |
| 1 | Servo 1 | PinHeader_1x03_P2.54mm_Vertical | J5 |
| 1 | Servo 2 | PinHeader_1x03_P2.54mm_Vertical | J6 |
| 1 | Servo 3 | PinHeader_1x03_P2.54mm_Vertical | J7 |
| 1 | Servo 4 | PinHeader_1x03_P2.54mm_Vertical | J8 |
| 1 | Servo 5 | PinHeader_1x03_P2.54mm_Vertical | J9 |
| 1 | +5V servo in | TerminalBlock_Phoenix_MPT-0,5-2-2.54_1x02_P2.54mm_Horizontal | J10 |
| 2 | BAT85 | D_DO-35_SOD27_P7.62mm_Horizontal | D1, D2 |
| 4 | 100n | C_Disc_D5.0mm_W2.5mm_P5.00mm | C1, C2, C4, C6 |
| 1 | 1u | C_Rect_L7.0mm_W2.0mm_P5.00mm | C3 |
| 1 | 10u | CP_Radial_D5.0mm_P2.50mm | C5 |
| 1 | 47p | C_Disc_D5.0mm_W2.5mm_P5.00mm | C7 |
| 1 | 470u | CP_Radial_D10.0mm_P5.00mm | C8 |
| 4 | 1k | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R1, R2, R4, R10 |
| 1 | 8.2k | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R3 |
| 1 | 15k | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R5 |
Show 7 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | 3.6k | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R6 |
| 2 | 10k | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R7, R8 |
| 1 | 5.1k | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R9 |
| 2 | 150k | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R11, R12 |
| 1 | 3.9M | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R13 |
| 1 | 390k | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R14 |
| 1 | 0R | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R15 |
Emg robotic hand design files
The KiCad project lives in the Pai-88/emg-robotic-hand repository on GitHub; these links point at the commit this page was built from.
Emg robotic hand: common questions
What microcontroller does the Emg robotic hand use?
The Emg robotic hand is built around the Pico / RP2040, from the RP2040/RP2350 family.
How big is the Emg robotic hand PCB?
The Emg robotic hand measures 100 × 100 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Emg robotic hand?
36 components, from 27 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Emg robotic hand design files?
From the Pai-88/emg-robotic-hand repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the Emg robotic hand design in my own project?
Yes, under the terms of its MIT license, which Pai-88 chose for the repository.
Can I test firmware for the Emg robotic hand without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug RP2040/RP2350 firmware against it before you order a PCB.
Similar boards
 RP2040/RP2350
Open Book Abridged Edition
joeycastillo
85 × 115 mm29 parts2LCC-BY-SA-4.08.1k RP2040/RP2350
Corne
foostan
277.2 × 107.5 mm164 parts2LCC-BY-4.07.7k RP2040/RP2350
Corne
277.2 × 107.5 mm164 parts2LCC-BY-4.07.7k RP2040/RP2350
Msa
Mentra-Community
47.8 × 9.4 mm53 parts2LMIT1.2k RP2040/RP2350
Open Source Smart Glasses
93 × 10.5 mm80 parts4LMIT1.2k RP2040/RP2350
MSA
30.5 × 138 mm61 parts2LMIT1.2k