
Industrial robot arm digital twin

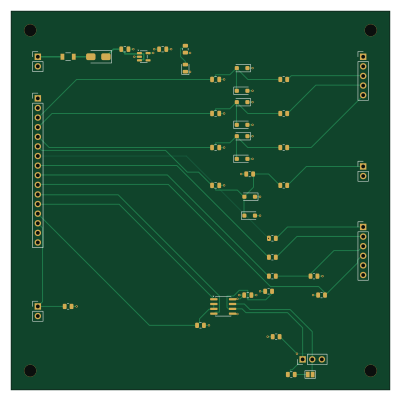
About the Industrial robot arm digital twin PCB
Industrial robot arm digital twin is an open source PCB design by pratham-cloud-ctrl, published on GitHub under the MIT license. It is a 4-layer board measuring 100 × 100 mm, with 44 components from 22 distinct parts.
Other key parts include the AP2112K-3.3 and LTC2850IS8. By type, the board carries 16 resistors, 10 diodes, 7 connectors, 7 capacitors, 2 ICs and 1 fuse.
It belongs with the robotics & motion designs in this gallery.
From the project
Original six-axis digital robot arm and parallel gripper: illustrated CAD, KiCad electronics, engineering theory, simulation and reproducible validation.
Inspect the interactive PCB · Rotate the 3D board · Zoom the schematic
Search components, cross-highlight the BOM, follow connected nets and inspect the actual board without installing KiCad.
Start with the illustrated circuit and PCB tour. Follow the regulated supply, encoder/limit inputs, external-drive commands and RS-485 interface, then match each block to the schematic and board.
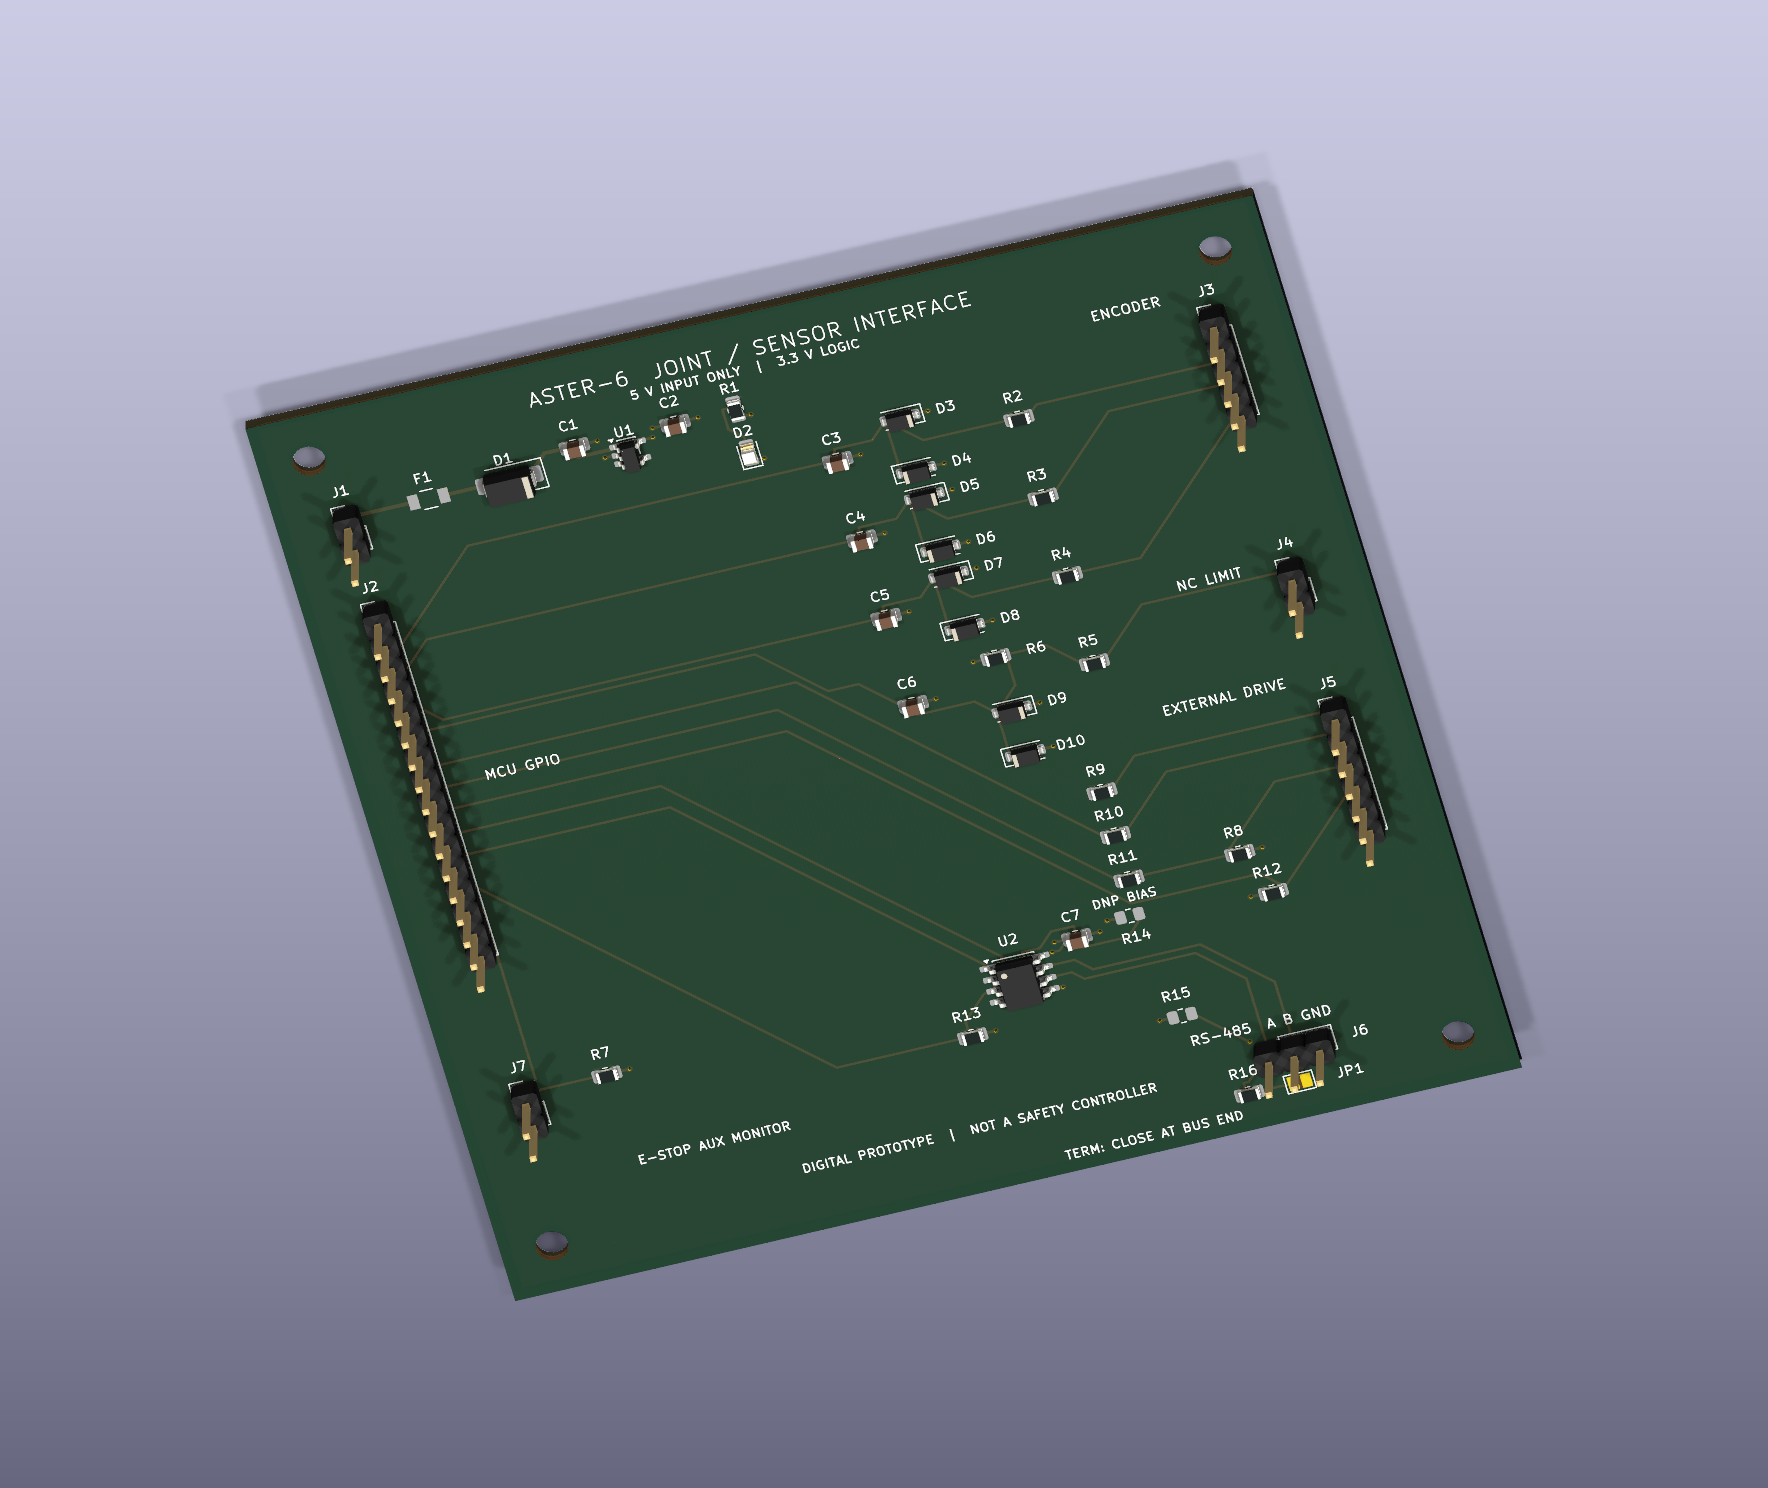
Main components on the Industrial robot arm digital twin
Industrial robot arm digital twin bill of materials (BOM)
44 components, 22 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | AP2112K-3.3 | SOT-23-5 | U1 |
| 1 | LTC2850IS8 | SOIC-8_3.9x4.9mm_P1.27mm | U2 |
| 1 | 5V INPUT | PinHeader_1x02_P2.54mm_Vertical | J1 |
| 1 | MCU 3V3 I/O | PinHeader_1x16_P2.54mm_Vertical | J2 |
| 1 | ENCODER 3V3 | PinHeader_1x05_P2.54mm_Vertical | J3 |
| 1 | NC LIMIT | PinHeader_1x02_P2.54mm_Vertical | J4 |
| 1 | 3V3 DRIVE I/O | PinHeader_1x06_P2.54mm_Vertical | J5 |
| 1 | RS485 BUS | PinHeader_1x03_P2.54mm_Vertical | J6 |
| 1 | E-STOP AUX NC | PinHeader_1x02_P2.54mm_Vertical | J7 |
| 1 | MF-NSMF025X-2 | PTC_Bourns_MF-NSMF025X_1206 | F1 |
| 1 | END TERM | SolderJumper-2_P1.3mm_Open_Pad1.0x1.5mm | JP1 |
| 1 | SS14 | D_SMA | D1 |
| 1 | GREEN | LED_0805_2012Metric | D2 |
| 8 | BAT54H | D_SOD-123F | D3, D4, D5, D6, D7, D8, D9, D10 |
| 1 | 10uF / 10V | C_0805_2012Metric | C1 |
| 1 | 4.7uF / 10V | C_0805_2012Metric | C2 |
| 3 | 100pF / 50V | C_0805_2012Metric | C3, C4, C5 |
| 2 | 100nF / 50V | C_0805_2012Metric | C6, C7 |
| 5 | 1k | R_0805_2012Metric | R1, R2, R3, R4, R5 |
| 5 | 10K 10k | R_0805_2012Metric | R6, R7, R8, R12, R13 |
Show 2 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 5 | 330 | R_0805_2012Metric | R9, R10, R11, R14, R15 |
| 1 | 120 | R_0805_2012Metric | R16 |
Industrial robot arm digital twin design files
The KiCad project lives in the pratham-cloud-ctrl/industrial-robot-arm-digital-twin repository on GitHub; these links point at the commit this page was built from.
Industrial robot arm digital twin: common questions
How big is the Industrial robot arm digital twin PCB?
The Industrial robot arm digital twin measures 100 × 100 mm, has 4 copper layers and is 1.6 mm thick.
How many components are on the Industrial robot arm digital twin?
44 components, from 22 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Industrial robot arm digital twin design files?
From the pratham-cloud-ctrl/industrial-robot-arm-digital-twin repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the Industrial robot arm digital twin design in my own project?
Yes, under the terms of its MIT license, which pratham-cloud-ctrl chose for the repository.
Similar boards

Stack chan
stack-chan
50 × 50 mm33 parts2LApache-2.01.7k
Cube batteryboard
willem-pennings
95 × 95 mm4 parts2LGPL-3.01.1k
Trollerv2
rene-dev
100 × 75 mm33 parts4LGPL-3.0979
Powerstep
95.2 × 71.5 mm28 parts4LGPL-3.0979
11ua
57.3 × 19 mm26 parts2LGPL-3.0979
Diff driver
32 × 22 mm14 parts2LGPL-3.0979