
Workbench-1 Controller

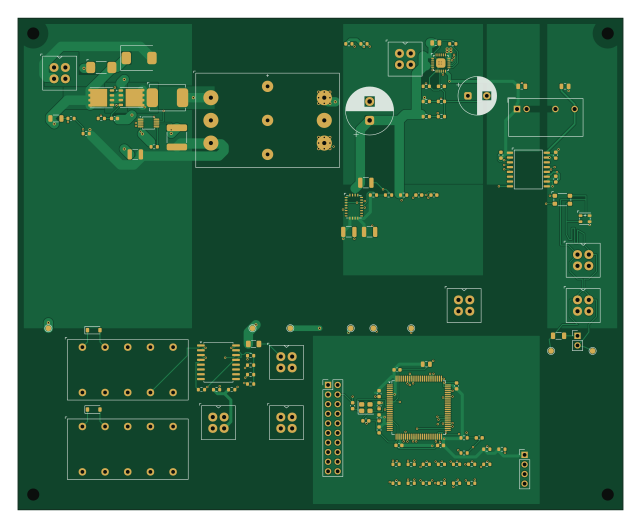
About the Workbench-1 Controller PCB
Workbench-1 Controller is an open source RISC-V PCB design by Quchaosheng, published on GitHub under the Apache-2.0 license. It is a 8-layer board measuring 160 × 130 mm, with 106 components from 62 distinct parts.
Its main chip is the WCH CH32V307VCT6, from the RISC-V family. Other key parts include the LTC4368HMS-2#PBF, TBD_36_60V_TO_12V_240W_ISOLATED, Texas Instruments TPS26633RGER, RECOM RPL-5.0-R and Texas Instruments ISO1042DWR. By type, the board carries 31 resistors, 25 capacitors, 10 connectors, 8 ICs, 4 diodes and 2 transistors.
It belongs with the robotics & motion and test & measurement designs in this gallery.
From the project
Evidence-first runtime for a wheeled mobile household robot with bounded actions, replayable events, and fail-closed verification.
Eight-layer controller/power-distribution board for a 48 V desk robot. The package defines the electrical architecture, interfaces, protection, isolated CAN, stackup, placement/thermal constraints, DFM limits, and manufacturing outputs.
The report is written to generated/electricalreport.json. Open kicad/controller.kicadpro with KiCad 10. The detailed EVT companion board has 110 controlled electrical components, four M3 NPTH mounting holes (114 total footprints), eight SMT test pads, 1,250 track/via items, 31 filled copper zones, eight copper layers, and a physical 8 mm primary/secondary…
Main components on the Workbench-1 Controller
Workbench-1 Controller bill of materials (BOM)
106 components, 62 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | LTC4368HMS-2#PBF LTC4368HMS-2 | MSOP-10_3x3mm_P0.5mm | U1 |
| 1 | TBD_36_60V_TO_12V_240W_ISOLATED ISOLATED 48V-12V 240W (TBD) | Isolated_48V_12V_240W_TBD | U2 |
| 1 | Texas Instruments TPS26633RGER TPS26633RGE | TPS26633_RGE24 | U3 |
| 1 | RECOM RPL-5.0-R RPL-5.0 3V3/5A | RPL-5.0_QFN24 | U4 |
| 1 | WCH CH32V307VCT6 CH32V307VCT6 | LQFP-100_14x14mm_P0.5mm | U5 |
| 1 | Texas Instruments ISO1042DWR ISO1042DW | ISO1042_DW16_HV | U6 |
| 1 | Murata MEJ1S0305SC 3V3-5V ISO 1W | Converter_DCDC_muRata_MEJ1SxxxxSC_THT | U7 |
| 1 | Toshiba TLP293-4(GB,E) ESTOP DIAGNOSTIC OPTO | SOIC-16W_7.5x10.3mm_P1.27mm | U8 |
| 2 | Infineon BSC093N15NS5ATMA1 150V N-MOS | Infineon_PG-TDSON-8_6.15x5.15mm | Q1, Q2 |
| 1 | Abracon ABM8-8.000MHZ-B2-T 8MHz | Crystal_SMD_3225-4Pin_3.2x2.5mm | Y1 |
| 1 | Molex 43045-0412 48V INPUT | MicroFit_2x2 | J1 |
| 1 | Molex 43045-0412 12V MOTOR AUX | MicroFit_2x2 | J2 |
| 1 | Molex 43045-0412 JETSON DEVKIT 12V | MicroFit_2x2 | J3 |
| 1 | JETSON MCU BACKPLANE | PinHeader_2x10_P2.54mm_Vertical | J4 |
| 1 | Molex 43045-0412 CAN A | MicroFit_2x2 | J5 |
| 1 | Molex 43045-0412 CAN B | MicroFit_2x2 | J6 |
| 1 | Molex 43045-0412 DUAL ESTOP LOOP | MicroFit_2x2 | J10 |
| 1 | Molex 43045-0412 SAFETY OUTPUT | MicroFit_2x2 | J11 |
| 1 | Molex 43045-0412 DUAL MANUAL RESET | MicroFit_2x2 | J12 |
| 1 | WCH DEBUG | PinHeader_1x04_P2.54mm_Vertical | J13 |
Show 42 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | 4.7nF 100V | C_0603_1608Metric | CG1 |
| 1 | 22nF | C_0603_1608Metric | CSS4 |
| 2 | 18pF | C_0603_1608Metric | CY1, CY2 |
| 1 | Littelfuse 0451010.MRL 10A 125V | Fuse_4510 | F1 |
| 1 | Littelfuse 1206L025YR PTC 0.25A | Fuse_1206_3216Metric | F2 |
| 4 | M3_NPTH | H1, H2, H3, H4 | |
| 1 | CAN TERM | PinHeader_1x02_P2.54mm_Vertical | JP1 |
| 1 | Panasonic SFM4-DC12V FORCE-GUIDED 12V A | Panasonic_SFM4 | K1 |
| 1 | Panasonic SFM4-DC12V FORCE-GUIDED 12V B | Panasonic_SFM4 | K2 |
| 1 | 45.0k 1% | R_0603_1608Metric | RFB1 |
| 1 | 10.0k 1% | R_0603_1608Metric | RFB2 |
| 1 | 22k | R_0603_1608Metric | RG1 |
| 1 | 453k 1% | R_0603_1608Metric | RPG1 |
| 1 | 56.0k 1% | R_0603_1608Metric | RPG2 |
| 1 | 10k | R_0603_1608Metric | RPG3 |
| 1 | Vishay WSL3637R0060FEA 6mR 3W 1% | Sense_3637 | RS1 |
| 1 | 510k | R_0603_1608Metric | RSH1 |
| 1 | 19.6M 1% | R_1206_3216Metric | RUV1 |
| 1 | 133k 1% | R_0603_1608Metric | RUV2 |
| 1 | 162k 1% | R_0603_1608Metric | RUV3 |
| 1 | Littelfuse SMCJ58A SMCJ58A | D_SMC | D1 |
| 1 | Nexperia PESD2CANFD24V-T CAN FD TVS | CAN_TVS | D2 |
| 2 | Diodes Inc. 1N4148W-7-F FLYBACK | D_SOD-123 | D3, D4 |
| 1 | TDK ACT45B-101-2P-TL003 100R@100MHz | ACT45B | L1 |
| 1 | 1uF 100V | C_1210_3225Metric | C1 |
| 1 | 10uF 100V | C_2220_5750Metric | C2 |
| 1 | 470uF 25V | CP_Radial_D12.5mm_P5.00mm | C3 |
| 1 | 1uF 25V | C_0805_2012Metric | C4 |
| 1 | 220uF 25V | CP_Radial_D10.0mm_P5.00mm | C5 |
| 1 | 22uF 25V | C_1210_3225Metric | C6 |
| 2 | 47uF 10V | C_1210_3225Metric | C7, C8 |
| 13 | 100nF | C_0603_1608Metric | C9, C10, C11, C12, C13, C14, C15, C16 +5 |
| 3 | 4.7uF | C_0805_2012Metric | C17, C42, C43 |
| 1 | 1uF 10V | C_0603_1608Metric | C20 |
| 13 | 33R | R_0603_1608Metric | R30, R31, R32, R33, R34, R35, R36, R37 +5 |
| 5 | 100k | R_0603_1608Metric | R43, R44, R45, R46, R57 |
| 5 | 10k | R_0603_1608Metric | R47, R49, R50, R51, R54 |
| 1 | 3.00k 1% | R_0603_1608Metric | R48 |
| 4 | 4.7k | R_0603_1608Metric | R52, R53, R55, R56 |
| 1 | 120R 1% | R_1206_3216Metric | R58 |
| 1 | 73.2k 1% | R_0603_1608Metric | R59 |
| 1 | 10.0k 1% | R_0603_1608Metric | R60 |
Workbench-1 Controller design files
The KiCad project lives in the Quchaosheng/workbench-mobile-home-robot repository on GitHub; these links point at the commit this page was built from.
Workbench-1 Controller: common questions
What microcontroller does the Workbench-1 Controller use?
The Workbench-1 Controller is built around the WCH CH32V307VCT6, from the RISC-V family.
How big is the Workbench-1 Controller PCB?
The Workbench-1 Controller measures 160 × 130 mm, has 8 copper layers and is 1.6 mm thick.
How many components are on the Workbench-1 Controller?
106 components, from 62 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Workbench-1 Controller design files?
From the Quchaosheng/workbench-mobile-home-robot repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the Workbench-1 Controller design in my own project?
Yes, under the terms of its Apache-2.0 license, which Quchaosheng chose for the repository.
Can I test firmware for the Workbench-1 Controller without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug RISC-V firmware against it before you order a PCB.
More boards in workbench-mobile-home-robot
Similar boards
 RISC-V
Back
johanwheeler
82 × 82 mm145 parts2LMIT32 RISC-V
OneButton
usr-ein
20 × 20 mm13 parts2LGPL-3.010 RISC-V
Cheep3a
emeb
27.9 × 108 mm84 parts4LMIT9 RISC-V
WCH-LinkE-Mini
21km43
38.1 × 15.2 mm35 parts2LMIT3 RISC-V
B-Sides 2025
OklahomaOpenSourceHardware
111.8 × 119 mm39 parts2LNo license3 RISC-V
ZigZag
RadionaOrg
79.9 × 29.7 mm33 parts2LGPL-3.03