
RoboRIO Interface

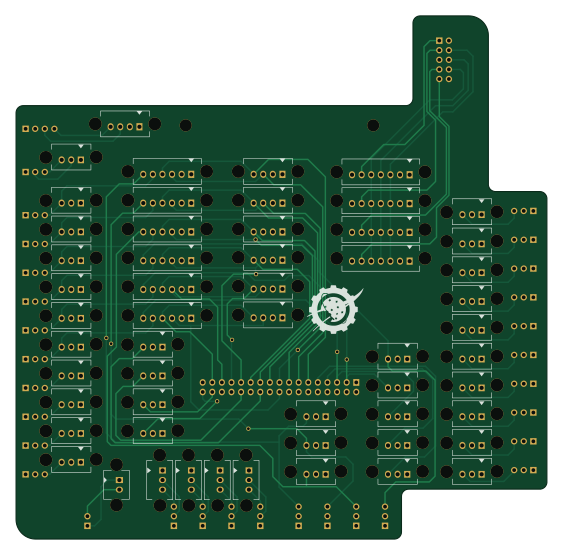
About the RoboRIO Interface PCB
RoboRIO Interface is an open source PCB design by RealtimeRoboticsGroup, published on GitHub under the SHL-2.1 license. It is a 4-layer board measuring 140.5 × 138.4 mm, with 88 components from 88 distinct parts.
From the project
This project is open-source hardware and is licensed under the Solderpad Hardware License v2.1 (the "License"), which is a permissive license based on the Apache License, Version 2.0.
This project is open-source hardware and is licensed under the Solderpad Hardware License v2.1 (the "License"), which is a permissive license based on the Apache License, Version 2.0.
You may use this work under the terms of the Solderpad Hardware License v2.1, or, at your option, under the terms of the Apache License, Version 2.0.
- Solderpad v2.1: Solderpad Hardware License v2.1 - Solderpad Hardware License
RoboRIO Interface bill of materials (BOM)
88 components, 88 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | 0705410037 DIO0 | 70541-0002 | J1 |
| 1 | 0705410037 DIO1 | 70541-0002 | J2 |
| 1 | 0705410037 DIO2 | 70541-0002 | J3 |
| 1 | 0705410037 DIO3 | 70541-0002 | J4 |
| 1 | 0705410037 DIO4 | 70541-0002 | J5 |
| 1 | 0705410037 DIO5 | 70541-0002 | J6 |
| 1 | DIO6 | 70541-0002 | J7 |
| 1 | DIO7 | 70541-0002 | J8 |
| 1 | DIO8 | 70541-0002 | J9 |
| 1 | DIO9 | 70541-0002 | J10 |
| 1 | DIO22 | 70541-0002 | J11 |
| 1 | DIO23 | 70541-0002 | J12 |
| 1 | DIO24 | 70541-0002 | J13 |
| 1 | DIO25 | 70541-0002 | J14 |
| 1 | PPTC031LFBN-RC RR_DIO0 | PinSocket_1x03_P2.54mm_Vertical | J15 |
| 1 | PPTC031LFBN-RC RR_DIO1 | PinSocket_1x03_P2.54mm_Vertical | J16 |
| 1 | PPTC031LFBN-RC RR_DIO2 | PinSocket_1x03_P2.54mm_Vertical | J17 |
| 1 | PPTC031LFBN-RC RR_DIO3 | PinSocket_1x03_P2.54mm_Vertical | J18 |
| 1 | PPTC031LFBN-RC RR_DIO4 | PinSocket_1x03_P2.54mm_Vertical | J19 |
| 1 | PPTC031LFBN-RC RR_DIO5 | PinSocket_1x03_P2.54mm_Vertical | J20 |
Show 68 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | RR_DIO6 | PinSocket_1x03_P2.54mm_Vertical | J21 |
| 1 | RR_DIO7 | PinSocket_1x03_P2.54mm_Vertical | J22 |
| 1 | RR_DIO8 | PinSocket_1x03_P2.54mm_Vertical | J23 |
| 1 | PPTC031LFBN-RC RR_DIO9 | PinSocket_1x03_P2.54mm_Vertical | J24 |
| 1 | ENC0 | 70541-0003 | J25 |
| 1 | ENC1 | 70541-0003 | J26 |
| 1 | ENC2 | 70541-0003 | J27 |
| 1 | ENC3 | 70541-0003 | J28 |
| 1 | ENC4 | 70541-0003 | J29 |
| 1 | ENC5 | 70541-0003 | J30 |
| 1 | ENC_AD0 | 70541-0005 | J31 |
| 1 | ENC_AD1 | 70541-0005 | J32 |
| 1 | ENC_AD2 | 70541-0005 | J33 |
| 1 | ENC_AD3 | 70541-0005 | J34 |
| 1 | ENC_AD4 | 70541-0005 | J35 |
| 1 | ENC_AD5 | 70541-0005 | J36 |
| 1 | RLY0 | 70541-0002 | J37 |
| 1 | RLY1 | 70541-0002 | J38 |
| 1 | RLY2 | 70541-0002 | J39 |
| 1 | RLY3 | 70541-0002 | J40 |
| 1 | 0705410037 AIN0 | 70541-0002 | J41 |
| 1 | 0705410037 AIN1 | 70541-0002 | J42 |
| 1 | 0705410037 AIN2 | 70541-0002 | J43 |
| 1 | AIN3 | 70541-0002 | J44 |
| 1 | AIN4 | 70541-0002 | J45 |
| 1 | AIN5 | 70541-0002 | J46 |
| 1 | AIN6 | 70541-0002 | J47 |
| 1 | AIN7 | 70541-0002 | J48 |
| 1 | RR_RELAY0 | PinSocket_1x03_P2.54mm_Vertical | J49 |
| 1 | RR_RELAY1 | PinSocket_1x03_P2.54mm_Vertical | J50 |
| 1 | RR_RELAY2 | PinSocket_1x03_P2.54mm_Vertical | J51 |
| 1 | RR_RELAY3 | PinSocket_1x03_P2.54mm_Vertical | J52 |
| 1 | PPTC031LFBN-RC RR_AIN0 | PinSocket_1x03_P2.54mm_Vertical | J53 |
| 1 | PPTC031LFBN-RC RR_AIN1 | PinSocket_1x03_P2.54mm_Vertical | J54 |
| 1 | PPTC031LFBN-RC RR_AIN2 | PinSocket_1x03_P2.54mm_Vertical | J55 |
| 1 | RR_AIN3 | PinSocket_1x03_P2.54mm_Vertical | J56 |
| 1 | 0705410037 PWM0 | 70541-0002 | J57 |
| 1 | 0705410037 PWM1 | 70541-0002 | J58 |
| 1 | 0705410037 PWM2 | 70541-0002 | J59 |
| 1 | PWM3 | 70541-0002 | J60 |
| 1 | PWM4 | 70541-0002 | J61 |
| 1 | PWM5 | 70541-0002 | J62 |
| 1 | PWM6 | 70541-0002 | J63 |
| 1 | PWM7 | 70541-0002 | J64 |
| 1 | PWM8 | 70541-0002 | J65 |
| 1 | PWM9 | 70541-0002 | J66 |
| 1 | PPTC031LFBN-RC RR_PWM0 | PinSocket_1x03_P2.54mm_Vertical | J67 |
| 1 | PPTC031LFBN-RC RR_PWM1 | PinSocket_1x03_P2.54mm_Vertical | J68 |
| 1 | PPTC031LFBN-RC RR_PWM2 | PinSocket_1x03_P2.54mm_Vertical | J69 |
| 1 | RR_PWM3 | PinSocket_1x03_P2.54mm_Vertical | J70 |
| 1 | RR_PWM4 | PinSocket_1x03_P2.54mm_Vertical | J71 |
| 1 | RR_PWM5 | PinSocket_1x03_P2.54mm_Vertical | J72 |
| 1 | RR_PWM6 | PinSocket_1x03_P2.54mm_Vertical | J73 |
| 1 | RR_PWM7 | PinSocket_1x03_P2.54mm_Vertical | J74 |
| 1 | RR_PWM8 | PinSocket_1x03_P2.54mm_Vertical | J75 |
| 1 | PPTC031LFBN-RC RR_PWM9 | PinSocket_1x03_P2.54mm_Vertical | J76 |
| 1 | 0705410036 RSL | 70541-0001 | J77 |
| 1 | 0705410037 RS232 | 70541-0002 | J78 |
| 1 | I2C | 70541-0003 | J79 |
| 1 | SPI0 | 70541-0006 | J80 |
| 1 | SPI1 | 70541-0006 | J81 |
| 1 | SPI2 | 70541-0006 | J82 |
| 1 | SPI3 | 70541-0006 | J83 |
| 1 | PPTC021LFBN-RC RR_RSL | PinSocket_1x02_P2.54mm_Vertical | J84 |
| 1 | PPTC031LFBN-RC RR_RS-232 | PinSocket_1x03_P2.54mm_Vertical | J85 |
| 1 | RR_I2C | PinSocket_1x04_P2.54mm_Vertical | J86 |
| 1 | RR_MXP | PinSocket_2x17_P2.54mm_Vertical | J87 |
| 1 | RR_SPI | PinSocket_2x05_P2.54mm_Vertical | J88 |
RoboRIO Interface design files
The KiCad project lives in the RealtimeRoboticsGroup/electrical repository on GitHub; these links point at the commit this page was built from.
RoboRIO Interface: common questions
How big is the RoboRIO Interface PCB?
The RoboRIO Interface measures 140.5 × 138.4 mm, has 4 copper layers and is 1.684 mm thick.
How many components are on the RoboRIO Interface?
88 components, from 88 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the RoboRIO Interface design files?
From the RealtimeRoboticsGroup/electrical repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the RoboRIO Interface design in my own project?
It is published under SHL-2.1, which limits how it may be reused; read the license before building on it.
More boards in electrical
 RP2040/RP2350
Pico Button Board
55.9 × 111.8 mm201 parts4LSHL-2.11 STM32
NX J401 Adapter
119.6 × 99.2 mm127 parts4LSHL-2.11 RP2040/RP2350
Beam Break Adapter
55.9 × 27.9 mm36 parts2LSHL-2.11
NX-IndicatorBoard V2
108.1 × 79 mm36 parts4LSHL-2.11
WCP Mag Encoder (WCP-2435)
19.9 × 27.8 mm22 parts4LSHL-2.11
Mini Power Distribution Board (WCP-1823)
84.4 × 36.8 mm19 parts2LSHL-2.11 RP2040/RP2350
Pico CAN-FD Adapter
70 × 53 mm13 parts2LSHL-2.11
CAN Hub
29.8 × 31.5 mm6 parts2LSHL-2.11
TEE CAN (WCP-1824)
27.9 × 14.5 mm5 parts2LSHL-2.11