
Motor Adapter

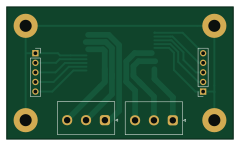
About the Motor Adapter PCB
Motor Adapter is an open source PCB design by robotronik, published on GitHub. It is a 2-layer board measuring 60 × 35 mm, with 6 components from 3 distinct parts.
By type, the board carries 4 connectors and 2 relays.
Motor Adapter bill of materials (BOM)
6 components, 3 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 2 | Hall_Sensor | PinSocket_1x05_P2.54mm_Vertical | J4, J5 |
| 2 | Conn_01x03_Female | JST_NV_B03P-NV_1x03_P5.00mm_Vertical | J6, J7 |
| 2 | Maxon-200142 | Molex-52610-1133 | K1, K2 |
Motor Adapter design files
The KiCad project lives in the robotronik/cdfr2019-2A-Electronic repository on GitHub; these links point at the commit this page was built from.
Motor Adapter: common questions
How big is the Motor Adapter PCB?
The Motor Adapter measures 60 × 35 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Motor Adapter?
6 components, from 3 distinct parts. The full bill of materials is listed on this page.
Where can I download the Motor Adapter design files?
From the robotronik/cdfr2019-2A-Electronic repository on GitHub, which has the KiCad layout; the links under Design files point to each one.
Can I use the Motor Adapter design in my own project?
The repository has no license, so all rights stay with robotronik. Use it as a reference, and ask the author before reusing the design.
More boards in cdfr2019-2A-Electronic
 STM32
Motor Card-V1
140 × 60 mm94 parts2LNo license1
Power Circuit
142.2 × 102.9 mm49 parts2LNo license1
Asservissement Shield
84 × 68.4 mm49 parts2LNo license1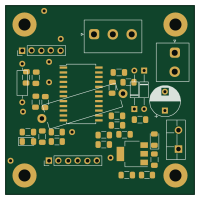
Driver brushless
50 × 50 mm34 parts2LNo license1
Encoder Level Shifter
22 × 23 mm12 parts2LNo license1