Roboy 3.0 40mm magnetic field calibration

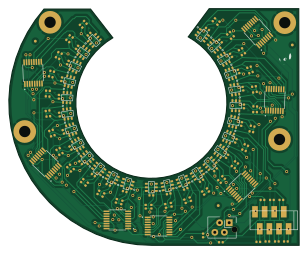
About the Roboy 3.0 40mm magnetic field calibration PCB
Roboy 3.0 40mm magnetic field calibration is an open source PCB design by Roboy, published on GitHub under the BSD-3-Clause license. It is a 2-layer board measuring 76.8 × 62.6 mm, with 125 components from 9 distinct parts.
Other key parts include the TLE493d and TCA9546APWR. By type, the board carries 61 resistors, 33 ICs, 26 capacitors and 2 connectors.
From the project
estimator for angles and ball in socket joint
Pytorch conda install pytorch torchvision torchaudio cudatoolkit=10.2 -c pytorch`
Switch to python folder as your working directory cd python
Generate data using python particleswarm.py --bodypart BODYPART
with BODYPART = {head, shoulderleft, shoulderright, handleft, handright}`
- /roboy/pinky/sensing/externaljointstates - /roboy/pinky/middleware/MagneticSensor - /trackingloss - /roboy/pinky/control/cardsflowjointstates - /roboy/pinky/simulation/jointtargets
Main components on the Roboy 3.0 40mm magnetic field calibration
Roboy 3.0 40mm magnetic field calibration bill of materials (BOM)
125 components, 9 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 26 | TLE493d | TLE493d | U1, U2, U3, U4, U6, U7, U8, U9 +18 |
| 7 | TCA9546APWR | SOP65P640X120-16N | U5, U10, U15, U20, U25, U30, U35 |
| 1 | i2c | TE-Connectivity_Micro-Match_connector_02x02_Pitch_1.27mm | J1 |
| 1 | Conn_01x08_Female | micro_match_female_8pos_SMT | J2 |
| 1 | head | R1_face_mask_5.5mm | H5 |
| 1 | eyes | R1_eyes_mask_5.5mm | H6 |
| 1 | ears | R1_ear_silk_5.5mm | H7 |
| 26 | C | C_0402_1005Metric | C1, C2, C3, C4, C5, C6, C7, C8 +18 |
| 61 | 1k | R_0402_1005Metric | R1, R2, R3, R4, R5, R6, R7, R8 +53 |
Roboy 3.0 40mm magnetic field calibration design files
The KiCad project lives in the Roboy/ball_and_socket_estimator repository on GitHub; these links point at the commit this page was built from.
Roboy 3.0 40mm magnetic field calibration: common questions
How big is the Roboy 3.0 40mm magnetic field calibration PCB?
The Roboy 3.0 40mm magnetic field calibration measures 76.8 × 62.6 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Roboy 3.0 40mm magnetic field calibration?
125 components, from 9 distinct parts. The full bill of materials is listed on this page.
Where can I download the Roboy 3.0 40mm magnetic field calibration design files?
From the Roboy/ball_and_socket_estimator repository on GitHub, which has the KiCad layout; the links under Design files point to each one.
Can I use the Roboy 3.0 40mm magnetic field calibration design in my own project?
Yes, under the terms of its BSD-3-Clause license, which Roboy chose for the repository.