
Zenbot

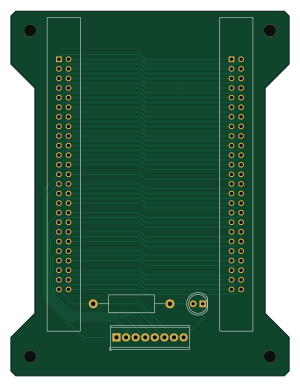
About the Zenbot PCB
Zenbot is an open source PCB design by SebKuzminsky, published on GitHub. It is a 2-layer board measuring 73.7 × 96.5 mm, with 5 components from 4 distinct parts.
By type, the board carries 3 connectors, 1 diode and 1 resistor.
It belongs with the dev boards & breakouts and robotics & motion designs in this gallery.
From the project
Configuration for "Zenbot", the SSD circuit mill
This is a breakout board for connecting the Zenbot to a Mesa FPGA board.
It connects to a standard 50-pin ribbon cable from the Mesa FPGA board.
It passes the servo pins for channels 0, 1, and 2 to a second 50-pin connector, for connecting to the 7i30 and driving the X, Y, and Z servos.
The remaining FPGA connector pins are routed to screw terminals, for additional IO (eg the control line for an SSR to power the spindle).
Zenbot bill of materials (BOM)
5 components, 4 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | Screw_Terminal_1x08 | TerminalBlock_Phoenix_MPT-0,5-8-2.54_1x08_P2.54mm_Horizontal | J1 |
| 2 | CONN_02X25 | TE-Connectivity_1-5499923-0 | P0, P1 |
| 1 | LED | LED_D5.0mm | D1 |
| 1 | 4.7k | R_Axial_DIN0414_L11.9mm_D4.5mm_P20.32mm_Horizontal | R1 |
Zenbot design files
The KiCad project lives in the SebKuzminsky/zenbot repository on GitHub; these links point at the commit this page was built from.
Zenbot: common questions
How big is the Zenbot PCB?
The Zenbot measures 73.7 × 96.5 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Zenbot?
5 components, from 4 distinct parts. The full bill of materials is listed on this page.
Where can I download the Zenbot design files?
From the SebKuzminsky/zenbot repository on GitHub, which has the KiCad layout; the links under Design files point to each one.
Can I use the Zenbot design in my own project?
The repository has no license, so all rights stay with SebKuzminsky. Use it as a reference, and ask the author before reusing the design.
Similar boards
Stack chan
stack-chan
50 × 50 mm33 parts2LApache-2.01.7k
134pin 7-967288-1
rusefi
139.7 × 73.7 mm38 parts2LGPL-3.01.2k
Eecv breakout
140.8 × 53.7 mm9 parts4LGPL-3.01.2k
88 Pin Vag Breakout
142 × 58 mm91 parts2LGPL-3.01.2k
Breakout 60pin EEC-IV
139.7 × 62.2 mm15 parts2LGPL-3.01.2k
Breakout 112pin Connector
174 × 58 mm39 parts2LGPL-3.01.2k