
Dengerobot

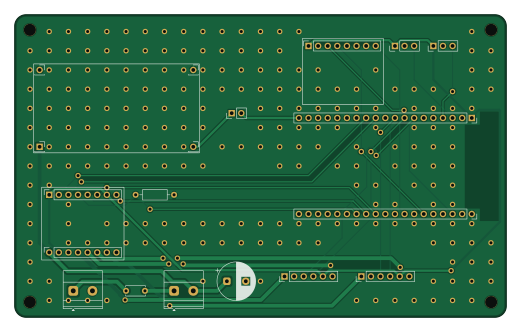
About the Dengerobot PCB
Dengerobot is an open source ESP32 PCB design by adakarda, published on GitHub. It is a 2-layer board measuring 130 × 80 mm, with 14 components from 14 distinct parts.
Its main chip is the ESP32-WROOM-32D DevKitC 38 pin, from the ESP32 family. Other key parts include the LM2596 mini 5,0 V (4 ped), GY-521 MPU6050 (1x8 soket) and TB6612FNG modul (2x8 soket). By type, the board carries 6 connectors, 2 ICs, 2 modules, 1 fuse, 1 jumper and 1 capacitor.
It belongs with the iot & wireless designs in this gallery, and the repository also holds 1 earlier revision of it.
From the project
YTÜ EEF ÇDTP 2026-27 Güz. Kontrol bölümünün işi (denge, hareket, istasyona yaklaşma) ve onun dokunduğu her şey: robot firmware'i, eldiven firmware'i, LQR tasarımı, fizik simülasyonu ve kabul testleri.
YTÜ EEF ÇDTP 2026-27 Güz. Kontrol bölümünün işi (denge, hareket, istasyona yaklaşma) ve onun dokunduğu her şey: robot firmware'i, eldiven firmware'i, LQR tasarımı, fizik simülasyonu ve kabul testleri.
Parça listesi ve takımın ortak şeması: . Buradaki pinler o şemayla aynıdır; farklar docs/ altındaki plan sayfasında "değişiklik önerisi" olarak işaretli.
Firmware: VS Code + PlatformIO eklentisi → firmware/robot (ya da firmware/glove) klasörünü açın → Upload. Kod yüklerken robotta JP1 köprüsünü çıkarın, eldivende SW1'i kapatın.
Main components on the Dengerobot
Dengerobot bill of materials (BOM)
14 components, 14 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | ESP32-WROOM-32D DevKitC 38 pin | ESP32_DevKitC_2x19_PinSocket_P2.54mm | U1 |
| 1 | LM2596 mini 5,0 V (4 ped) | LM2596_mini_4pad | U3 |
| 1 | GY-521 MPU6050 (1x8 soket) | PinSocket_1x08_P2.54mm_Vertical | A1 |
| 1 | TB6612FNG modul (2x8 soket) | TB6612_2x8_PinSocket_P2.54mm | A2 |
| 1 | 12V ADAPTOR GIRIS klemens | TerminalBlock_Phoenix_MKDS-1,5-2-5.08_1x02_P5.08mm_Horizontal | J1 |
| 1 | ANAHTAR klemens | TerminalBlock_Phoenix_MKDS-1,5-2-5.08_1x02_P5.08mm_Horizontal | J2 |
| 1 | SOL MOTOR 6 pin | PinHeader_1x06_P2.54mm_Vertical | J3 |
| 1 | SAG MOTOR 6 pin | PinHeader_1x06_P2.54mm_Vertical | J4 |
| 1 | IR SOL | PinHeader_1x03_P2.54mm_Vertical | J5 |
| 1 | IR SAG | PinHeader_1x03_P2.54mm_Vertical | J6 |
| 1 | PTC sigorta 3 A | C_Disc_D5.0mm_W2.5mm_P5.00mm | F1 |
| 1 | USB'de cikar | PinHeader_1x02_P2.54mm_Vertical | JP1 |
| 1 | 1000uF 25V | CP_Radial_D10.0mm_P5.00mm | C1 |
| 1 | 10k | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R1 |
Dengerobot design files
The KiCad project lives in the adakarda/dengerobot repository on GitHub; these links point at the commit this page was built from.
Dengerobot: common questions
What microcontroller does the Dengerobot use?
The Dengerobot is built around the ESP32-WROOM-32D DevKitC 38 pin, from the ESP32 family.
How big is the Dengerobot PCB?
The Dengerobot measures 130 × 80 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Dengerobot?
14 components, from 14 distinct parts. The full bill of materials is listed on this page.
Where can I download the Dengerobot design files?
From the adakarda/dengerobot repository on GitHub, which has the KiCad layout; the links under Design files point to each one.
Can I use the Dengerobot design in my own project?
The repository has no license, so all rights stay with adakarda. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the Dengerobot without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug ESP32 firmware against it before you order a PCB.
Earlier revisions in the repo: cdtp_ana_kart
Similar boards
 ESP32
OSO-BOOK-B1
joeycastillo
85 × 115 mm65 parts2LCC-BY-SA-4.08.1k ESP32
Powertrain
byrantech
64 × 45.4 mm171 parts4LMIT4.3k ESP32
Esp32 minimal
atopile
36.2 × 26.8 mm20 parts2LMIT4.0k ESP32
Badge
56.3 × 39 mm239 parts4LMIT4.0k ESP32
Racer
StuckAtPrototype
36 × 50.2 mm70 parts4LApache-2.03.8k ESP32
Controller
29 × 74 mm58 parts4LApache-2.03.8k