
Mecanum robot board

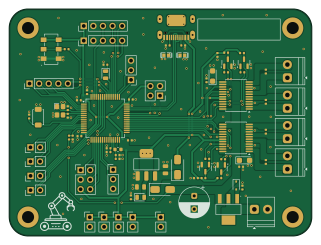
About the Mecanum robot board
Mecanum robot board is an open source STM32 PCB design by adammat02, published on GitHub. It is a 2-layer board measuring 80 × 60 mm, with 83 components from 49 distinct parts.
Its main chip is the STM32G474RETX, from the STM32 family. Other key parts include the AMS1117 and TB6612FNG. By type, the board carries 25 capacitors, 22 connectors, 16 resistors, 7 diodes, 5 transistors and 4 ICs.
It belongs with the robotics & motion, power & battery and sensors designs in this gallery.
From the project
A compact STM32-based controller board for a four-wheel mecanum robot. It drives four DC gear motors with quadrature-encoder feedback, reads two time-of-flight distance sensors, and breaks out the common serial buses - all powered directly from a 2S-3S Li-ion / LiPo battery.
A compact STM32-based controller board for a four-wheel mecanum robot. It drives four DC gear motors with quadrature-encoder feedback, reads two time-of-flight distance sensors, and breaks out the common serial buses - all powered directly from a 2S-3S Li-ion / LiPo battery.
The board integrates everything needed to control a mecanum-wheel platform on a single PCB: an STM32G4 microcontroller, two dual H-bridge motor drivers, on-board reverse-polarity protection, a USB-C interface, and headers for sensors and expansion. It is designed around parts available from JLCPCB / LCSC so it can be…
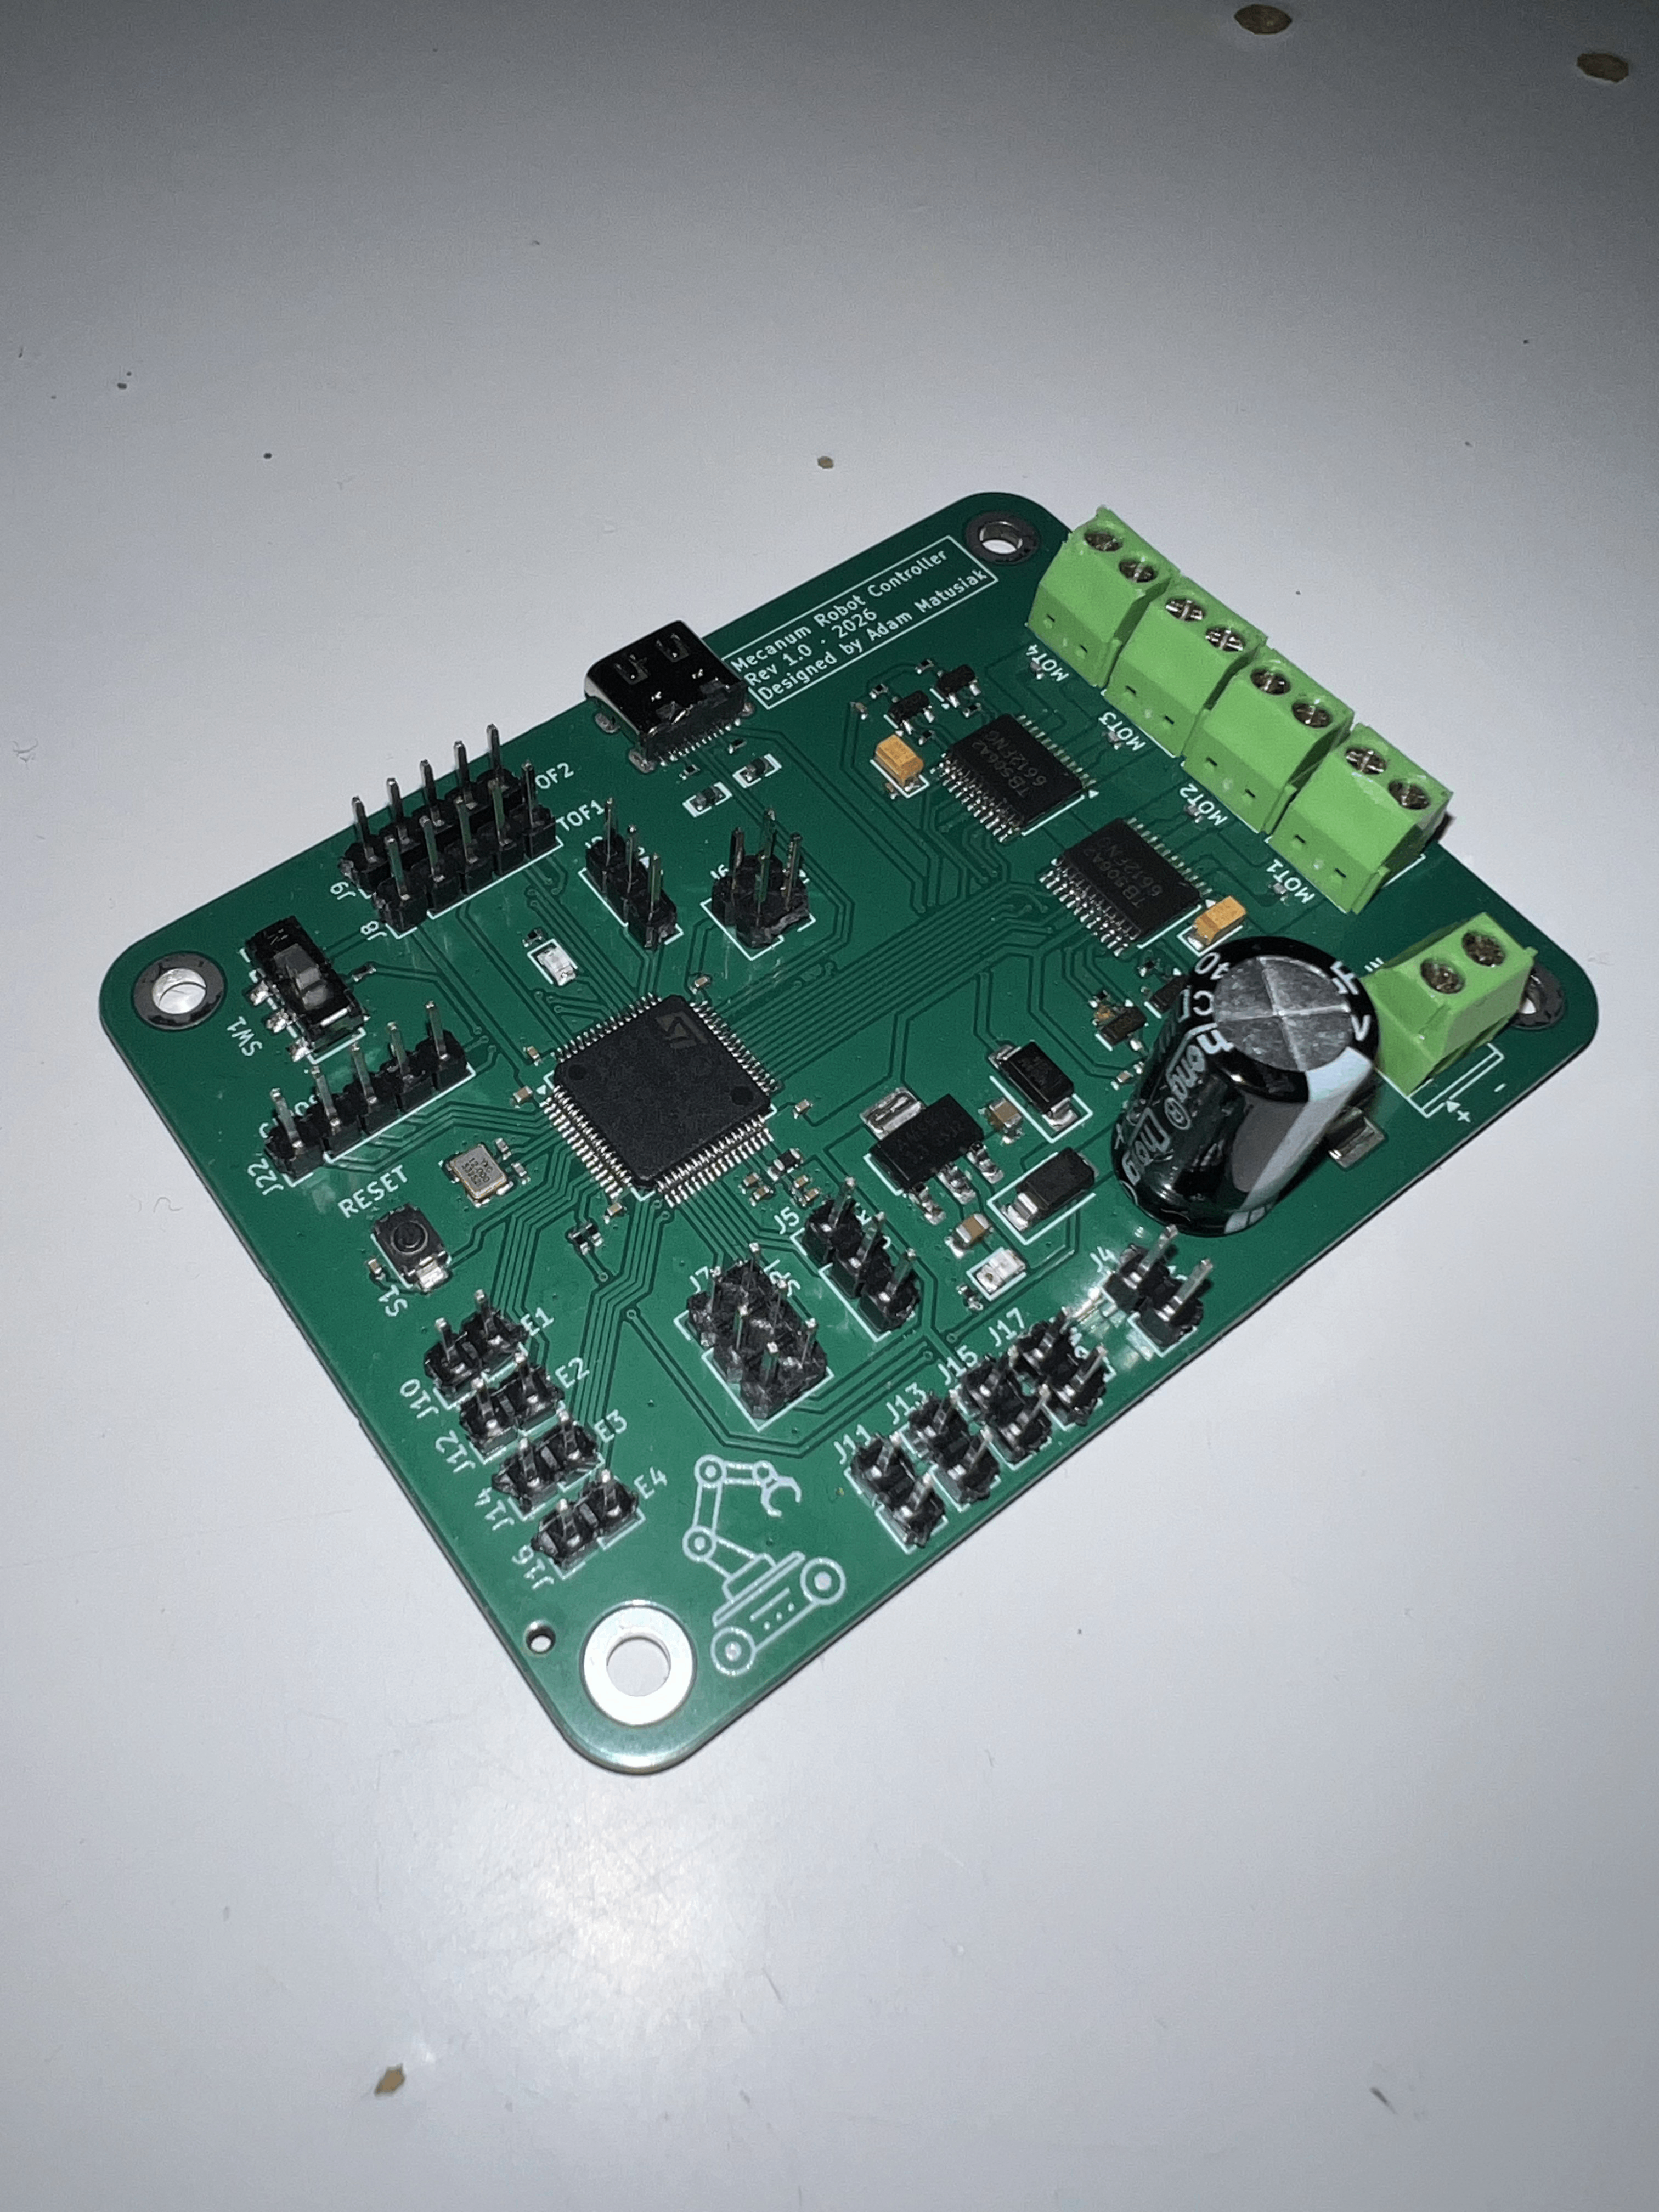
Main components on the Mecanum robot board
Mecanum robot board bill of materials (BOM)
83 components, 49 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | AMS1117 Advanced Monolithic Systems | SOT-223-3_L6.5-W3.4-P2.30-LS7.0-BR | U1 |
| 1 | STM32G474RETX STM32G474RETx | LQFP-64_10x10mm_P0.5mm | U2 |
| 2 | TB6612FNG | SSOP-24_5.3x8.2mm_P0.65mm | U3, U4 |
| 4 | 2N7002 Changjiang Electronics Tech (CJ) | Q_SOT-23 | Q1, Q2, Q3, Q4 |
| 1 | NTF6P02T3G PMOS onsemi(安森美) | SOT-223-4_L6.5-W3.5-P2.30-LS7.0-BR | Q5 |
| 1 | X322512MSB4SI Yangxing Tech | CRYSTAL-SMD_4P-L3.2-W2.5-BL | X1 |
| 1 | C2927039 Connector, USB-TYPE-C-16P | TYPE-C-SMD_HX-TYPE-C-16PIN | J1 |
| 1 | SWD | PinHeader_1x03_P2.54mm_Vertical | J2 |
| 1 | PWR_IN | TerminalBlock_Phoenix_PT-1,5-2-3.5-H_1x02_P3.50mm_Horizontal | J3 |
| 1 | 3V3_OUT | PinHeader_1x02_P2.54mm_Vertical | J4 |
| 1 | UART | PinHeader_1x03_P2.54mm_Vertical | J5 |
| 1 | I2C | PinHeader_2x02_P2.54mm_Vertical | J6 |
| 1 | SPI | PinHeader_2x03_P2.54mm_Vertical | J7 |
| 1 | TOF1 | PinHeader_1x05_P2.54mm_Vertical | J8 |
| 1 | TOF2 | PinHeader_1x05_P2.54mm_Vertical | J9 |
| 1 | ENKODER1 | PinHeader_1x02_P2.54mm_Vertical | J10 |
| 1 | ENKODER1_PWR | PinHeader_1x02_P2.54mm_Vertical | J11 |
| 1 | ENKODER2 | PinHeader_1x02_P2.54mm_Vertical | J12 |
| 1 | ENKODER2_PWR | PinHeader_1x02_P2.54mm_Vertical | J13 |
| 1 | ENKODER3 | PinHeader_1x02_P2.54mm_Vertical | J14 |
Show 29 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | ENKODER3_PWR | PinHeader_1x02_P2.54mm_Vertical | J15 |
| 1 | ENKODER4 | PinHeader_1x02_P2.54mm_Vertical | J16 |
| 1 | ENKODER4_PWR | PinHeader_1x02_P2.54mm_Vertical | J17 |
| 1 | MOTOR1 | TerminalBlock_Phoenix_PT-1,5-2-3.5-H_1x02_P3.50mm_Horizontal | J18 |
| 1 | MOTOR2 | TerminalBlock_Phoenix_PT-1,5-2-3.5-H_1x02_P3.50mm_Horizontal | J19 |
| 1 | MOTOR3 | TerminalBlock_Phoenix_PT-1,5-2-3.5-H_1x02_P3.50mm_Horizontal | J20 |
| 1 | MOTOR4 | TerminalBlock_Phoenix_PT-1,5-2-3.5-H_1x02_P3.50mm_Horizontal | J21 |
| 1 | GPIOS | PinHeader_1x05_P2.54mm_Vertical | J22 |
| 1 | C720477 RESET XUNPU | SW_TS-1088-AR02016 | S1 |
| 1 | SSSS213202 BOOT ALPSALPINE(阿尔卑斯阿尔派) | SW-TH_SSSS213202 | SW1 |
| 2 | SS14 MDD(Microdiode Electronics) | D_SMA | D1, D2 |
| 1 | C84256 Red Foshan NationStar Optoelectronics | D_0805 | D3 |
| 2 | 0603ESDA-05N BORN(伯恩半导体) | D0603-BI | D4, D5 |
| 1 | C2297 Green Hubei KENTO Elec | D_0805 | D6 |
| 1 | BZT52B5V1S hongjiacheng | D_SOD-323 | D7 |
| 1 | C1002 ~ Sunlord | FB_0603 | FB1 |
| 2 | 22UF 22uF Samsung Electro-Mechanics | C_0805 | C1, C2 |
| 11 | 100NF 100nF Samsung Electro-Mechanics | C_0402 | C3, C4, C5, C6, C9, C10, C12, C16 +3 |
| 1 | 10UF 10uF Samsung Electro-Mechanics | C_0402 | C7 |
| 2 | 1UF 1uF Samsung Electro-Mechanics | C_0402 | C8, C11 |
| 6 | 33PF 33pF FH(Guangdong Fenghua Advanced Tech) | C_0402 | C13, C14, C19, C20, C24, C25 |
| 1 | 470UF 470uF | CP_Radial_D8.0mm_P3.50mm | C15 |
| 2 | 10UF 10uF AVX | C_CASE-A-3216-18(mm) | C18, C23 |
| 2 | 220Ω UNI-ROYAL(Uniroyal Elec) | R_0402 | R1, R5 |
| 2 | 5.1kΩ UNI-ROYAL(Uniroyal Elec) | R_0402 | R2, R3 |
| 6 | 10kΩ UNI-ROYAL(Uniroyal Elec) | R_0402 | R4, R6, R9, R10, R13, R16 |
| 4 | 1kΩ UNI-ROYAL(Uniroyal Elec) | R_0402 | R7, R8, R11, R12 |
| 1 | 100kΩ UNI-ROYAL(Uniroyal Elec) | R_0402 | R14 |
| 1 | 33kΩ UNI-ROYAL(Uniroyal Elec) | R_0402 | R15 |
Mecanum robot board design files
The KiCad project lives in the adammat02/mecanum_robot_board repository on GitHub; these links point at the commit this page was built from.
Mecanum robot board: common questions
What microcontroller does the Mecanum robot board use?
The Mecanum robot board is built around the STM32G474RETX, from the STM32 family.
How big is the Mecanum robot board?
The Mecanum robot board measures 80 × 60 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Mecanum robot board?
83 components, from 49 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Mecanum robot board design files?
From the adammat02/mecanum_robot_board repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the Mecanum robot board design in my own project?
The repository has no license, so all rights stay with adammat02. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the Mecanum robot board without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug STM32 firmware against it before you order a PCB.
Similar boards
 STM32
LumenPnP Motherboard
opulo-inc
149 × 95 mm296 parts4LCC-BY-SA-4.03.7k STM32
AxxSolder
AxxAxx
39 × 82.5 mm122 parts2LGPL-3.01.7k STM32
AIOC
skuep
21 × 31.5 mm47 parts2LMIT1.4k STM32
Ferris
pierrechevalier83
208.8 × 86.8 mm102 parts2LSHL-2.11.3k STM32
176 pin board
rusefi
61.8 × 73.2 mm76 parts2LGPL-3.01.2k STM32
Brain board STM32F407
61.8 × 73.2 mm69 parts2LGPL-3.01.2k