
BalanceBot

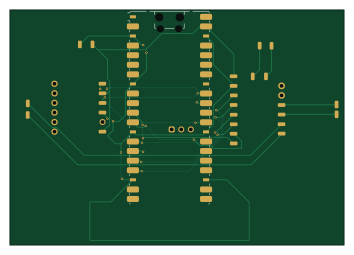
About the BalanceBot PCB
BalanceBot is an open source Raspberry Pi PCB design by BigBrain244466666, published on GitHub. It is a 2-layer board measuring 88.5 × 62.2 mm, with 3 components from 3 distinct parts.
Its main chip is the RaspberryPi_Pico_W, from the Raspberry Pi family. By type, the board carries 2 jumpers and 1 module.
It belongs with the robotics & motion designs in this gallery.
From the project
Making a self balancing robot
Description: This is a robot that can autonomously balance on two wheels while being controlled with regular movements (forward, backward, left, right) via Bluetooth on a computer.
Why I did this project: I found this project online when searching for good robotics challenges. It sounded fun because I had just seen things like hoverboards (those two-wheel boards that you can ride on) and thought it would be cool if I could make a miniature version of them. Of course, the design isn't the same, but it's the same concept.
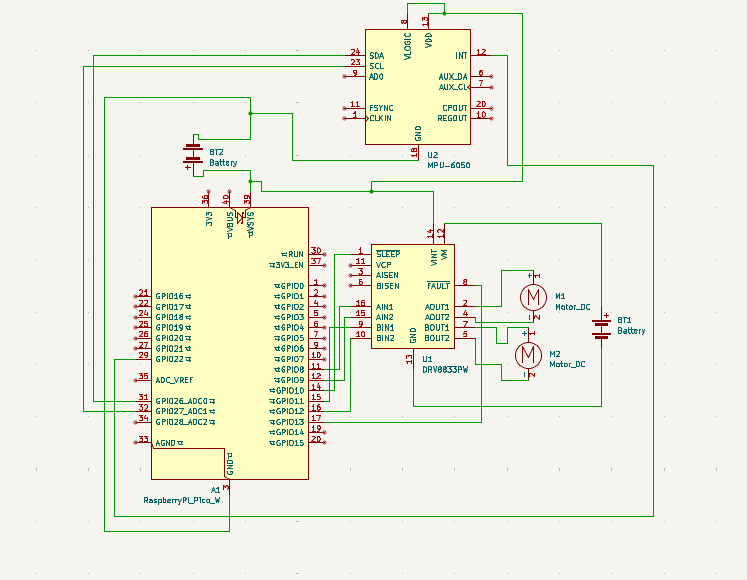
Main components on the BalanceBot
BalanceBot bill of materials (BOM)
3 components, 3 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | RaspberryPi_Pico_W | RaspberryPi_Pico_W_SMD_HandSolder | A1 |
| 1 | — | 1X06_ROUND | JP2 |
| 1 | — | 1X02_ROUND | JP4 |
BalanceBot design files
The KiCad project lives in the BigBrain244466666/BalanceBot repository on GitHub; these links point at the commit this page was built from.
- LayoutPCB/Balance Bot.kicad_pcb
- BOMBOM.csv
BalanceBot: common questions
What microcontroller does the BalanceBot use?
The BalanceBot is built around the RaspberryPi_Pico_W, from the Raspberry Pi family.
How big is the BalanceBot PCB?
The BalanceBot measures 88.5 × 62.2 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the BalanceBot?
3 components, from 3 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the BalanceBot design files?
From the BigBrain244466666/BalanceBot repository on GitHub, which has the KiCad layout and the BOM; the links under Design files point to each one.
Can I use the BalanceBot design in my own project?
The repository has no license, so all rights stay with BigBrain244466666. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the BalanceBot without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug Raspberry Pi firmware against it before you order a PCB.
Similar boards
 Raspberry Pi
Open source rover
nasa-jpl
220 × 178 mm144 parts2LApache-2.09.7k Raspberry Pi
Iot
dotnet
56 × 65 mm24 parts2LMIT2.4k Raspberry Pi
SPIRIT
SPIRIT-org
82 × 155 mm130 parts6LCERN-OHL-S-2.01.3k Raspberry Pi
CM5RevEng
schlae
55 × 40 mm417 parts10LNo license1.0k Raspberry Pi
Haxo hw
cardonabits
102.4 × 211.3 mm38 parts2LCustom license672 Raspberry Pi
Phased
Neumi
75 × 100 mm71 parts2LNo license507