
Exoskeleton

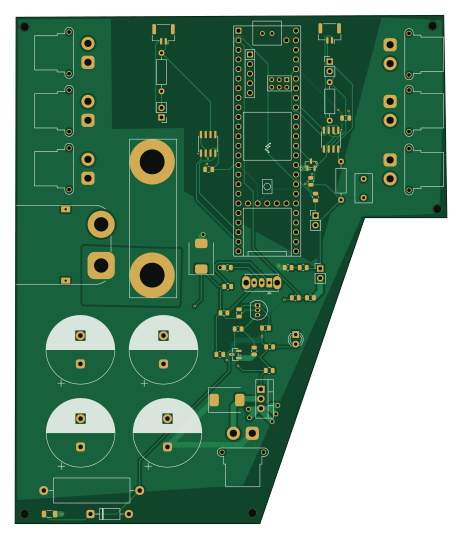
About the Exoskeleton PCB
Exoskeleton is an open source NXP PCB design by Bihyungbetter, published on GitHub. It is a 4-layer board measuring 114.3 × 134.5 mm, with 55 components from 42 distinct parts.
Its main chip is the TEENSY4.1, from the NXP family. Other key parts include the SN65HVD230 and TL431LP. By type, the board carries 19 resistors, 13 connectors, 9 capacitors, 5 diodes, 4 ICs and 2 transistors.
From the project
Exoskeleton is a powered lower-limb exoskeleton with six actuated joints — hip flexion, hip abduction, and knee flexion per leg. Each joint is driven by a CubeMars AK-series actuator (AK70-10 / AK80-64) commanded over CAN by a Teensy 4.1 running through a custom dual-CAN power di
Exoskeleton is a powered lower-limb exoskeleton with six actuated joints — hip flexion, hip abduction, and knee flexion per leg. Each joint is driven by a CubeMars AK-series actuator (AK70-10 / AK80-64) commanded over CAN by a Teensy 4.1 running through a custom dual-CAN power distribution board, which supplies six independent motor power outputs. The frame — waist, hip abductors, hip-to-thigh, thigh-to-knee, and knee-to-shank sections — is designed in SolidWorks; the electronics are designed in KiCad.
Main components on the Exoskeleton
Exoskeleton bill of materials (BOM)
55 components, 42 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | TEENSY4.1 Teensy4.1 | Teensy41 | U1 |
| 2 | SN65HVD230 | SOIC-8_3.9x4.9mm_P1.27mm | U2, U4 |
| 1 | TL431LP | TO-92_Inline | U3 |
| 1 | MMBT3906 | SOT-23 | Q1 |
| 1 | IRFB4110 | TO-220-3_Vertical | Q2 |
| 1 | TERM | PinHeader_1x02_P2.54mm_Vertical | J2 |
| 1 | PWR M1 | AMASS_XT30PW-F_1x02_P2.50mm_Horizontal | J3 |
| 1 | CANA | JST_GH_SM02B-GHS-TB_1x02-1MP_P1.25mm_Horizontal | J4 |
| 1 | PWR M2 | AMASS_XT30PW-F_1x02_P2.50mm_Horizontal | J5 |
| 1 | CANB | JST_GH_SM02B-GHS-TB_1x02-1MP_P1.25mm_Horizontal | J6 |
| 1 | PWR M3 | AMASS_XT30PW-F_1x02_P2.50mm_Horizontal | J7 |
| 1 | PWR M4 | AMASS_XT30PW-F_1x02_P2.50mm_Horizontal | J9 |
| 1 | PWR M5 | AMASS_XT30PW-F_1x02_P2.50mm_Horizontal | J11 |
| 1 | PWR M6 | AMASS_XT30PW-F_1x02_P2.50mm_Horizontal | J13 |
| 1 | TERM2 | PinHeader_1x02_P2.54mm_Vertical | J15 |
| 1 | BATT_SENSE | PinHeader_1x02_P2.54mm_Vertical | J16 |
| 1 | DUMP_RESISTOR | AMASS_XT30PW-F_1x02_P2.50mm_Horizontal | J17 |
| 1 | THERMAL_SW | PinHeader_1x02_P2.54mm_Vertical | J19 |
| 1 | BF1 58V MIDI 50A (142.7010.5502) | Fuse_MIDI_BF1-58V_50A_BoltDown_2xM6_P30mm | F1 |
| 1 | SW_SPDT | SW_Slide_SPDT_Straight_CK_OS102011MS2Q | SW1 |
Show 22 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | Conn_01x02_Pin | AMASS_XT90PW-M_1x02_P10.90mm_Horizontal | XT90PWRIN1 |
| 1 | SMCJ58CA | D_SMC | D1 |
| 1 | BAT54S | SOT-23 | D2 |
| 1 | BZX85C12 | D_DO-41_SOD81_P10.16mm_Horizontal | D3 |
| 1 | CHOP_ACTIVE | LED_D3.0mm | D4 |
| 1 | ES3D | D_SMC | D5 |
| 4 | 680uF 100V | CP_Radial_D18.0mm_P7.50mm | C1, C2, C3, C4 |
| 1 | 100NF 100nF | C_Disc_D7.5mm_W4.4mm_P5.00mm | C5 |
| 2 | 100NF 100nF | C_0805_2012Metric | C6, C9 |
| 1 | 10uF 25V | C_1206_3216Metric | C7 |
| 1 | 10NF 10nF | C_0805_2012Metric | C8 |
| 2 | 120R | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R1, R5 |
| 6 | 10K | R_0805_2012Metric | R2, R6, R13, R16, R17, R20 |
| 1 | 1K | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R3 |
| 2 | 4.7K | R_0805_2012Metric | R7, R10 |
| 1 | 1K 3W | R_Axial_Power_L20.0mm_W6.4mm_P25.40mm | R8 |
| 2 | 100K | R_0805_2012Metric | R9, R18 |
| 1 | 5.1K | R_0805_2012Metric | R11 |
| 1 | 1K | R_0805_2012Metric | R12 |
| 1 | 1M | R_0805_2012Metric | R14 |
| 1 | 100 | R_0805_2012Metric | R15 |
| 1 | 33K | R_0805_2012Metric | R19 |
Exoskeleton design files
The KiCad project lives in the Bihyungbetter/exoskeleton repository on GitHub; these links point at the commit this page was built from.
- Layoutpcb/Exoskeleton.kicad_pcb
- Schematicpcb/Exoskeleton.kicad_sch
- BOMpcb/production/bom.csv
Exoskeleton: common questions
What microcontroller does the Exoskeleton use?
The Exoskeleton is built around the TEENSY4.1, from the NXP family.
How big is the Exoskeleton PCB?
The Exoskeleton measures 114.3 × 134.5 mm, has 4 copper layers and is 1.67 mm thick.
How many components are on the Exoskeleton?
55 components, from 42 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Exoskeleton design files?
From the Bihyungbetter/exoskeleton repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the Exoskeleton design in my own project?
The repository has no license, so all rights stay with Bihyungbetter. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the Exoskeleton without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug NXP firmware against it before you order a PCB.
Similar boards
 NXP
Mega-Cube-Board
MaltWhiskey
200 × 54 mm100 parts4LNo license763 NXP
32Bit shift register
100 × 54 mm56 parts4LNo license763 NXP
IC60
kiibohd
285 × 95 mm242 partsCERN-OHL-1.2415 NXP
ICED-R
175.4 × 145 mm163 partsCERN-OHL-1.2415 NXP
Testcontroller
145.8 × 42.9 mm45 parts2LCERN-OHL-1.2415 NXP
ICED-L
175.4 × 145 mm163 partsCERN-OHL-1.2415