
Encoder

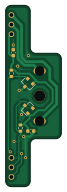
About the Encoder PCB
Encoder is an open source PCB design by hbrobotics, published on GitHub. It is a 2-layer board measuring 14.8 × 48 mm, with 7 components from 4 distinct parts.
By type, the board carries 2 transistors, 2 capacitors, 2 resistors and 1 connector.
It belongs with the robotics & motion designs in this gallery.
From the project
HomeBrew Robotics Club Robot Platform
The HR2 Encoder deals with the geometry constraints of a the Robot Computer (i.e. Raspberry Pi 4) mounted on the Pololu Romi Base. There is only one way to mount the Raspberry Pi processor on the Romi. This means that the standard Pololu Romi encoders will not work. Thus new encoders are needed. These encoder boards are soldered to the motor and have 2 male 1x3 right angle connectors that plug into 2 associated female 1x3 receptacles on the master board. The connectors are to the side of each motor.
Encoder bill of materials (BOM)
7 components, 4 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 2 | DRV5013FAQDBZR;SOT23 | SOT-23 | Q1, Q2 |
| 1 | ENCODER_FIX;2xM1x3RA | ENCODER_2xM1x3RA | CN1 |
| 2 | 10nF;1608 | C_0603_1608Metric | C1, C2 |
| 2 | 47KΩ;1608 | R_0603_1608Metric | R1, R2 |
Encoder design files
The KiCad project lives in the hbrobotics/hbrc_ros_robot_platform repository on GitHub; these links point at the commit this page was built from.
Encoder: common questions
How big is the Encoder PCB?
The Encoder measures 14.8 × 48 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Encoder?
7 components, from 4 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Encoder design files?
From the hbrobotics/hbrc_ros_robot_platform repository on GitHub, which has the KiCad layout and the BOM; the links under Design files point to each one.
Can I use the Encoder design in my own project?
The repository has no license, so all rights stay with hbrobotics. Use it as a reference, and ask the author before reusing the design.
More boards in hbrc_ros_robot_platform

Similar boards
Stack chan
stack-chan
50 × 50 mm33 parts2LApache-2.01.7k
Cube batteryboard
willem-pennings
95 × 95 mm4 parts2LGPL-3.01.1k
Mesabob
rene-dev
87.5 × 50 mm44 parts2LGPL-3.0979
Bob
100 × 100 mm140 parts2LGPL-3.0979
Triple adapter
57 × 75 mm26 parts2LGPL-3.0979
Trollerv2
100 × 75 mm33 parts4LGPL-3.0979