
HR2 Master Board


About the HR2 Master Board
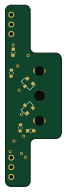
HR2 Master Board is an open source PCB design by hbrobotics, published on GitHub. It is a 4-layer board measuring 22 × 6 mm, with 203 components from 67 distinct parts.
Other key parts include the C55266, C7440, C81193, C50506 and C5948. By type, the board carries 61 resistors, 30 connectors, 25 transistors, 23 capacitors, 22 ICs and 22 diodes.
It belongs with the robotics & motion designs in this gallery.
From the project
HomeBrew Robotics Club Robot Platform
This is the common design information that is pretty applicable across all revisions of the HR2 Master PCB Board. The intention is to always use a higher end STM Nucleo-144 development board as the embedded microcontroller. This also allows processor upgrades to occur when newer Nucleo-144 boards come out by simply upgrading to a newer Nucleo-144 board. The higher end chips in the STM32Fxxx series of processors try to maintain peripheral pin mappings across all versions of the 144-LQFP (144 pin Low profile Quad Flat Package.) Time will tell how good ST Microelectronics is at adhering to this…
Main components on the HR2 Master Board
HR2 Master Board bill of materials (BOM)
203 components, 67 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 3 | C55266 LM5050-1;TSOT-23-6 | TSOT-23-6 | U1, U2, U3 |
| 1 | C7440 MCP7940;SOIC8 | SOIC-8_3.9x4.9mm_P1.27mm | U4 |
| 1 | C81193 CAT24C32;SOIC8 | SOIC-8_3.9x4.9mm_P1.27mm | U5 |
| 1 | C50506 DRV8833PWPR;HTSSOP16EP3.4x5 | HTSSOP-16-1EP_4.4x5mm_P0.65mm_EP3.4x5mm_Mask3x3mm_ThermalVias | U6 |
| 4 | C5948 SN74HC595;TSSOP16 | TSSOP-16_4.4x5mm_P0.65mm | U7, U8, U9, U13 |
| 2 | C233582 CD4504B;TTSOP16 | TSSOP-16_4.4x5mm_P0.65mm | U10, U11 |
| 1 | C10681 ACS711;SOIC8 | SOIC-8_3.9x4.9mm_P1.27mm | U12 |
| 2 | C201716 SN74HC165;TSSOP16 | TSSOP-16_4.4x5mm_P0.65mm | U14, U15 |
| 2 | 74x11G1;TSOP6 | TSOP-6_1.65x3.05mm_P0.95mm | U16, U17 |
| 2 | MCP2542;SOIC8 | SOIC-8_3.9x4.9mm_P1.27mm | U18, U19 |
| 1 | 74LVC1G74;TSSOP8 | TSSOP-8_3x3mm_P0.65mm | U20 |
| 2 | C261926 CPC1017N;SOP4W3.8L4.1 | SOP-4_3.8x4.1mm_P2.54mm | U21, U22 |
| 3 | C20917 NFET_3A_GSD;SOT23 | SOT-23 | Q1, Q2, Q3 |
| 20 | C8545 2N7002;SOT23 | SOT-23 | Q4, Q6, Q7, Q8, Q9, Q10, Q11, Q12 +12 |
| 2 | C141546 PFET_6A_GSD;SOT23 | SOT-23 | Q5, Q24 |
| 1 | C32346 32.768kHz12.5pF;3.2x1.5 | Crystal_SMD_3215-2Pin_3.2x1.5mm | X1 |
| 1 | USB-C;USB-C,POGND | USB_C_Receptacle_JAE_DX07S024WJ3R400 | CN1 |
| 1 | USB-C;USB-C | USB_C_Receptacle_JAE_DX07S024WJ3R400 | CN2 |
| 1 | POLOLU_U3V70F9;F1x4+F1x5 | U3V70xMATE_F1x4+F1x5 | CN3 |
| 1 | RPI_DSP_PWR;M1x2 | PinHeader_1x02_P2.54mm_Vertical | CN4 |
Show 47 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | RASPI;F2X20 | RASPI_F2X20 | CN5 |
| 2 | HR2_ENCODER;2xF1x3 | ENCODER_2xF1x3 | CN6, CN7 |
| 1 | STADAPTER;F2x4 | STADAPTER_F2x4 | CN8 |
| 2 | HCSR04LP;F1X4 | HCSR04_F1x4H | CN9, CN10 |
| 2 | HCSR04LP;F1X4 | HCSR04_F1x4 | CN11, CN19 |
| 3 | HCSR04LP;F1X4 | HCSR04_F1x4LP | CN12, CN14, CN16 |
| 3 | SERVO;M1x3 | PinHeader_1x03_P2.54mm_Vertical | CN13, CN15, CN17 |
| 1 | SERVO;M1x4 | PinHeader_1x04_P2.54mm_Vertical | CN18 |
| 1 | NUCLEO-F767ZI;2xF2x35 | NUCLEO_F767ZI_2xF2x35 | CN20 |
| 1 | LIDAR_ADAPTER;2xF1x4_F1x3 | LIDAR_ADAPTER_2xF1x4_F1x3 | CN21 |
| 8 | SENSE;M1x3 | PinHeader_1x03_P2.54mm_Vertical | CN22, CN23, CN24, CN25, CN26, CN27, CN28, CN29 |
| 1 | WOW_OUT;M2x6S | PinHeader_2x06_P2.54mm_Vertical_Shrouded | CN30 |
| 1 | COIN_HOLDER6.8R;TE1376164-1 | TE1376164-1_COINHOLDER6.8 | BT1 |
| 5 | GROVE;20x20 | GROVE20x20 | GV1, GV2, GV3, GV4, GV5 |
| 2 | LED_EN;M1x3 | PinHeader_1x03_P2.54mm_Vertical | JP1, JP8 |
| 5 | SHUNT;M1x2 | PinHeader_1x02_P2.54mm_Vertical | JP2, JP3, JP4, JP5, JP10 |
| 1 | RPI_DISP_EN;M1x3 | PinHeader_1x03_P2.54mm_Vertical | JP6 |
| 1 | JUMPER;M1x2 | PinHeader_1x02_P2.54mm_Vertical | JP7 |
| 1 | EXT_ESTOP;M1x2 | PinHeader_1x02_P2.54mm_Vertical | JP9 |
| 2 | C127509 BUTTON;6x6 | SW_Push_1P1T_NO_6x6mm_H9.5mm | SW1, SW2 |
| 1 | C6186 AMS1117-3.3V800mA_GOI;SOT223 | SOT-223-3_TabPin2 | VR1 |
| 5 | C72043 LEDGRN;1608 | LED_0603_1608Metric | D1, D2, D3, D4, D5 |
| 16 | LED;GRNRA | LED_GRNRA | D6, D7, D8, D9, D10, D11, D12, D13 +8 |
| 1 | C2286 REDLED;1608 | LED_0603_1608Metric | D22 |
| 1 | C135574 Ta22µF6.3V;3216 | C_1206_3216Metric | C1 |
| 2 | 470µF,25Vmin;D10P5H13max | CP_Radial_D10.0mm_P5.00mm | C2, C4 |
| 1 | 1000µF@10Vmin;D10P5H13max | CP_Radial_D10.0mm_P5.00mm | C3 |
| 2 | C1644 15pF;1608 | C_0603_1608Metric | C5, C7 |
| 14 | C1525 0.1µF;1005 | C_0402_1005Metric | C6, C8, C11, C12, C13, C14, C15, C17 +6 |
| 1 | C19702 10µF;1608 | C_0603_1608Metric | C9 |
| 1 | C23630 2.2µF6.3V;1608 | C_0603_1608Metric | C10 |
| 1 | C15195 0.01µF;1005 | C_0402_1005Metric | C16 |
| 4 | C25744 10KΩ;1005 | R_0402_1005Metric | R1, R2, R3, R4 |
| 2 | C25105 33Ω;1005 | R_0402_1005Metric | R5, R20 |
| 2 | C25091 220Ω;1005 | R_0402_1005Metric | R6, R8 |
| 1 | C23204 560Ω;1608 | R_0603_1608Metric | R7 |
| 5 | C17888 0Ω;3216 | R_1206_3216Metric | R9, R10, R11, R12, R56 |
| 1 | C25803 100KΩ;1608 | R_0603_1608Metric | R13 |
| 19 | C25741 100KΩ;1005 | R_0402_1005Metric | R14, R15, R16, R18, R19, R21, R22, R23 +11 |
| 2 | C11702 1KΩ;1005 | R_0402_1005Metric | R17, R44 |
| 2 | C34388 .16Ω.25W;2012 | R_0805_2012Metric | R25, R26 |
| 16 | C22966 270Ω;1608 | R_0603_1608Metric | R27, R28, R29, R30, R31, R32, R33, R34 +8 |
| 1 | C25879 2.2KΩ;1005 | R_0402_1005Metric | R45 |
| 1 | C25890 3.3KΩ;1005 | R_0402_1005Metric | R46 |
| 1 | C25079 120Ω;1005 | R_0402_1005Metric | R57 |
| 2 | C17909 120Ω.25W;3216 | R_1206_3216Metric | R58, R59 |
| 2 | C23025 300Ω;1608 | R_0603_1608Metric | R60, R61 |
HR2 Master Board design files
The KiCad project lives in the hbrobotics/hbrc_ros_robot_platform repository on GitHub; these links point at the commit this page was built from.
HR2 Master Board: common questions
How big is the HR2 Master Board?
The HR2 Master Board measures 22 × 6 mm, has 4 copper layers and is 1.6 mm thick.
How many components are on the HR2 Master Board?
203 components, from 67 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the HR2 Master Board design files?
From the hbrobotics/hbrc_ros_robot_platform repository on GitHub, which has the KiCad layout and the BOM; the links under Design files point to each one.
Can I use the HR2 Master Board design in my own project?
The repository has no license, so all rights stay with hbrobotics. Use it as a reference, and ask the author before reusing the design.
More boards in hbrc_ros_robot_platform
Similar boards
Stack chan
stack-chan
50 × 50 mm33 parts2LApache-2.01.7k
Cube batteryboard
willem-pennings
95 × 95 mm4 parts2LGPL-3.01.1k
Mesabob
rene-dev
87.5 × 50 mm44 parts2LGPL-3.0979
Bob
100 × 100 mm140 parts2LGPL-3.0979
Triple adapter
57 × 75 mm26 parts2LGPL-3.0979
Trollerv2
100 × 75 mm33 parts4LGPL-3.0979