
TelepresenceRobot

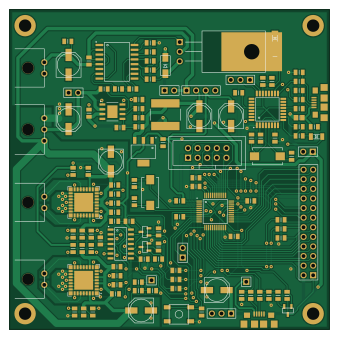
About the TelepresenceRobot PCB
TelepresenceRobot is an open source STM32 PCB design by joeferner, published on GitHub. It is a 2-layer board measuring 84.6 × 84.6 mm, with 133 components from 63 distinct parts.
Its main chip is the STM32F102C6, from the STM32 family. Other key parts include the BQ24450, ZLDO1117, AP6502, 7408 and MC33926. By type, the board carries 46 capacitors, 44 resistors, 17 connectors, 8 ICs, 4 modules and 4 transistors.
It belongs with the robotics & motion designs in this gallery.
From the project
Telepresence Robot
After seeing a commercial for a Telepresence robot on TV, I knew I wanted to play with one, but after looking at prices I didn't want to pay for one.
I used an Android Nexus 7 tablet for the video conferencing. A custom PCB with an STM32 ARM processor and an FTDI USB chip to connect the Android tablet with the motors.
Main components on the TelepresenceRobot
TelepresenceRobot bill of materials (BOM)
133 components, 63 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | STM32F102C6 | QFP50P900X900X160-48N | U1 |
| 1 | BQ24450 | SOIC127P1030X265-16N | U2 |
| 1 | ZLDO1117 | SOT230P700X180-4N | U3 |
| 1 | AP6502 | SOIC127P600X150-9N | U4 |
| 1 | 7408 | SOIC127P600X175-14N | U5 |
| 2 | MC33926 | PQFN80P800X800X220-33N | U6, U7 |
| 1 | FT312D | QFP80P900X900X160-32N | U8 |
| 4 | Mounting Hole | MTGNP565H328Z565P | M1, M2, M3, M4 |
| 1 | ZXMP2120FFTA | SOT95P237X112_123-3N | Q1 |
| 1 | BD242CG | TO254P1512X997X450-231-3P | Q2 |
| 2 | IRLML2803TRPBF | SOT95P237X112_123-3N | Q3, Q4 |
| 1 | 8MHz | XTAL8045X200N | X1 |
| 1 | 12MHz | XTAL8045X200N | X2 |
| 1 | USB_DEBUG | JST_UB-MC5BR3-SD204-4S-NMP | J1 |
| 1 | USB_TO_ANDROID | JST_UB-MC5BR3-SD204-4S-NMP | J2 |
| 1 | VBAT-TEST | HDRV1W66P254_1X1_254X249X838P | P1 |
| 1 | USB-VBUS | HDRV1W66P254_1X1_254X249X838P | P2 |
| 1 | SERVO-TILT | HDRV3W66P254_1X3_762X249X838P | P3 |
| 1 | JTAG10 | SHDRV10W66P254_2X5_2035X870X609P | P4 |
| 1 | POWER-CHARGE | TECONN-2-1445098-2 | P5 |
Show 43 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | POWER | HDRV4W66P254_1X4_1016X249X838P | P6 |
| 1 | BATCHG | HDRV2W66P254_1X2_508X249X838P | P7 |
| 1 | 12VIN | HDRV2W66P254_1X2_508X249X838P | P8 |
| 1 | BAT | TECONN-2-1445098-3 | P9 |
| 1 | ANDROID-SERIAL-TEST | HDRV3W66P254_1X3_762X249X838P | P10 |
| 1 | MOTOR-L | TECONN-2-1445098-2 | P11 |
| 1 | MOTOR-R | TECONN-2-1445098-2 | P12 |
| 1 | AND5V | HDRV2W66P254_1X2_508X249X838P | P13 |
| 1 | AUX | HDRV24W66P254_2X12_3048X503X838P | P14 |
| 1 | MOTOR-PWM-TEST | HDRV2W66P254_1X2_508X249X838P | P15 |
| 2 | BATTERY | EMPTY | BT1, BT2 |
| 1 | BTN_SPST | CKCOMP-PTS525SM10SMTR | S1 |
| 1 | DIODE | DIOM5226X220N | D1 |
| 1 | PWR | LEDC3216X100N | D2 |
| 1 | LED | LEDC3216X100N | D3 |
| 1 | MH2029-300Y | INDC2012X110N | FB1 |
| 1 | 68uH | IND_ASPI-8040S-680M-T | L1 |
| 18 | 0.1uF | CAPC2012X100N | C1, C4, C5, C7, C8, C9, C10, C14 +10 |
| 4 | 47pF | CAPC2012X100N | C2, C3, C36, C37 |
| 2 | 18pF | CAPC2012X100N | C6, C11 |
| 3 | 100uF 35V | CAPAE660X790N | C12, C25, C26 |
| 9 | 0.1uF 35V | CAPC2012X100N | C13, C27, C28, C29, C30, C31, C32, C33 +1 |
| 3 | 100uF | CAPAE660X790N | C15, C21, C46 |
| 1 | 100uF 15V | CAPAE660X790N | C17 |
| 1 | 6.8nF | CAPC2012X100N | C20 |
| 2 | 33nF 35V | CAPC2012X100N | C23, C24 |
| 2 | 12pF | CAPC2012X100N | C41, C44 |
| 1 | 4.7uF | CAPC2012X100N | C43 |
| 19 | 10K | RESC2012X100N | R1, R2, R6, R8, R25, R26, R27, R28 +11 |
| 6 | 1K | RESC2012X100N | R3, R9, R10, R11, R12, R13 |
| 2 | 22R | RESC2012X100N | R4, R5 |
| 1 | 1.5K | RESC2012X100N | R7 |
| 1 | 0.4 | RESC2012X100N | R14 |
| 1 | 760 | RESC2012X100N | R15 |
| 1 | 590R | RESC2012X100N | R16 |
| 3 | ??? | RESC2012X100N | R17, R18, R19 |
| 1 | 46K | RESC2012X100N | R20 |
| 2 | 100R | RESC2012X100N | R21, R43 |
| 1 | 100k | RESC2012X100N | R22 |
| 1 | 6.8k | RESC2012X100N | R23 |
| 1 | 45.3k | RESC2012X100N | R24 |
| 2 | 270R | RESC2012X100N | R38, R39 |
| 2 | 27R | RESC2012X100N | R40, R41 |
TelepresenceRobot design files
The KiCad project lives in the joeferner/telepresenceRobot repository on GitHub; these links point at the commit this page was built from.
- Layouthardware/main.kicad_pcb
TelepresenceRobot: common questions
What microcontroller does the TelepresenceRobot use?
The TelepresenceRobot is built around the STM32F102C6, from the STM32 family.
How big is the TelepresenceRobot PCB?
The TelepresenceRobot measures 84.6 × 84.6 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the TelepresenceRobot?
133 components, from 63 distinct parts. The full bill of materials is listed on this page.
Where can I download the TelepresenceRobot design files?
From the joeferner/telepresenceRobot repository on GitHub, which has the KiCad layout; the links under Design files point to each one.
Can I use the TelepresenceRobot design in my own project?
The repository has no license, so all rights stay with joeferner. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the TelepresenceRobot without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug STM32 firmware against it before you order a PCB.
Similar boards
 STM32
LumenPnP Motherboard
opulo-inc
149 × 95 mm296 parts4LCC-BY-SA-4.03.7k STM32
Base
google
52.3 × 52.3 mm36 parts2LApache-2.02.9k STM32
Type g
169 × 30 mm24 parts2LApache-2.02.9k STM32
Main panel
234 × 84 mm26 parts4LApache-2.02.9k STM32
Type a
150 × 30 mm14 parts2LApache-2.02.9k STM32
Type c
188 × 30 mm17 parts2LApache-2.02.9k