
Mobile-Robot

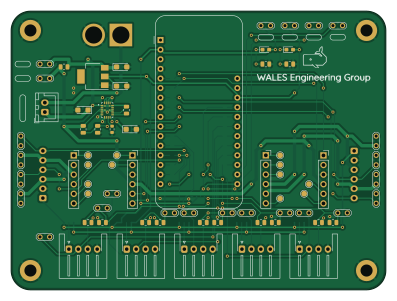
About the Mobile-Robot PCB
Mobile-Robot is an open source PCB design by ljparrish, published on GitHub. It is a 2-layer board measuring 99.1 × 73.7 mm, with 87 components from 24 distinct parts.
Other key parts include the LM1117IMPX-5.0/NOPB and Adafruit_Feather_Generic. By type, the board carries 24 jumpers, 24 test points, 15 resistors, 14 connectors, 5 capacitors and 2 diodes.
It belongs with the robotics & motion designs in this gallery.
From the project
Final Project for ME235 - Autonomous Mobile Robot
Main components on the Mobile-Robot
Mobile-Robot bill of materials (BOM)
87 components, 24 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | LM1117IMPX-5.0/NOPB LM1117-5.0 | SOT-223 | U1 |
| 1 | Adafruit_Feather_Generic | Adafruit_Feather | A1 |
| 5 | Conn_01x04_Male | JST_XH_S4B-XH-A-1_1x04_P2.50mm_Horizontal | J1, J4, J5, J6, J10 |
| 1 | XT60-M | AMASS_XT60-M | J2 |
| 1 | Conn_01x02_Male | JST_XH_B2B-XH-A_1x02_P2.50mm_Vertical | J3 |
| 2 | Conn_01x06_Male | JST_XH_B6B-XH-A_1x06_P2.50mm_Vertical | J7, J11 |
| 4 | Conn_01x06_Female | PinSocket_1x06_P2.54mm_Vertical | J8, J9, J12, J13 |
| 1 | Conn_01x04_Male | JST_SH_SM04B-SRSS-TB_1x04-1MP_P1.00mm_Horizontal | J14 |
| 1 | Jumper_2_Open | R_0805_2012Metric | JP1 |
| 5 | SolderJumper_3_Bridged12 | SolderJumper-3_P1.3mm_Bridged12_Pad1.0x1.5mm_NumberLabels | JP2, JP3, JP4, JP5, JP6 |
| 18 | SolderJumper_2_Bridged | SolderJumper-2_P1.3mm_Bridged_RoundedPad1.0x1.5mm | JP7, JP8, JP9, JP10, JP11, JP12, JP13, JP14 +10 |
| 24 | TestPoint | TestPoint_2Pads_Pitch2.54mm_Drill0.8mm | TP13, TP14, TP15, TP16, TP17, TP18, TP19, TP20 +16 |
| 1 | LT3033IUDC_PBF | VREG_LT3033IUDC_PBF | VR1 |
| 2 | LED | LED_0603_1608Metric_Pad1.05x0.95mm_HandSolder | D1, D2 |
| 3 | 399-3684-1 10uF | CP_EIA-3216-18_Kemet-A | C1, C3, C4 |
| 1 | 0.1uF | R_0603_1608Metric | C2 |
| 1 | 478-5651-1 100uF | CP_EIA-3216-18_Kemet-A | C5 |
| 1 | 100k | R_0805_2012Metric | R1 |
| 5 | 10k | R_0805_2012Metric | R2, R6, R8, R10, R12 |
| 5 | 15k | R_0805_2012Metric | R3, R7, R9, R11, R13 |
Show 4 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | 133k | R_0805_2012Metric | R4 |
| 1 | 10-ERA-6AEB3921V 3.92k | R_0805_2012Metric | R5 |
| 1 | 1k | R_0805_2012Metric | R14 |
| 1 | 3k | R_0805_2012Metric | R15 |
Mobile-Robot design files
The KiCad project lives in the ljparrish/Mobile-Robot repository on GitHub; these links point at the commit this page was built from.
Mobile-Robot: common questions
How big is the Mobile-Robot PCB?
The Mobile-Robot measures 99.1 × 73.7 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Mobile-Robot?
87 components, from 24 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Mobile-Robot design files?
From the ljparrish/Mobile-Robot repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the Mobile-Robot design in my own project?
The repository has no license, so all rights stay with ljparrish. Use it as a reference, and ask the author before reusing the design.
Similar boards
Stack chan
stack-chan
50 × 50 mm33 parts2LApache-2.01.7k
Cube batteryboard
willem-pennings
95 × 95 mm4 parts2LGPL-3.01.1k
Mesabob
rene-dev
87.5 × 50 mm44 parts2LGPL-3.0979
Bob
100 × 100 mm140 parts2LGPL-3.0979
Triple adapter
57 × 75 mm26 parts2LGPL-3.0979
Trollerv2
100 × 75 mm33 parts4LGPL-3.0979