
Base

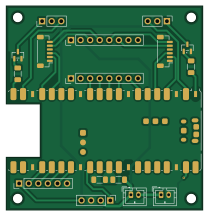
About the Base PCB
Base is an open source Raspberry Pi PCB design by LukeZhang0826, published on GitHub. It is a 2-layer board measuring 52 × 54 mm, with 17 components from 11 distinct parts.
Its main chip is the RaspberryPi_Pico_W, from the Raspberry Pi family. By type, the board carries 10 connectors, 4 resistors, 2 transistors and 1 module.
It belongs with the robotics & motion designs in this gallery.
From the project
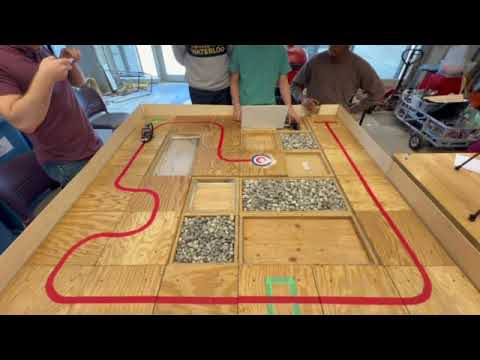
Autonomous line-following rescue robot built for a competition at Waterloo's IDEAS Clinic. Raspberry Pi Pico and Arduino Mega, Pixy2 vision, custom KiCad PCBs.
An autonomous line-following rescue robot, built for a competition at the University of Waterloo's IDEAS Clinic. It follows a track, finds a coloured target, picks it up with a servo claw, carries it to a safe zone, drops it, then finds the line again and drives back.
We called it Hamster, which is why the robot code lives in Hamster/.
Built by Josh Lobe, Koketso Gaborekwe, Luke Zhang, Winters Xia, and Griffin Wilson.
Main components on the Base
Base bill of materials (BOM)
17 components, 11 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | RaspberryPi_Pico_W | RaspberryPi_Pico_W_SMD | A2 |
| 2 | AO3400A | SOT-23 | Q1, Q2 |
| 2 | CONN_01X02_SOCKET Conn_01x02_Socket | JST_PH_B2B-PH-K_1x02_P2.00mm_Vertical | J1, J2 |
| 2 | CONN_01X06_SOCKET Conn_01x06_Socket | JST_SH_BM06B-SRSS-TB_1x06-1MP_P1.00mm_Vertical | J3, J4 |
| 1 | CONN_01X06 Conn_01x06 | PinHeader_1x06_P2.54mm_Vertical | J5 |
| 2 | CONN_01X03 Conn_01x03 | PinHeader_1x03_P2.54mm_Vertical | J6, J7 |
| 1 | CONN_01X04 Conn_01x04 | PinHeader_1x04_P2.54mm_Vertical | J8 |
| 2 | CONN_01X08 Conn_01x08 | PinHeader_1x08_P2.54mm_Vertical | J9, J10 |
| 2 | 10K 10k | R_1206_3216Metric_Pad1.30x1.75mm_HandSolder | R1, R2 |
| 1 | 100K 100k | R_1206_3216Metric_Pad1.30x1.75mm_HandSolder | R3 |
| 1 | 56K 56k | R_1206_3216Metric_Pad1.30x1.75mm_HandSolder | R4 |
Base design files
The KiCad project lives in the LukeZhang0826/RescueRobot repository on GitHub; these links point at the commit this page was built from.
Base: common questions
What microcontroller does the Base use?
The Base is built around the RaspberryPi_Pico_W, from the Raspberry Pi family.
How big is the Base PCB?
The Base measures 52 × 54 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Base?
17 components, from 11 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Base design files?
From the LukeZhang0826/RescueRobot repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the Base design in my own project?
The repository has no license, so all rights stay with LukeZhang0826. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the Base without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug Raspberry Pi firmware against it before you order a PCB.
More boards in RescueRobot
Similar boards
 Raspberry Pi
Open source rover
nasa-jpl
220 × 178 mm144 parts2LApache-2.09.7k Raspberry Pi
SPIRIT
SPIRIT-org
82 × 155 mm130 parts6LCERN-OHL-S-2.01.3k Raspberry Pi
CM5RevEng
schlae
55 × 40 mm417 parts10LNo license1.0k Raspberry Pi
Haxo hw
cardonabits
102.4 × 211.3 mm38 parts2LCustom license672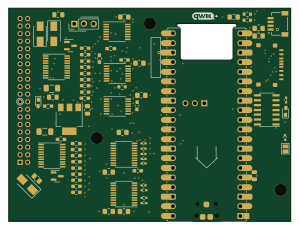 Raspberry Pi
PowerBook
BlueSCSI
74.5 × 56.3 mm78 parts2LGPL-3.0449 Raspberry Pi
Desktop 50 Pin TopConn
89.2 × 82.6 mm103 parts2LGPL-3.0449