
Agribot

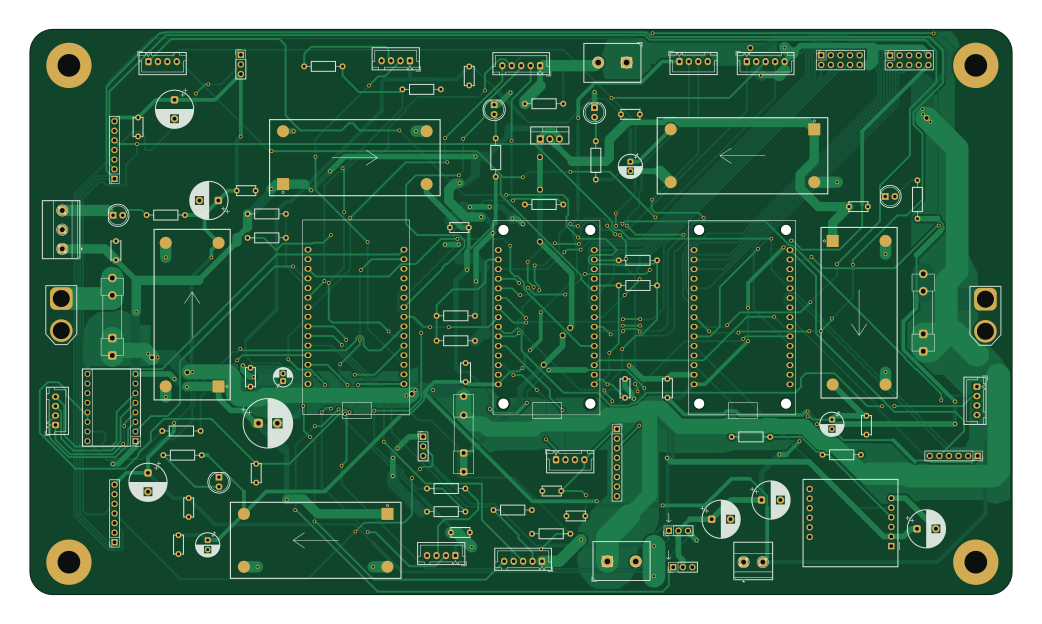
About the Agribot PCB
Agribot is an open source ESP32 PCB design by Maleksameh61, published on GitHub under the MIT license. It is a 2-layer board measuring 260 × 149.6 mm, with 96 components from 42 distinct parts.
Its main chip is the ESP32 DevKit 30-pin, from the ESP32 family. Other key parts include the Display link (CYD), ultrasonic, BH1750_GY302_Module, MPU6050_GY521 and MAX98357A_Module. By type, the board carries 29 capacitors, 22 resistors, 16 connectors, 12 ICs, 8 modules and 6 diodes.
It belongs with the robotics & motion, audio and sensors designs in this gallery.
From the project
AgriBot is a farming rover with a top speed of 1.4 km/h, and this is the one board that runs all of it: three ESP32s, five buck converters, the motor driver links, a stepper that shoves a soil probe into the ground, GPS, a SIM800L and two speakers, all on 260 x 150 mm of 2 oz cop
AgriBot is a farming rover with a top speed of 1.4 km/h, and this is the one board that runs all of it: three ESP32s, five buck converters, the motor driver links, a stepper that shoves a soil probe into the ground, GPS, a SIM800L and two speakers, all on 260 x 150 mm of 2 oz copper.
Your phone joins the WiFi network that the Sensors ESP32 puts up, then sends throttle and steering about 20 times a second over UDP. Sensors passes that down a UART to the Motion ESP32, and Motion mixes it into left and right wheel speeds for the two Cytron MDD10A motor drivers. The drivers live off the board.…
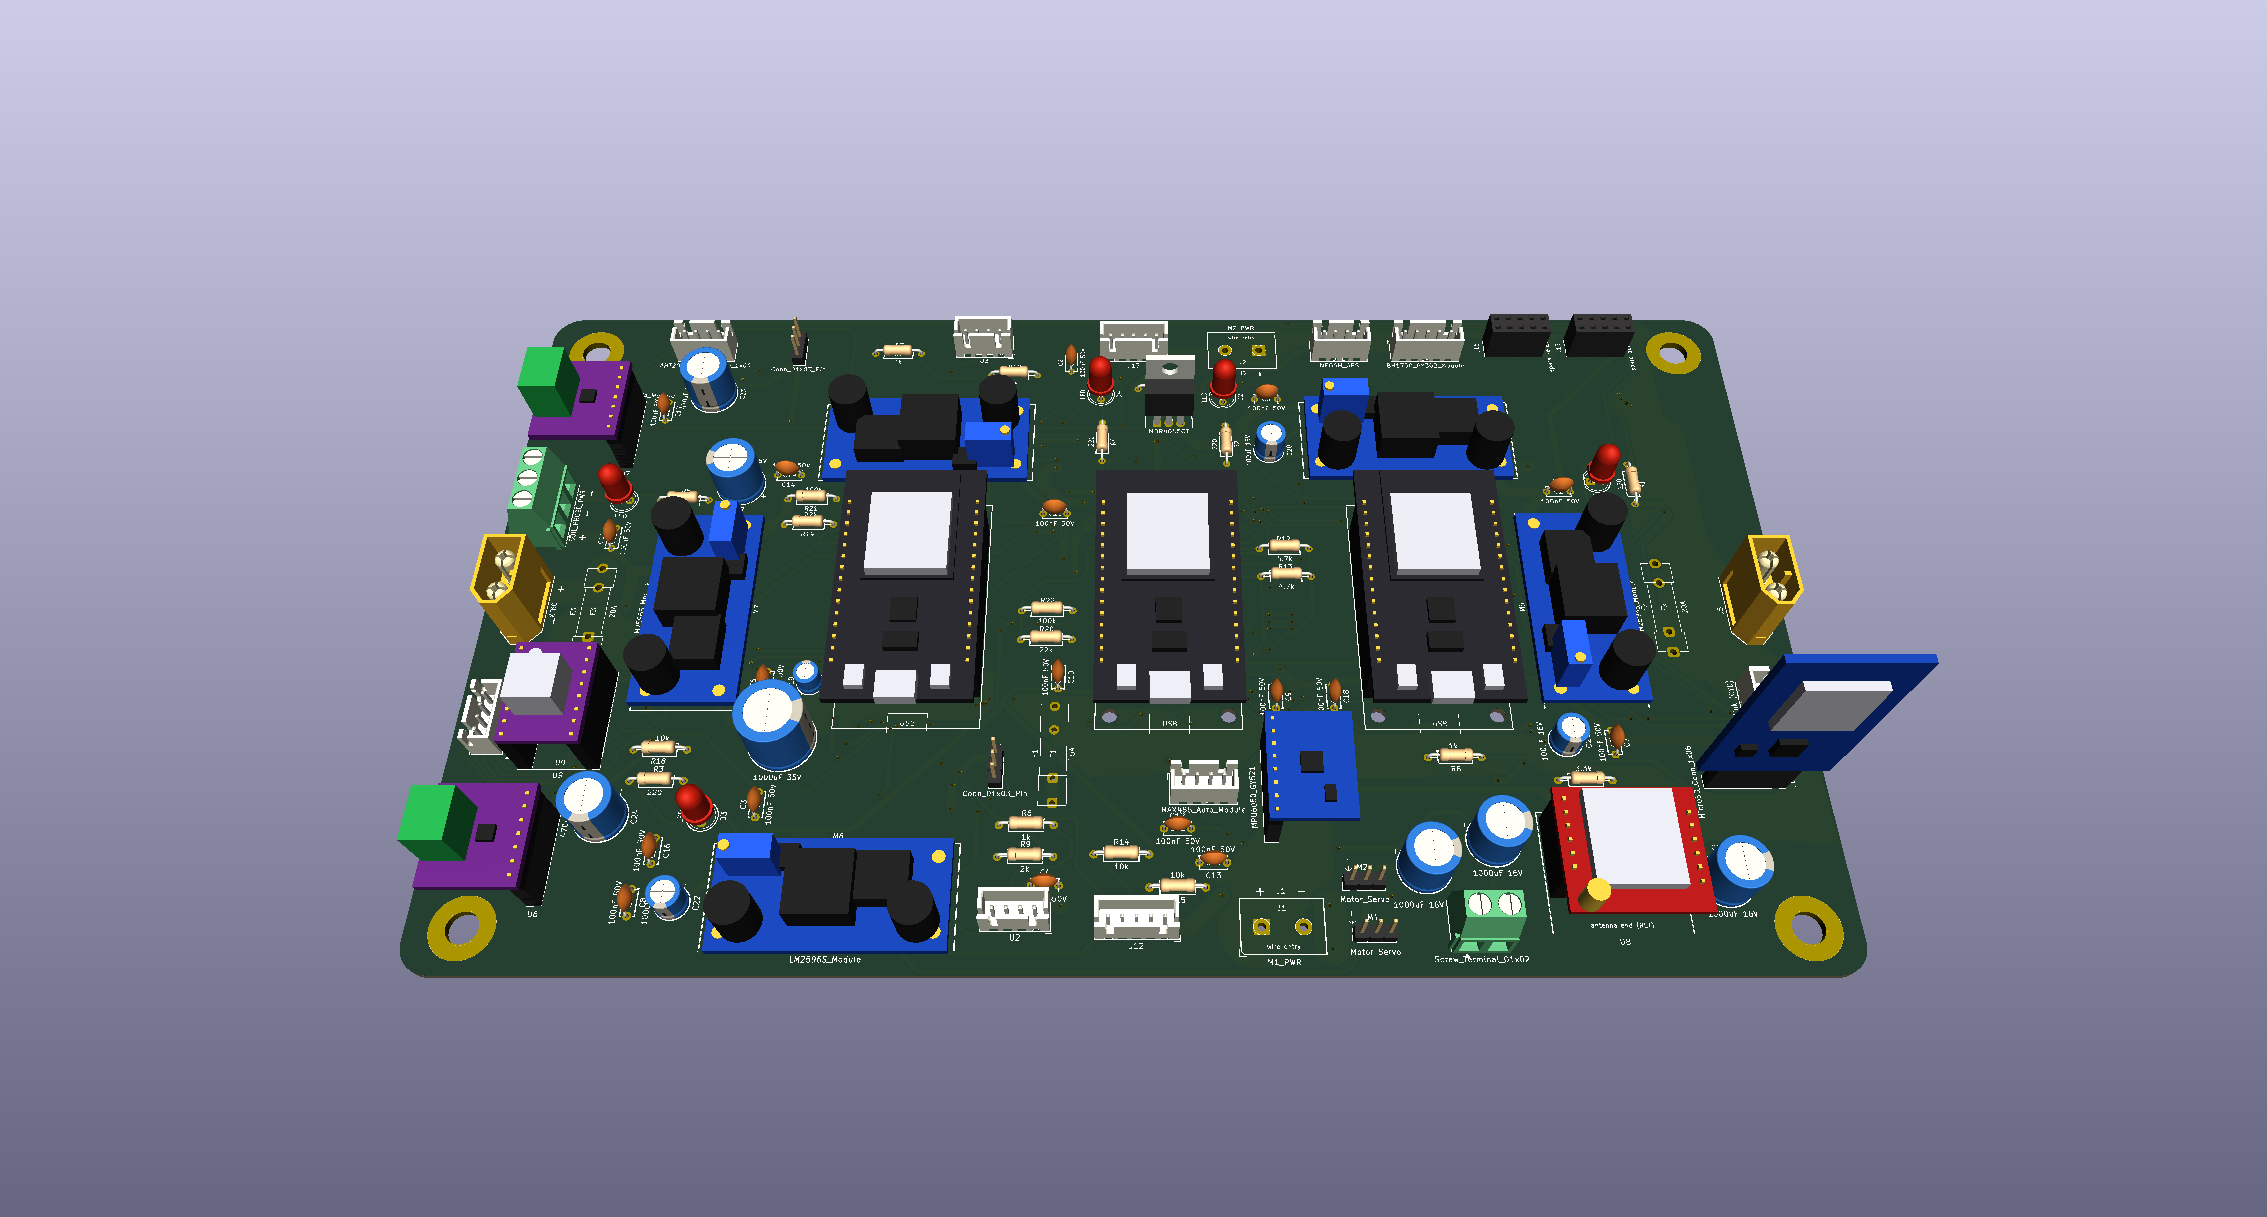
Main components on the Agribot
Agribot bill of materials (BOM)
96 components, 42 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | Display link (CYD) | JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | U1 |
| 2 | ultrasonic | JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | U2, U3 |
| 1 | BH1750_GY302_Module | JST_XH_B5B-XH-A_1x05_P2.50mm_Vertical | U4 |
| 1 | MPU6050_GY521 | PinSocket_1x08_P2.54mm_Vertical | U5 |
| 2 | MAX98357A_Module | PinSocket_1x07_P2.54mm_Vertical | U6, U7 |
| 1 | SIM800L_Module | SIM800L_Module | U8 |
| 1 | DRV8825_Carrier | Pololu_Breakout-16_15.2x20.3mm_D1.0mm | U9 |
| 3 | ESP32 DevKit 30-pin | ESP32_30pin_D1.0mm | U10, U11, U12 |
| 2 | Motor_Servo | PinHeader_1x03_P2.54mm_Vertical | M1, M2 |
| 5 | LM2596S_Module | LM2596S_Module_FlatMount_SMD | M3, M4, M5, M6, M7 |
| 1 | MAX485_Auto_Module | JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | M8 |
| 1 | M1_PWR | KF128-7.5_1x02_P7.50mm_Horizontal | J1 |
| 1 | M2_PWR | KF128-7.5_1x02_P7.50mm_Horizontal | J2 |
| 1 | SOIL_PROBE_PWR | TerminalBlock_Phoenix_MKDS-1,5-3-5.08_1x03_P5.08mm_Horizontal | J3 |
| 1 | Screw_Terminal_01x02 | TerminalBlock_Phoenix_MKDS-1,5-2-5.08_1x02_P5.08mm_Horizontal | J4 |
| 2 | XT60 | AMASS_XT60-M_1x02_P7.20mm_Vertical | J5, J6 |
| 2 | Conn_01x03_Pin | PinHeader_1x03_P2.54mm_Vertical | J7, J8 |
| 1 | AHT20_BMP280_Conn_1x04 | JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | J9 |
| 1 | NEMA17_Conn_1x04 | JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | J10 |
| 1 | NEO6M_GPS | JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | J11 |
Show 22 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 2 | MDD10A_Signal | JST_XH_B5B-XH-A_1x05_P2.50mm_Vertical | J12, J13 |
| 1 | MicroSD_Conn_1x06 | PinSocket_1x06_P2.54mm_Vertical | J14 |
| 1 | spare audio pins | PinSocket_2x05_P2.54mm_Vertical | J15 |
| 1 | spare sensor pins | PinSocket_2x05_P2.54mm_Vertical | J16 |
| 1 | T5A | Fuseholder_Clip-5x20mm_Littelfuse_111_Inline_P20.00x5.00mm_D1.05mm_Horizontal | F1 |
| 2 | 20A | Fuseholder_Clip-5x20mm_Littelfuse_100_Inline_P20.50x4.60mm_D1.30mm_Horizontal | F2, F3 |
| 5 | LED | LED_D5.0mm | D1, D2, D3, D4, D5 |
| 1 | MBR4045CT | TO-220-3_Vertical | D6 |
| 18 | 100nF 50V | C_Disc_D5.0mm_W2.5mm_P5.00mm | C1, C2, C3, C4, C5, C6, C7, C8 +10 |
| 1 | 10uF 16V | CP_Radial_D5.0mm_P2.00mm | C19 |
| 3 | 100uF 16V | CP_Radial_D6.3mm_P2.50mm | C20, C21, C22 |
| 2 | 470uF 16V | CP_Radial_D10.0mm_P5.00mm | C23, C24 |
| 4 | 1000uF 16V | CP_Radial_D10.0mm_P5.00mm | C25, C26, C27, C28 |
| 1 | 1000uF 35V | CP_Radial_D13.0mm_P5.00mm | C29 |
| 5 | 220 | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R1, R2, R3, R4, R5 |
| 3 | 1k | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R6, R7, R8 |
| 2 | 2k | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R9, R10 |
| 1 | 3.3k | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R11 |
| 2 | 4.7k | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R12, R13 |
| 5 | 10k | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R14, R15, R16, R17, R18 |
| 2 | 22k | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R19, R20 |
| 2 | 100k | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R21, R22 |
Agribot design files
The KiCad project lives in the Maleksameh61/Agribot repository on GitHub; these links point at the commit this page was built from.
- LayoutPCB/agribot.kicad_pcb
- SchematicPCB/agribot.kicad_sch
Agribot: common questions
What microcontroller does the Agribot use?
The Agribot is built around the ESP32 DevKit 30-pin, from the ESP32 family.
How big is the Agribot PCB?
The Agribot measures 260 × 149.6 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Agribot?
96 components, from 42 distinct parts. The full bill of materials is listed on this page.
Where can I download the Agribot design files?
From the Maleksameh61/Agribot repository on GitHub, which has the KiCad layout and the schematic; the links under Design files point to each one.
Can I use the Agribot design in my own project?
Yes, under the terms of its MIT license, which Maleksameh61 chose for the repository.
Can I test firmware for the Agribot without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug ESP32 firmware against it before you order a PCB.
Similar boards
 ESP32
OSO-BOOK-B1
joeycastillo
85 × 115 mm65 parts2LCC-BY-SA-4.08.1k ESP32
Powertrain
byrantech
64 × 45.4 mm171 parts4LMIT4.3k ESP32
Badge
atopile
56.3 × 39 mm239 parts4LMIT4.0k ESP32
Esp32 minimal
36.2 × 26.8 mm20 parts2LMIT4.0k ESP32
Controller
StuckAtPrototype
29 × 74 mm58 parts4LApache-2.03.8k ESP32
Racer
36 × 50.2 mm70 parts4LApache-2.03.8k