
Thruster Controller V2

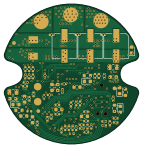
About the Thruster Controller V2 PCB
Thruster Controller V2 is an open source PCB design by mark-belbin, published on GitHub under the GPL-3.0 license. It is a 4-layer board measuring 35.5 × 37 mm, with 102 components from 46 distinct parts.
Other key parts include the NCP718AMT330, TMS320F280041C, DRV8320S, NCP718AMT500 and ATA6561. By type, the board carries 44 capacitors, 35 resistors, 7 connectors, 5 ICs, 5 diodes and 3 transistors.
It belongs with the robotics & motion designs in this gallery, and the repository also holds 1 earlier revision of it.
From the project
Custom FOC motor controller designed for underwater robotics.
The final controller is designed for T200 or T100 thrusters from BlueRobotics, boasting sensorless FOC and a miniature form-factor that is built right into the thruster.
For most hobby BLDC controllers, commonly referred to as electronic speed controllers (ESCs), motor commutation is accomplished through sensorless trapezoidal 6-step control. This commutation method steps through 6 distinct stator magnetic field positions in order to keep the motor spinning, based only on the feedback of the back-EMF voltage of the three motor phases. With only 6 available control positions, this method of…
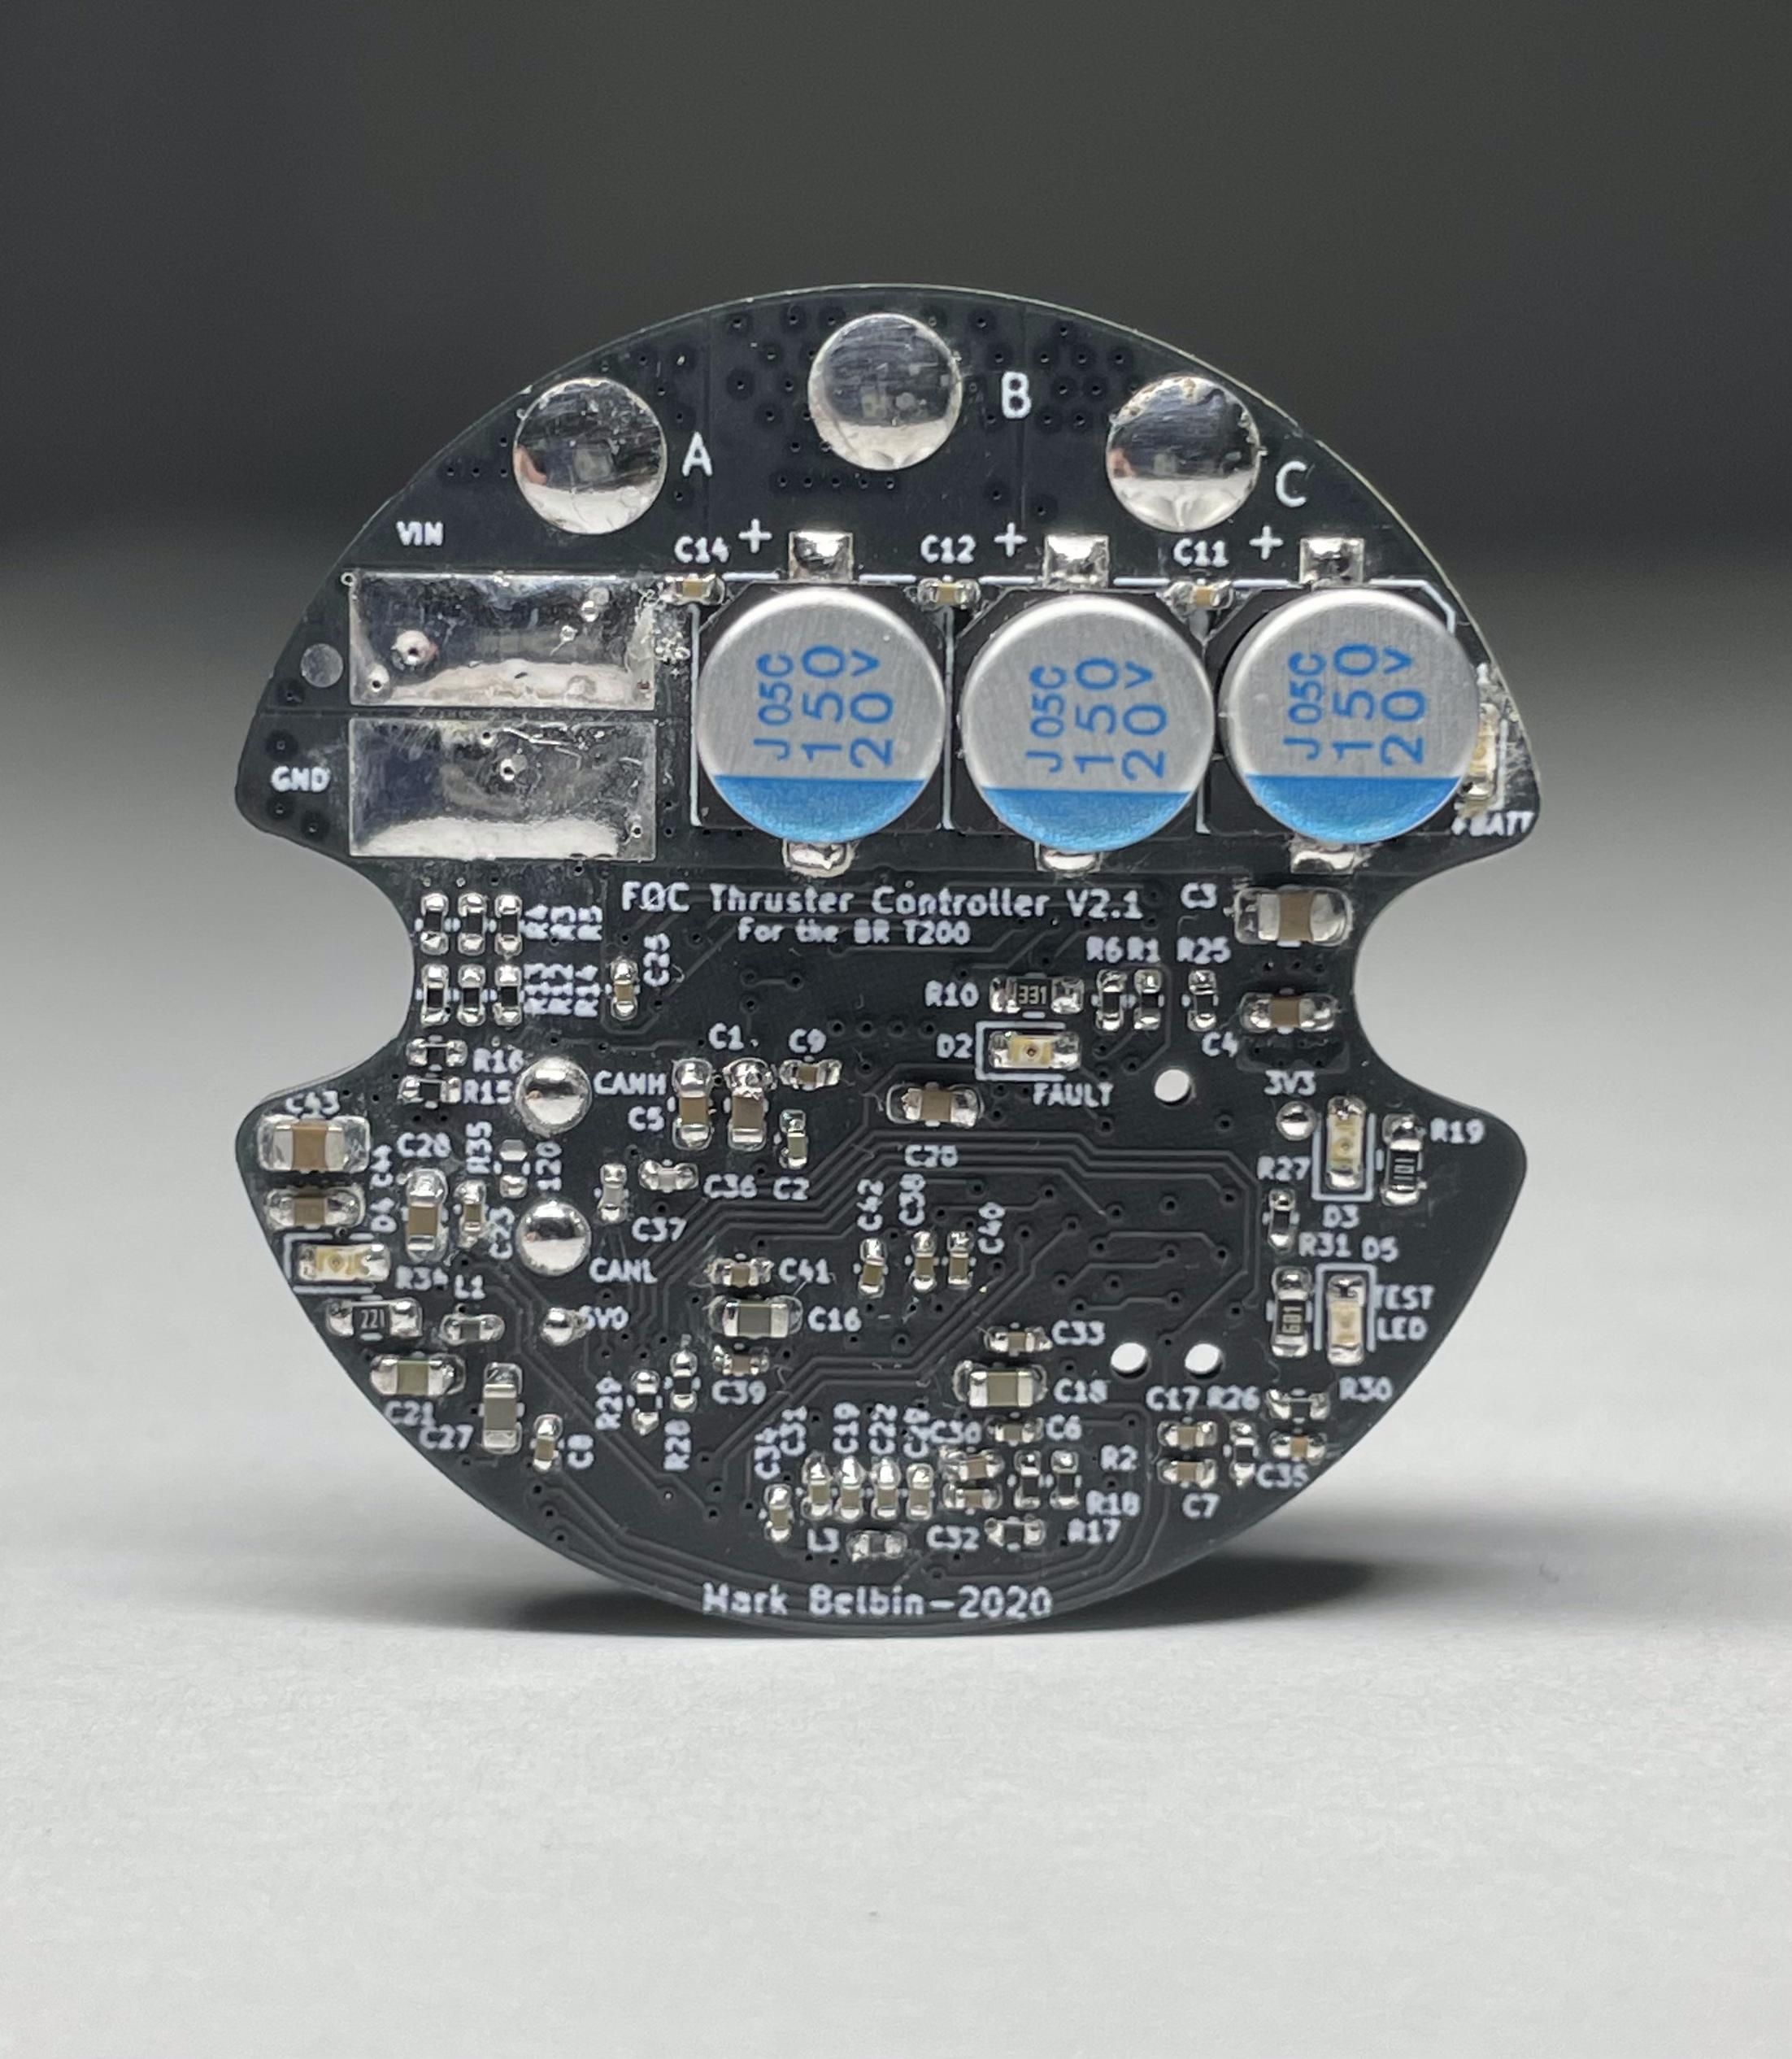
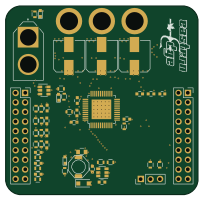
Main components on the Thruster Controller V2
Thruster Controller V2 bill of materials (BOM)
102 components, 46 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | NCP718AMT330 | DFN-6-1EP_2x2mm_P0.65mm_EP1x1.6mm | U1 |
| 1 | TMS320F280041C | QFN-56-1EP_7x7mm_P0.4mm_EP5.6x5.6mm | U2 |
| 1 | DRV8320S | WQFN-32-1EP_5x5mm_P0.5mm_EP3.1x3.1mm | U3 |
| 1 | NCP718AMT500 | DFN-6-1EP_2x2mm_P0.65mm_EP1x1.6mm | U4 |
| 1 | ATA6561 | DFN-8-1EP_3x3mm_P0.65mm_EP1.7x2.05mm | U8 |
| 3 | SIZF906DT | SIZF906DT | Q1, Q2, Q3 |
| 1 | SER3629 20 MHz | Crystal_SMD_SeikoEpson_FA238-4pin_3.2x2.5mm | Y1 |
| 1 | PHASE_A | Phase_Pad | J1 |
| 1 | PHASE_B | Phase_Pad | J2 |
| 1 | PHASE_C | Phase_Pad | J3 |
| 1 | CONN_01X01 CANL | CAN_Pad | J4 |
| 1 | CONN_01X01 CANH | CAN_Pad | J6 |
| 1 | CONN_01X01 VIN | Bus_Pad | J7 |
| 1 | CONN_01X01 GND | Bus_Pad | J8 |
| 1 | 732-4966-1 BLUE | LED_0603_1608Metric | D1 |
| 1 | 732-4978-1 RED | LED_0603_1608Metric | D2 |
| 2 | 732-4980-1 GREEN | LED_0603_1608Metric | D3, D4 |
| 1 | 160-1180-1 Orange | LED_0603_1608Metric | D5 |
| 1 | 490-11021-1 220 Ohm | L_0402_1005Metric | L1 |
| 1 | 445-172882-1 60 Ohm | L_0402_1005Metric | L3 |
Show 26 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | 4.7UF 4.7uF | C_0603_1608Metric | C1 |
| 1 | 0.047UF 0.047uF | C_0402_1005Metric | C2 |
| 2 | 1UF 1uF | C_0805_2012Metric | C3, C43 |
| 5 | 1UF 1uF | C_0603_1608Metric | C4, C5, C20, C28, C44 |
| 14 | 0.1UF 0.1uF | C_0402_1005Metric | C6, C7, C8, C9, C17, C23, C31, C33 +6 |
| 3 | 220UF 220uF | CP_Elec_6.3x5.8 | C10, C13, C15 |
| 3 | 0.01UF 0.01uF | C_0402_1005Metric | C11, C12, C14 |
| 4 | 10UF 10uF | C_0603_1608Metric | C16, C18, C21, C27 |
| 5 | 2.2UF 2.2uF | C_0402_1005Metric | C19, C22, C29, C30, C32 |
| 3 | 2200PF 2200pF | C_0402_1005Metric | C24, C25, C26 |
| 1 | 0.01UF 10nF | C_0402_1005Metric | C35 |
| 2 | 9PF 9pF | C_0402_1005Metric | C36, C37 |
| 3 | 2.2K 2.2k | R_0402_1005Metric | R1, R27, R30 |
| 3 | 27.4K 27.4k | R_0402_1005Metric | R2, R17, R18 |
| 4 | 22.0K 22.0k | R_0402_1005Metric | R3, R4, R5, R15 |
| 5 | 10K 10k | R_0402_1005Metric | R6, R25, R26, R28, R29 |
| 1 | 2.7K 2.7k | R_0603_1608Metric | R7 |
| 3 | 5m | R_2512_6332Metric | R8, R9, R11 |
| 1 | 330 | R_0603_1608Metric | R10 |
| 4 | 4.99K 4.99k | R_0402_1005Metric | R12, R13, R14, R16 |
| 1 | 100 | R_0603_1608Metric | R19 |
| 4 | 56 | R_0402_1005Metric | R20, R21, R22, R33 |
| 3 | 2.49K 2.49k | R_0402_1005Metric | R23, R24, R32 |
| 1 | 680 | R_0603_1608Metric | R31 |
| 1 | 220 | R_0603_1608Metric | R34 |
| 1 | 120 | R_0402_1005Metric | R35 |
Thruster Controller V2 design files
The KiCad project lives in the mark-belbin/motor-controller repository on GitHub; these links point at the commit this page was built from.
Thruster Controller V2: common questions
How big is the Thruster Controller V2 PCB?
The Thruster Controller V2 measures 35.5 × 37 mm, has 4 copper layers and is 1.6 mm thick.
How many components are on the Thruster Controller V2?
102 components, from 46 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Thruster Controller V2 design files?
From the mark-belbin/motor-controller repository on GitHub, which has the KiCad layout and the BOM; the links under Design files point to each one.
Can I use the Thruster Controller V2 design in my own project?
Yes, under the terms of its GPL-3.0 license, which mark-belbin chose for the repository.
More boards in motor-controller
Earlier revisions in the repo: Thruster_Controller
Similar boards
Cube batteryboard
willem-pennings
95 × 95 mm4 parts2LGPL-3.01.1k
Rp2040 encoder
Twisted-Fields
36.7 × 33.3 mm10 parts2LCustom license417
VESC Controller
paltatech
160 × 90 mm908 parts2LNo license354
${BOARD NAME} Assembly
EPFLXplore
45 × 43.5 mm21 parts4LApache-2.0345
OpenESC-20x20
OpenDrone-hw
31.2 × 33 mm180 parts6LCERN-OHL-S-2.0243
Legacy stepper motor analyzer
zapta
96.7 × 66.4 mm28 parts2LCC0-1.0163