
Erc rover-EyP

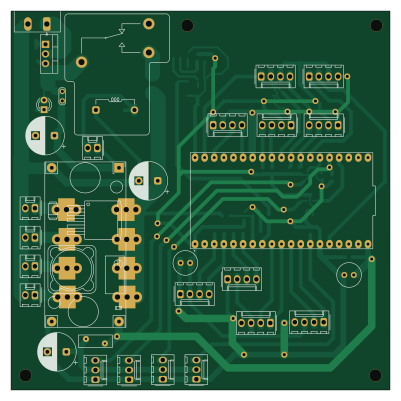
About the Erc rover-EyP PCB
Erc rover-EyP is an open source ESP32 PCB design by Matyy38, published on GitHub. It is a 2-layer board measuring 100 × 100 mm, with 72 components from 47 distinct parts.
Its main chip is the ESP32, from the ESP32 family. Other key parts include the NLAS4157, LM2596_StepDown_LM2596 and TMCS1126. By type, the board carries 19 connectors, 18 resistors, 15 capacitors, 5 ICs, 5 fuses and 5 diodes.
From the project
Documentación del subsistema de Electrónica y Potencia del rover del European Rover Challenge (IEEE ITBA I+D). Dos frentes: el rover final (40 kg, bus de 24 V, swerve de 4 ruedas) y el modelo a escala, que es un instrumento de medición para cerrar la especificación de motores sin
Documentación del subsistema de Electrónica y Potencia del rover del European Rover Challenge (IEEE ITBA I+D). Dos frentes: el rover final (40 kg, bus de 24 V, swerve de 4 ruedas) y el modelo a escala, que es un instrumento de medición para cerrar la especificación de motores sin comprar motores de tamaño real a ciegas.
Empezá por 00-contexto/00-contexto-maestro.md. Tiene el estado, los conflictos abiertos y el mapa.
Main components on the Erc rover-EyP
Erc rover-EyP bill of materials (BOM)
72 components, 47 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 3 | NLAS4157 | SOT-363_SC-70-6_tomi | U1, U4, U5 |
| 1 | LM2596_StepDown_LM2596 | LM2596_buck | U2 |
| 1 | TMCS1126 | SOIC10_DVG_TEX | U3 |
| 1 | IRF9540N | TO-220-3_Vertical | Q1 |
| 1 | Alimentacion | PhoenixContact_MSTBA_2,5_2-G_1x02_P5.00mm_Horizontal | J1 |
| 1 | E-Stop | Molex_KK-254_AE-6410-02A_1x02_P2.54mm_Vertical | J2 |
| 1 | MPU6050 | Molex_KK-254_AE-6410-04A_1x04_P2.54mm_Vertical | J3 |
| 1 | 12v_driver_2 | Molex_KK-254_AE-6410-02A_1x02_P2.54mm_Vertical | J4 |
| 1 | 12v_driver_3 | Molex_KK-254_AE-6410-02A_1x02_P2.54mm_Vertical | J5 |
| 1 | 12v_driver_1 | Molex_KK-254_AE-6410-02A_1x02_P2.54mm_Vertical | J6 |
| 1 | 12v_driver_4 | Molex_KK-254_AE-6410-02A_1x02_P2.54mm_Vertical | J7 |
| 1 | Encoder RR | Molex_KK-254_AE-6410-04A_1x04_P2.54mm_Vertical | J8 |
| 1 | Encoder FR | Molex_KK-254_AE-6410-04A_1x04_P2.54mm_Vertical | J9 |
| 1 | BTS7960_1 | Molex_KK-254_AE-6410-04A_1x04_P2.54mm_Vertical | J10 |
| 1 | BTS7960_2 | Molex_KK-254_AE-6410-04A_1x04_P2.54mm_Vertical | J11 |
| 1 | Servo1 | Molex_KK-254_AE-6410-03A_1x03_P2.54mm_Vertical | J12 |
| 1 | Servo3 | Molex_KK-254_AE-6410-03A_1x03_P2.54mm_Vertical | J13 |
| 1 | Servo2 | Molex_KK-254_AE-6410-03A_1x03_P2.54mm_Vertical | J14 |
| 1 | BTS7960_3 | Molex_KK-254_AE-6410-04A_1x04_P2.54mm_Vertical | J15 |
| 1 | Encoder FL | Molex_KK-254_AE-6410-04A_1x04_P2.54mm_Vertical | J16 |
Show 27 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | Servo4 | Molex_KK-254_AE-6410-03A_1x03_P2.54mm_Vertical | J17 |
| 1 | Encoder RL | Molex_KK-254_AE-6410-04A_1x04_P2.54mm_Vertical | J18 |
| 1 | BTS7960_4 | Molex_KK-254_AE-6410-04A_1x04_P2.54mm_Vertical | J19 |
| 1 | ESP32 | esp32_39pin | ESP1 |
| 1 | Polyfuse | RV_Disc_D9mm_W3.3mm_P5mm | F2 |
| 4 | Fuse | FuseClip_5x20_ZH266 | F3, F4, F5, F6 |
| 1 | Jumper_2_Small_Open | TestPoint_2Pads_Pitch2.54mm_Drill0.8mm | JP1 |
| 1 | RAYEX-L90S | Relay_SPDT_RAYEX-L90S | K1 |
| 1 | SM6T15A | D_SMB_Handsoldering | D1 |
| 1 | BAT54S | SOT-23 | D2 |
| 1 | D | D_SMA_Handsoldering | D3 |
| 1 | 16v | D_MiniMELF | D4 |
| 1 | LED | LED_D3.0mm | D5 |
| 1 | 1k | L_0805_2012Metric | FB1 |
| 3 | 1000u | CP_Radial_D10.0mm_P5.00mm | C1, C2, C7 |
| 2 | 100n | C_0805_2012Metric | C3, C4 |
| 3 | 1u | C_0805_2012Metric | C5, C10, C11 |
| 2 | 100n | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C6, C8 |
| 2 | 100u | C_Radial_D6.3mm_H5.0mm_P2.50mm | C9, C15 |
| 3 | 100n | C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C12, C13, C14 |
| 10 | 4.7k | R_0805_2012Metric | R1, R2, R3, R7, R8, R9, R10, R11 +2 |
| 1 | 47k | R_0805_2012Metric | R4 |
| 1 | 2k2 | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R5 |
| 1 | 10k | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R6 |
| 3 | 10k | R_0805_2012Metric | R14, R21, R22 |
| 1 | 1k | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R15 |
| 1 | 2k2 | R_0805_2012Metric | R16 |
Erc rover-EyP design files
The KiCad project lives in the Matyy38/erc-rover-EyP repository on GitHub; these links point at the commit this page was built from.
Erc rover-EyP: common questions
What microcontroller does the Erc rover-EyP use?
The Erc rover-EyP is built around the ESP32, from the ESP32 family.
How big is the Erc rover-EyP PCB?
The Erc rover-EyP measures 100 × 100 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Erc rover-EyP?
72 components, from 47 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the Erc rover-EyP design files?
From the Matyy38/erc-rover-EyP repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the Erc rover-EyP design in my own project?
The repository has no license, so all rights stay with Matyy38. Use it as a reference, and ask the author before reusing the design.
Can I test firmware for the Erc rover-EyP without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug ESP32 firmware against it before you order a PCB.
Similar boards
 ESP32
Open Book Abridged Edition
joeycastillo
85 × 115 mm65 parts2LCC-BY-SA-4.08.1k ESP32
Badge
atopile
56.3 × 39 mm239 parts4LMIT4.0k ESP32
Esp32 minimal
36.2 × 26.8 mm20 parts2LMIT4.0k ESP32
Racer
StuckAtPrototype
36 × 50.2 mm70 parts4LApache-2.03.8k ESP32
Controller
29 × 74 mm58 parts4LApache-2.03.8k ESP32
Bitaxe
skot
56.5 × 99.8 mm86 parts4LCERN-OHL-S-2.01.4k