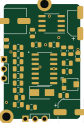
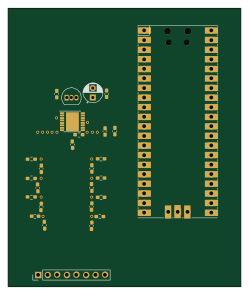
SethEMG v2

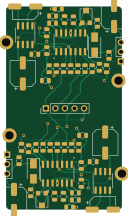
About the SethEMG v2 PCB
SethEMG v2 is an open source PCB design by Medical-Robotics-Limbo, published on GitHub. It is a 2-layer board measuring 30.7 × 53.9 mm, with 28 components from 14 distinct parts.
Other key parts include the LM324 and ICL7660. By type, the board carries 15 resistors, 8 capacitors, 2 ICs, 1 connector and 1 diode.
Main components on the SethEMG v2
SethEMG v2 bill of materials (BOM)
28 components, 14 distinct parts — part numbers from the project's BOM.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | LM324 | SOIC127P600X175-14N | U1 |
| 1 | ICL7660 | SOIC-8_3.9x4.9mm_P1.27mm | U2 |
| 1 | MCU_out | PinHeader_1x03_P2.54mm_Vertical | J3 |
| 1 | 100k | Potentiometer_Bourns_TC33X_Vertical | RV1 |
| 1 | SS14 | D_SMA | D1 |
| 2 | 470n | C_0805_2012Metric | C1, C2 |
| 2 | 330n | C_0805_2012Metric | C3, C4 |
| 1 | 100n | C_0805_2012Metric | C5 |
| 3 | 10u | CP_Elec_6.3x5.4 | C6, C8, C9 |
| 5 | 1k | R_0805_2012Metric | R1, R2, R9, R10, R13 |
| 3 | 47k | R_0805_2012Metric | R3, R4, R14 |
| 2 | 15k | R_0805_2012Metric | R5, R6 |
| 3 | 18k | R_0805_2012Metric | R7, R11, R15 |
| 2 | 10k | R_0805_2012Metric | R8, R12 |
SethEMG v2 design files
The KiCad project lives in the Medical-Robotics-Limbo/Electrical repository on GitHub; these links point at the commit this page was built from.
SethEMG v2: common questions
How big is the SethEMG v2 PCB?
The SethEMG v2 measures 30.7 × 53.9 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the SethEMG v2?
28 components, from 14 distinct parts, with part numbers taken from the project's own BOM. The full bill of materials is listed on this page.
Where can I download the SethEMG v2 design files?
From the Medical-Robotics-Limbo/Electrical repository on GitHub, which has the KiCad layout, the schematic and the BOM; the links under Design files point to each one.
Can I use the SethEMG v2 design in my own project?
The repository has no license, so all rights stay with Medical-Robotics-Limbo. Use it as a reference, and ask the author before reusing the design.