
Real-Time-Gesture-Controlled-Bot

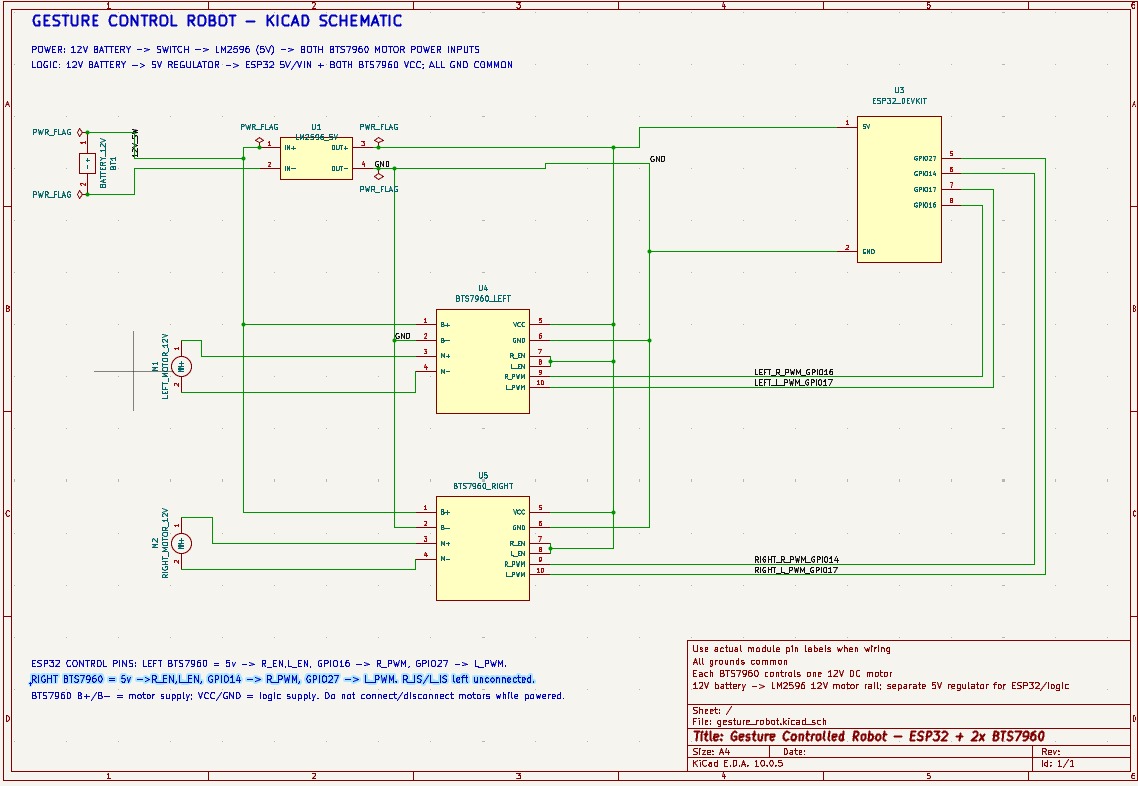
About the Real-Time-Gesture-Controlled-Bot PCB
Real-Time-Gesture-Controlled-Bot is an open source ESP32 PCB design by PrinceSanchela, published on GitHub under the MIT license. It is a board, with 7 components from 7 distinct parts.
Its main chip is the ESP32_DEVKIT, from the ESP32 family. Other key parts include the LM2596_5V, BTS7960_LEFT and BTS7960_RIGHT. By type, the board carries 4 ICs, 2 modules and 1 battery holder.
It belongs with the robotics & motion, iot & wireless and power & battery designs in this gallery.
From the project
Low-latency vision-controlled robot using custom YOLOv8 hand gesture recognition, ESP32 WebSocket server, and dual BTS7960 43A motor drivers. Features CPU & CUDA GPU pipelines, watchdog safety, and KiCad schematics."
An end-to-end, low-latency vision-controlled robotic platform. This project integrates custom-trained YOLOv8 hand-gesture recognition with an ESP32 microcontroller and dual BTS7960 43A H-Bridge motor drivers via a high-throughput asynchronous WebSocket protocol.
Both dedicated CPU (main.cpu.py) and CUDA GPU (main.cuda.py) runtimes are supported, complemented by an interactive dual-motor serial calibration utility, custom model training pipeline on Google Colab, and complete KiCad electrical schematics.
Main components on the Real-Time-Gesture-Controlled-Bot
Real-Time-Gesture-Controlled-Bot bill of materials (BOM)
7 components, 7 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | LM2596_5V | PinHeader_1x04_P2.54mm_Vertical | U1 |
| 1 | ESP32_DEVKIT | PinHeader_1x10_P2.54mm_Vertical | U3 |
| 1 | BTS7960_LEFT | PinHeader_1x10_P2.54mm_Vertical | U4 |
| 1 | BTS7960_RIGHT | PinHeader_1x10_P2.54mm_Vertical | U5 |
| 1 | LEFT_MOTOR_12V | TerminalBlock_Phoenix_MKDS-1,5-2-5.08_1x02_P5.08mm_Horizontal | M1 |
| 1 | RIGHT_MOTOR_12V | TerminalBlock_Phoenix_MKDS-1,5-2-5.08_1x02_P5.08mm_Horizontal | M2 |
| 1 | BATTERY_12V | TerminalBlock_Phoenix_MKDS-1,5-2-5.08_1x02_P5.08mm_Horizontal | BT1 |
Real-Time-Gesture-Controlled-Bot design files
The KiCad project lives in the PrinceSanchela/Real-Time-Gesture-Controlled-Bot repository on GitHub; these links point at the commit this page was built from.
- Schematicgesture_robot.kicad_sch
Real-Time-Gesture-Controlled-Bot: common questions
What microcontroller does the Real-Time-Gesture-Controlled-Bot use?
The Real-Time-Gesture-Controlled-Bot is built around the ESP32_DEVKIT, from the ESP32 family.
How many components are on the Real-Time-Gesture-Controlled-Bot?
7 components, from 7 distinct parts. The full bill of materials is listed on this page.
Where can I download the Real-Time-Gesture-Controlled-Bot design files?
From the PrinceSanchela/Real-Time-Gesture-Controlled-Bot repository on GitHub, which has the schematic; the links under Design files point to each one.
Can I use the Real-Time-Gesture-Controlled-Bot design in my own project?
Yes, under the terms of its MIT license, which PrinceSanchela chose for the repository.
Can I test firmware for the Real-Time-Gesture-Controlled-Bot without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug ESP32 firmware against it before you order a PCB.
Similar boards
 ESP32
Open Book Abridged Edition
joeycastillo
85 × 115 mm65 parts2LCC-BY-SA-4.08.1k ESP32
Badge
atopile
56.3 × 39 mm239 parts4LMIT4.0k ESP32
Esp32 minimal
36.2 × 26.8 mm20 parts2LMIT4.0k ESP32
Racer
StuckAtPrototype
36 × 50.2 mm70 parts4LApache-2.03.8k ESP32
Controller
29 × 74 mm58 parts4LApache-2.03.8k ESP32
Bitaxe
skot
56.5 × 99.8 mm86 parts4LCERN-OHL-S-2.01.4k