
RevExBot

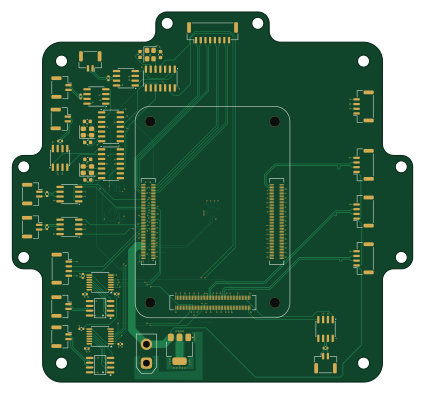
About the RevExBot PCB
RevExBot is an open source PCB design by priyanshu-ogdev, published on GitHub under the Apache-2.0 license. It is a 4-layer board measuring 106 × 98 mm, with 60 components from 29 distinct parts.
Other key parts include the AMS1117-3.3, Hirose DF40C-100DS-0.4V, LSM6DSVTR, SN65HVD10DR and TXB0104PW. By type, the board carries 19 ICs, 15 connectors, 14 capacitors, 9 resistors and 3 crystals.
From the project
The Motion Control Board (MCB) is a carrier board designed for the Radxa CM5, providing comprehensive connectivity for robotic applications.
The Motion Control Board (MCB) is a carrier board designed for the Radxa CM5, providing comprehensive connectivity for robotic applications.
- The board serves as a carrier board for the Radxa CM5. - Power is supplied via a 5V input through an XT30 connector. - A UART TTL debug port is available for serial debugging purposes. - The LSM6DSV IMU is located at the bottom of the board, with an I2C connector available if an external IMU is required. - All signal connections use JST-GH connectors - LCSC component IDs are attached in the KiCad source files for direct JLCPCB fabrication and assembly.
Main components on the RevExBot
RevExBot bill of materials (BOM)
60 components, 29 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | AMS1117-3.3 | SOT-223-3_TabPin2 | U101 |
| 1 | Hirose DF40C-100DS-0.4V | radxa_cm5_1 | U201 |
| 1 | LSM6DSVTR | LGA-14_L3.0-W2.5-P0.50-TL | U202 |
| 1 | Hirose DF40C-100DS-0.4V | radxa_cm5_2 | U301 |
| 1 | Hirose DF40C-100DS-0.4V | radxa_cm5_3 | U401 |
| 2 | SN65HVD10DR | SOIC-8_L4.9-W3.9-P1.27-LS6.0-BL | U402, U405 |
| 3 | TXB0104PW | TSSOP-14_4.4x5mm_P0.65mm | U403, U404, U602 |
| 3 | MCP2518FD-xQBB | SOIC-14_3.9x8.7mm_P1.27mm | U501, U502, U503 |
| 6 | SN65HVD230 | SOIC-8_3.9x4.9mm_P1.27mm | U603, U606, U607, U701, U702, U703 |
| 3 | 40M | Crystal_SMD_3225-4Pin_3.2x2.5mm | Y601, Y602, Y603 |
| 1 | 5V_IN | AMASS_XT30UPB-F_1x02_P5.0mm_Vertical | J101 |
| 1 | I2C_Socket | JST_GH_SM04B-GHS-TB_1x04-1MP_P1.25mm_Horizontal | J201 |
| 1 | ETH | JST_GH_BM08B-GHS-TBT_1x08-1MP_P1.25mm_Vertical | J202 |
| 1 | Debug_Socket | JST_GH_SM04B-GHS-TB_1x04-1MP_P1.25mm_Horizontal | J203 |
| 1 | USB_MASKROM | JST_GH_SM04B-GHS-TB_1x04-1MP_P1.25mm_Horizontal | J301 |
| 1 | USB_1 | JST_GH_SM04B-GHS-TB_1x04-1MP_P1.25mm_Horizontal | J401 |
| 1 | USB_0 | JST_GH_SM04B-GHS-TB_1x04-1MP_P1.25mm_Horizontal | J402 |
| 1 | RS485_0 | JST_GH_SM02B-GHS-TB_1x02-1MP_P1.25mm_Horizontal | J403 |
| 1 | RS485_1 | JST_GH_SM02B-GHS-TB_1x02-1MP_P1.25mm_Horizontal | J404 |
| 1 | SPI00_CAN_OUT | JST_GH_SM02B-GHS-TB_1x02-1MP_P1.25mm_Horizontal | J601 |
Show 9 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | SPI01_CAN_OUT | JST_GH_SM02B-GHS-TB_1x02-1MP_P1.25mm_Horizontal | J602 |
| 1 | SPI02_CAN_OUT | JST_GH_SM02B-GHS-TB_1x02-1MP_P1.25mm_Horizontal | J603 |
| 1 | CAN0_OUT | JST_GH_SM02B-GHS-TB_1x02-1MP_P1.25mm_Horizontal | J701 |
| 1 | CAN1_OUT | JST_GH_SM02B-GHS-TB_1x02-1MP_P1.25mm_Horizontal | J702 |
| 1 | CAN2_OUT | JST_GH_SM02B-GHS-TB_1x02-1MP_P1.25mm_Horizontal | J703 |
| 8 | 100n | C_0402_1005Metric | C201, C202, C401, C402, C403, C404, C603, C604 |
| 6 | 20p | C_0603_1608Metric | C601, C602, C605, C606, C607, C608 |
| 3 | 10k | R_0402_1005Metric | R401, R402, R602 |
| 6 | 120 | R_0402_1005Metric | R601, R604, R605, R701, R702, R703 |
RevExBot design files
The KiCad project lives in the priyanshu-ogdev/RevExBot repository on GitHub; these links point at the commit this page was built from.
RevExBot: common questions
How big is the RevExBot PCB?
The RevExBot measures 106 × 98 mm, has 4 copper layers and is 1.634 mm thick.
How many components are on the RevExBot?
60 components, from 29 distinct parts. The full bill of materials is listed on this page.
Where can I download the RevExBot design files?
From the priyanshu-ogdev/RevExBot repository on GitHub, which has the KiCad layout and the schematic; the links under Design files point to each one.
Can I use the RevExBot design in my own project?
Yes, under the terms of its Apache-2.0 license, which priyanshu-ogdev chose for the repository.