
Evilia boat servo

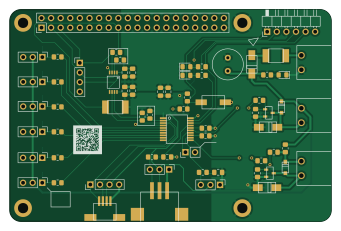
About the Evilia boat servo PCB
Evilia boat servo is an open source PIC PCB design by robperkel, published on GitHub under the GPL-3.0 license. It is a 2-layer board measuring 85 × 56 mm, with 73 components from 28 distinct parts.
Its main chip is the PIC18F16Q41, from the PIC family. Other key parts include the PI4ULS5V202UEX. By type, the board carries 23 resistors, 15 capacitors, 8 diodes, 2 ICs, 2 transistors and 1 connector.
It belongs with the robotics & motion and dev boards & breakouts designs in this gallery.
From the project
Documentation, Hardware Files, and Firmware for Dr. Evilia's Boat Servo Board
This repository contains the documentation, hardware files, and firmware used for this project. The boat runs on a Raspberry Pi 4, Model B.
- Base Software - Tools Needed - Other Tools Used - Bill of Materials (BOM) - Design Objectives - Microcontroller Pinout - Software Registers - Digital Control - Analog Control - Usage from Raspberry Pi
This bare metal I2C driver was used as a code base: https://github.com/microchip-pic-avr-examples/pic18f56q71-bare-metal-i2c-mplab
Main components on the Evilia boat servo
Evilia boat servo bill of materials (BOM)
73 components, 28 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | PIC18F16Q41 | SSOP-20, 5.3mm Body | U1 |
| 1 | PI4ULS5V202UEX | MSOP-8 | U2 |
| 2 | BSS214NH | SOT23-3 | Q1, Q2 |
| 1 | Raspberry_Pi_2_3 | PinHeader_2x20_P2.54mm_Vertical | J1 |
| 2 | 0 | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | ADDR0, ADDR1 |
| 8 | Conn_01x03_Pin | PinHeader_1x03_P2.54mm_Vertical | ANALOG_EXT1, ANALOG_EXT2, SERVO1, SERVO2, SERVO3, SERVO4, SERVO5, SERVO6 |
| 3 | BCH-381H-2 GN | BCH-381H-2GN | BAT_IN1, EXT_LED1, PUMP_IN1 |
| 2 | Conn_01x04_Pin | PinHeader_1x04_P2.54mm_Vertical | EXT_I2C1, EXT_I2C2 |
| 1 | Conn_01x02_Pin | PinHeader_1x02_P2.54mm_Vertical | OPAMP_TEST1 |
| 1 | Conn_01x06 | PinHeader_1x06_P2.54mm_Horizontal | PICKIT1 |
| 1 | 1.1A | 0ZCG Series PTC | PTC2 |
| 1 | 100mA | 0ZCG Series PTC | PTC3 |
| 1 | TL6400AF160QJ | TL6400AF160QJ | RST_SW1 |
| 1 | JST SH | Adafruit STEMMA, 4-pin JST SH | STEMMA1 |
| 1 | JST PH | Adafruit STEMMA, 3-pin JST PH | STEMMA4 |
| 2 | MBR0580S1 | SOD-123 | D1, D2 |
| 2 | SMAJ6.0A | DO-214AC | D3, D4 |
| 1 | B240AE-13 | DO-214AC | D5 |
| 3 | LED_Small_Filled | LED_0805_2012Metric_Pad1.15x1.40mm_HandSolder | D6, D7, D8 |
| 11 | 0.01uF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C1, C3, C5, C7, C8, C9, C10, C11 +3 |
Show 8 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 3 | 0.1uF | C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C2, C4, C6 |
| 1 | 220uF | C_Radial_D8.0mm_H11.5mm_P3.50mm | C15 |
| 8 | 10k | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R1, R3, R4, R7, R8, R9, R10, R11 |
| 9 | 470 | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R2, R14, R15, R16, R17, R18, R19, R20 +1 |
| 2 | 100 | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R12, R21 |
| 2 | 100k | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R13, R22 |
| 1 | 0 | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R23 |
| 1 | 1k | R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R24 |
Evilia boat servo design files
The KiCad project lives in the robperkel/evilia-boat-servo repository on GitHub; these links point at the commit this page was built from.
Evilia boat servo: common questions
What microcontroller does the Evilia boat servo use?
The Evilia boat servo is built around the PIC18F16Q41, from the PIC family.
How big is the Evilia boat servo PCB?
The Evilia boat servo measures 85 × 56 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Evilia boat servo?
73 components, from 28 distinct parts. The full bill of materials is listed on this page.
Where can I download the Evilia boat servo design files?
From the robperkel/evilia-boat-servo repository on GitHub, which has the KiCad layout and the schematic; the links under Design files point to each one.
Can I use the Evilia boat servo design in my own project?
Yes, under the terms of its GPL-3.0 license, which robperkel chose for the repository.
Can I test firmware for the Evilia boat servo without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug PIC firmware against it before you order a PCB.
Similar boards
 PIC
Pslab hardware
fossasia
99 × 53.3 mm187 parts4LApache-2.01.7k PIC
Micro 8088
skiselev
152.4 × 101.6 mm71 partsGPL-3.0414 PIC
GB-CARTPP-DIY
Gekkio
100 × 100 mm22 parts2LCC-BY-4.0376 PIC
GB-BENCH-G1
100 × 100 mm98 parts4LCC-BY-4.0376 PIC
GB-MBCTEST
51.4 × 61 mm32 parts2LCC-BY-4.0376 PIC
GB-LIVE32
51.4 × 61 mm46 parts4LCC-BY-4.0376