
MSP430-Robot-Control

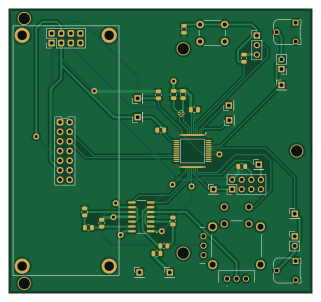
About the MSP430-Robot-Control PCB
MSP430-Robot-Control is an open source TI MSP430/CC PCB design by sergimarsol, published on GitHub under the MIT license. It is a 2-layer board measuring 80 × 75 mm, with 37 components from 18 distinct parts.
Its main chip is the MSP430FR2355TPT, from the TI MSP430/CC family. Other key parts include the LMV324. By type, the board carries 13 connectors, 12 resistors, 4 capacitors, 2 ICs, 2 switches and 1 crystal.
It belongs with the robotics & motion, displays & leds and sensors designs in this gallery.
From the project
Custom KiCad PCB + bare-metal C firmware (MSP430FR2355): LCD menu, joystick, line & light following
A custom two-layer KiCad control board and bare-metal C firmware for the MSP430FR2355. It drives a mobile robot in joystick, line-following and light-following modes, using an LCD menu and an interrupt-driven I2C bus.
The goal: design a controller board for a mobile robot base, have it fabricated, assemble it, and write bare-metal firmware that lets a user pick an operating mode from an on-board menu and then either drive the robot by hand or let it run autonomously.
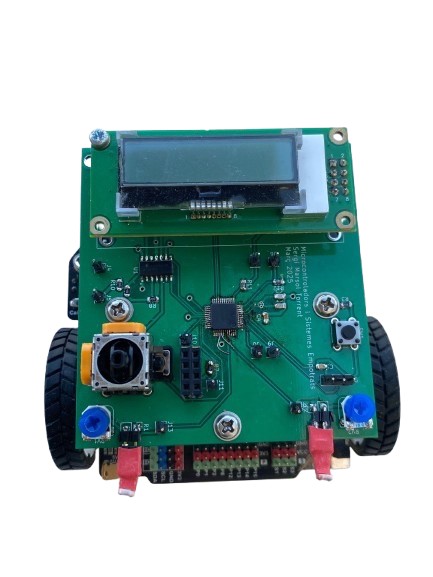
Main components on the MSP430-Robot-Control
MSP430-Robot-Control bill of materials (BOM)
37 components, 18 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | MSP430FR2355TPT | QFP50P900X900X160-48N | IC1 |
| 1 | LMV324 | SOIC127P600X175-14N | U1 |
| 1 | Crystal | XTAL_ECS-.327-8-14 | Y1 |
| 1 | conn_DFrobot | conn_DFrobot | J1 |
| 1 | Conn_01x03_Pin | PinHeader_1x03_P2.54mm_Vertical | J2 |
| 1 | Conn_02x04_Odd_Even | PinHeader_2x04_P2.54mm_Vertical | J3 |
| 10 | Conn_01x01 | PinHeader_1x01_P2.54mm_Vertical | J4, J5, J6, J7, J8, J9, J10, J11 +2 |
| 1 | LCD_2x16_I2C | LCD_2x16_I2C(Midas) | LCD1 |
| 2 | Device_R_POT | Trimmer_MiSE | RV1, RV2 |
| 1 | THB001P | THB001P | S1 |
| 1 | SW_Push | SW_PUSH_6mm_H4.3mm | SW1 |
| 1 | 1n | C_0805_2012Metric | C1 |
| 2 | 12.5p | C_0805_2012Metric | C2, C3 |
| 1 | 0.1u | C_0805_2012Metric | C4 |
| 2 | Device_R_PHOTO | LDR | R1, R2 |
| 2 | 47k | R_0805_2012Metric | R3, R7 |
| 6 | 50k | R_0805_2012Metric | R4, R5, R6, R8, R9, R10 |
| 2 | 2.2k | R_0805_2012Metric | R11, R12 |
MSP430-Robot-Control design files
The KiCad project lives in the sergimarsol/MSP430-Robot-Control-PCB repository on GitHub; these links point at the commit this page was built from.
MSP430-Robot-Control: common questions
What microcontroller does the MSP430-Robot-Control use?
The MSP430-Robot-Control is built around the MSP430FR2355TPT, from the TI MSP430/CC family.
How big is the MSP430-Robot-Control PCB?
The MSP430-Robot-Control measures 80 × 75 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the MSP430-Robot-Control?
37 components, from 18 distinct parts. The full bill of materials is listed on this page.
Where can I download the MSP430-Robot-Control design files?
From the sergimarsol/MSP430-Robot-Control-PCB repository on GitHub, which has the KiCad layout and the schematic; the links under Design files point to each one.
Can I use the MSP430-Robot-Control design in my own project?
Yes, under the terms of its MIT license, which sergimarsol chose for the repository.
Can I test firmware for the MSP430-Robot-Control without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug TI MSP430/CC firmware against it before you order a PCB.
Similar boards
 TI MSP430/CC
Pluto
carrotIndustries
24.4 × 24.4 mm36 parts2LGPL-3.0533 TI MSP430/CC
Apimote
riverloopsec
83.3 × 33.4 mm80 parts4LTAPR-OHL-1.089 TI MSP430/CC
Toniebox
toniebox-reverse-engineering
88 × 102 mm11 parts2LNo license36 TI MSP430/CC
Nsumo hardware
artfulbytes
50 × 65 mm73 parts2LMIT33 TI MSP430/CC
Elektronika-1
BenjaminSoelberg
29.5 × 29.5 mm14 parts4LGPL-3.029 TI MSP430/CC
MSP430 Breadstick - Apple Sauce
upsidedownlabs
18.5 × 65.8 mm31 parts2LCERN-OHL-S-2.021