
Lancer sensorbord v2

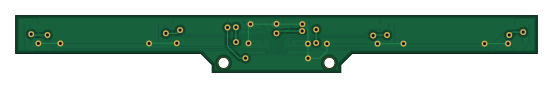
About the Lancer sensorbord v2 PCB
Lancer sensorbord v2 is an open source PCB design by shimotoriharuki, published on GitHub under the MIT license. It is a 2-layer board measuring 138 × 15 mm, with 21 components from 5 distinct parts.
By type, the board carries 6 transistors, 6 diodes, 6 resistors, 2 capacitors and 1 connector.
It belongs with the robotics & motion designs in this gallery, and the repository also holds 1 earlier revision of it.
Lancer sensorbord v2 bill of materials (BOM)
21 components, 5 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 6 | TEMT7100X01 | TEMT7100X01 | Q1, Q2, Q3, Q4, Q5, Q6 |
| 1 | CN-FFC(0.5)14PD | CN-FFC-SMT2(CN-FFC(0.5)14PD) | P1 |
| 6 | SIR19-21C/TR8 | SIR19-21C | D1, D2, D3, D4, D5, D6 |
| 2 | 0.1u | C_1608_HandSolderring | C1, C2 |
| 6 | 100k | C_1608_HandSolderring | R1, R2, R3, R4, R5, R6 |
Lancer sensorbord v2 design files
The KiCad project lives in the shimotoriharuki/2018_RobotLancer_kicad repository on GitHub; these links point at the commit this page was built from.
Lancer sensorbord v2: common questions
How big is the Lancer sensorbord v2 PCB?
The Lancer sensorbord v2 measures 138 × 15 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Lancer sensorbord v2?
21 components, from 5 distinct parts. The full bill of materials is listed on this page.
Where can I download the Lancer sensorbord v2 design files?
From the shimotoriharuki/2018_RobotLancer_kicad repository on GitHub, which has the KiCad layout; the links under Design files point to each one.
Can I use the Lancer sensorbord v2 design in my own project?
Yes, under the terms of its MIT license, which shimotoriharuki chose for the repository.
More boards in 2018_RobotLancer_kicad
 STM32
Lancer mainbord v1
109.4 × 94.4 mm177 parts2LMIT0
Lancer sensor bwv2
150 × 100 mm33 parts2LMIT0
Lancer subbord
60 × 40 mm22 parts2LMIT0
Sensorbord whiteline
138 × 15 mm21 parts2LMIT0
Sensorbord 1mm 16pin
138 × 15 mm21 parts2LMIT0
Lancer sensorboard v3
138 × 95 mm21 parts2LMIT0
Earlier revisions in the repo: lancer_sensorbord_v1
Similar boards
Stack chan
stack-chan
50 × 50 mm33 parts2LApache-2.01.7k
Cube batteryboard
willem-pennings
95 × 95 mm4 parts2LGPL-3.01.1k
Mesabob
rene-dev
87.5 × 50 mm44 parts2LGPL-3.0979
Bob
100 × 100 mm140 parts2LGPL-3.0979
Triple adapter
57 × 75 mm26 parts2LGPL-3.0979
Trollerv2
100 × 75 mm33 parts4LGPL-3.0979