
Lancer mainbord v1

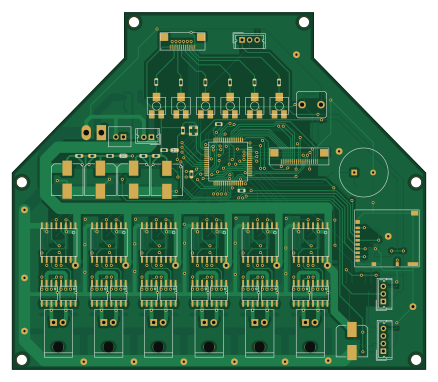
About the Lancer mainbord v1 PCB
Lancer mainbord v1 is an open source STM32 PCB design by shimotoriharuki, published on GitHub under the MIT license. It is a 2-layer board measuring 109.4 × 94.4 mm, with 177 components from 39 distinct parts.
Its main chip is the STM32F401-64, from the STM32 family. Other key parts include the TC4469, NJM2845DL1-05 and NJM2845DL1-33. By type, the board carries 67 resistors, 31 diodes, 29 capacitors, 15 connectors, 8 ICs and 2 transistors.
It belongs with the robotics & motion designs in this gallery.
Main components on the Lancer mainbord v1
Lancer mainbord v1 bill of materials (BOM)
177 components, 39 distinct parts.
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 6 | TC4469 | TC4469 | IC1, IC2, IC3, IC4, IC5, IC6 |
| 1 | NJM2845DL1-05 | NJM2845DL1 | U1 |
| 1 | NJM2845DL1-33 | NJM2845DL1 | U2 |
| 2 | Q_NMOS_GSD | BSS138 | Q1, Q2 |
| 1 | ASDMB-8.000MHZ-LY-T | ASDMB-8.000MHZ-LY-T | Y1 |
| 1 | Micro_SD_Card_Det | micro_SDcard | J1 |
| 1 | encorder | Molex_MicroLatch-53253-0470_04x2.00mm_Straight | J2 |
| 2 | potentio | Molex_MicroLatch-53253-0370_03x2.00mm_Straight | J3, J4 |
| 1 | BATT | hole | P1 |
| 1 | main_sw | PA_2pin | P2 |
| 1 | VOLTAGE_CHECK | Molex_MicroLatch-53253-0270_02x2.00mm_Straight | P3 |
| 6 | XA_side | XA_2pin_boss | P4, P5, P6, P7, P8, P9 |
| 1 | CN-FFC-SMT2(CN-FFC(0.5)14PD) | CN-FFC-SMT2(CN-FFC(0.5)14PD) | P10 |
| 1 | CN-FFC-SMT2(CN-FFC(0.5)22PD) | CN-FFC-SMT2(CN-FFC(0.5)20PD) | P11 |
| 1 | PKM17EPP-4001-B0 | PKM13EPYH4000-A0 | BZ1 |
| 1 | STM32F401-64 | stm32f401 | CPU1 |
| 12 | TPC8407 | TPC8407 | FET1, FET2, FET3, FET4, FET5, FET6, FET7, FET8 +4 |
| 1 | uPA2815T1S | uPA2815T1S | FET13 |
| 6 | 1k | G43ATB103 | RV1, RV2, RV3, RV4, RV5, RV6 |
| 1 | SW_Push | tact_switch | SW1 |
Show 19 more
| Qty | Part | Footprint | Refs |
|---|---|---|---|
| 1 | 5V_CHECK | LED 1608 | LED1 |
| 1 | 3.3V_CHECK | LED 1608 | LED2 |
| 18 | 1SMB5930BT3G | 1SMB5930BT3G | D1, D2, D3, D10, D11, D12, D13, D14 +10 |
| 12 | CUS10F30 | CUS10F30 | D4, D5, D6, D7, D8, D9, D19, D20 +4 |
| 1 | 1SMB5919BT3G | 1SMB5930BT3G | D31 |
| 5 | 220u | CP_Elec_8x10 | C1, C4, C5, C8, C29 |
| 7 | 0.1u | C_1608_HandSolderring | C2, C3, C6, C7, C17, C25, C26 |
| 12 | 10u | C_1608_HandSolderring | C9, C10, C11, C12, C13, C14, C18, C19 +4 |
| 4 | 1u | C_1608_HandSolderring | C15, C16, C24, C28 |
| 1 | 4.7u | C_1608_HandSolderring | C27 |
| 1 | 680 | R_1608_HandSoldering | R1 |
| 1 | 330 | R_1608_HandSoldering | R2 |
| 37 | 12k | R_1608_HandSoldering | R3, R4, R5, R6, R7, R8, R15, R16 +29 |
| 12 | 47 | R_1608_HandSoldering | R9, R10, R11, R12, R13, R14, R33, R34 +4 |
| 3 | 47k | R_1608_HandSoldering | R51, R52, R53 |
| 6 | 56 | R_1608_HandSoldering | R54, R55, R56, R57, R58, R59 |
| 5 | 10k | R_1608_HandSoldering | R60, R61, R62, R63, R67 |
| 1 | 1k | R_1608_HandSoldering | R64 |
| 1 | 150k | R_1608_HandSoldering | R66 |
Lancer mainbord v1 design files
The KiCad project lives in the shimotoriharuki/2018_RobotLancer_kicad repository on GitHub; these links point at the commit this page was built from.
Lancer mainbord v1: common questions
What microcontroller does the Lancer mainbord v1 use?
The Lancer mainbord v1 is built around the STM32F401-64, from the STM32 family.
How big is the Lancer mainbord v1 PCB?
The Lancer mainbord v1 measures 109.4 × 94.4 mm, has 2 copper layers and is 1.6 mm thick.
How many components are on the Lancer mainbord v1?
177 components, from 39 distinct parts. The full bill of materials is listed on this page.
Where can I download the Lancer mainbord v1 design files?
From the shimotoriharuki/2018_RobotLancer_kicad repository on GitHub, which has the KiCad layout; the links under Design files point to each one.
Can I use the Lancer mainbord v1 design in my own project?
Yes, under the terms of its MIT license, which shimotoriharuki chose for the repository.
Can I test firmware for the Lancer mainbord v1 without the hardware?
Yes. HardLabs builds a simulation of the board from its netlist and BOM, so you can run and debug STM32 firmware against it before you order a PCB.
More boards in 2018_RobotLancer_kicad
Lancer sensor bwv2
150 × 100 mm33 parts2LMIT0
Lancer subbord
60 × 40 mm22 parts2LMIT0
Lancer sensorbord v2
138 × 15 mm21 parts2LMIT0
Sensorbord whiteline
138 × 15 mm21 parts2LMIT0
Sensorbord 1mm 16pin
138 × 15 mm21 parts2LMIT0
Lancer sensorboard v3
138 × 95 mm21 parts2LMIT0
Similar boards
 STM32
LumenPnP Motherboard
opulo-inc
149 × 95 mm296 parts4LCC-BY-SA-4.03.7k STM32
AxxSolder
AxxAxx
39 × 82.5 mm122 parts2LGPL-3.01.7k STM32
LibreVNA
jankae
122 × 98 mm592 parts6LGPL-3.01.6k STM32
AIOC
skuep
21 × 31.5 mm47 parts2LMIT1.4k STM32
Ferris
pierrechevalier83
208.8 × 86.8 mm102 parts2LSHL-2.11.3k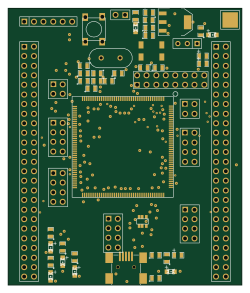 STM32
176 pin board
rusefi
61.8 × 73.2 mm76 parts2LGPL-3.01.2k